Related Experiment Video
Updated: Nov 26, 2025

Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
The mechanics of azimuth control in jumping by froghopper insects
1Department of Zoology, University of Cambridge, Downing Street, Cambridge CB2 3EJ, UK. rscealai@gmail.com

Abstract:
Many animals move so fast that there is no time for sensory feedback to correct possible errors. The biomechanics of the limbs participating in such movements appear to be configured to simplify neural control. To test this general principle, we analysed how froghopper insects control the azimuth direction of their rapid jumps, using high speed video of the natural movements and modelling to understand the mechanics of the hind legs. We show that froghoppers control azimuth by altering the initial orientation of the hind tibiae; their mean angle relative to the midline closely predicts the take-off azimuth. This applies to jumps powered by both hind legs, or by one hind leg. Modelling suggests that moving the two hind legs at different times relative to each other could also control azimuth, but measurements of natural jumping showed that the movements of the hind legs were synchronised to within 32 mus of each other. The maximum timing difference observed (67 micros) would only allow control of azimuth over 0.4 deg. to either side of the midline. Increasing the timing differences between the hind legs is also energetically inefficient because it decreases the energy available and causes losses of energy to body spin; froghoppers with just one hind leg spin six times faster than intact ones. Take-off velocities also fall. The mechanism of azimuth control results from the mechanics of the hind legs and the resulting force vectors of their tibiae. This enables froghoppers to have a simple transform between initial body position and motion trajectory, therefore potentially simplifying neural control.
Related Concept Videos
 01:19
Azimuths and Bearings
 01:16
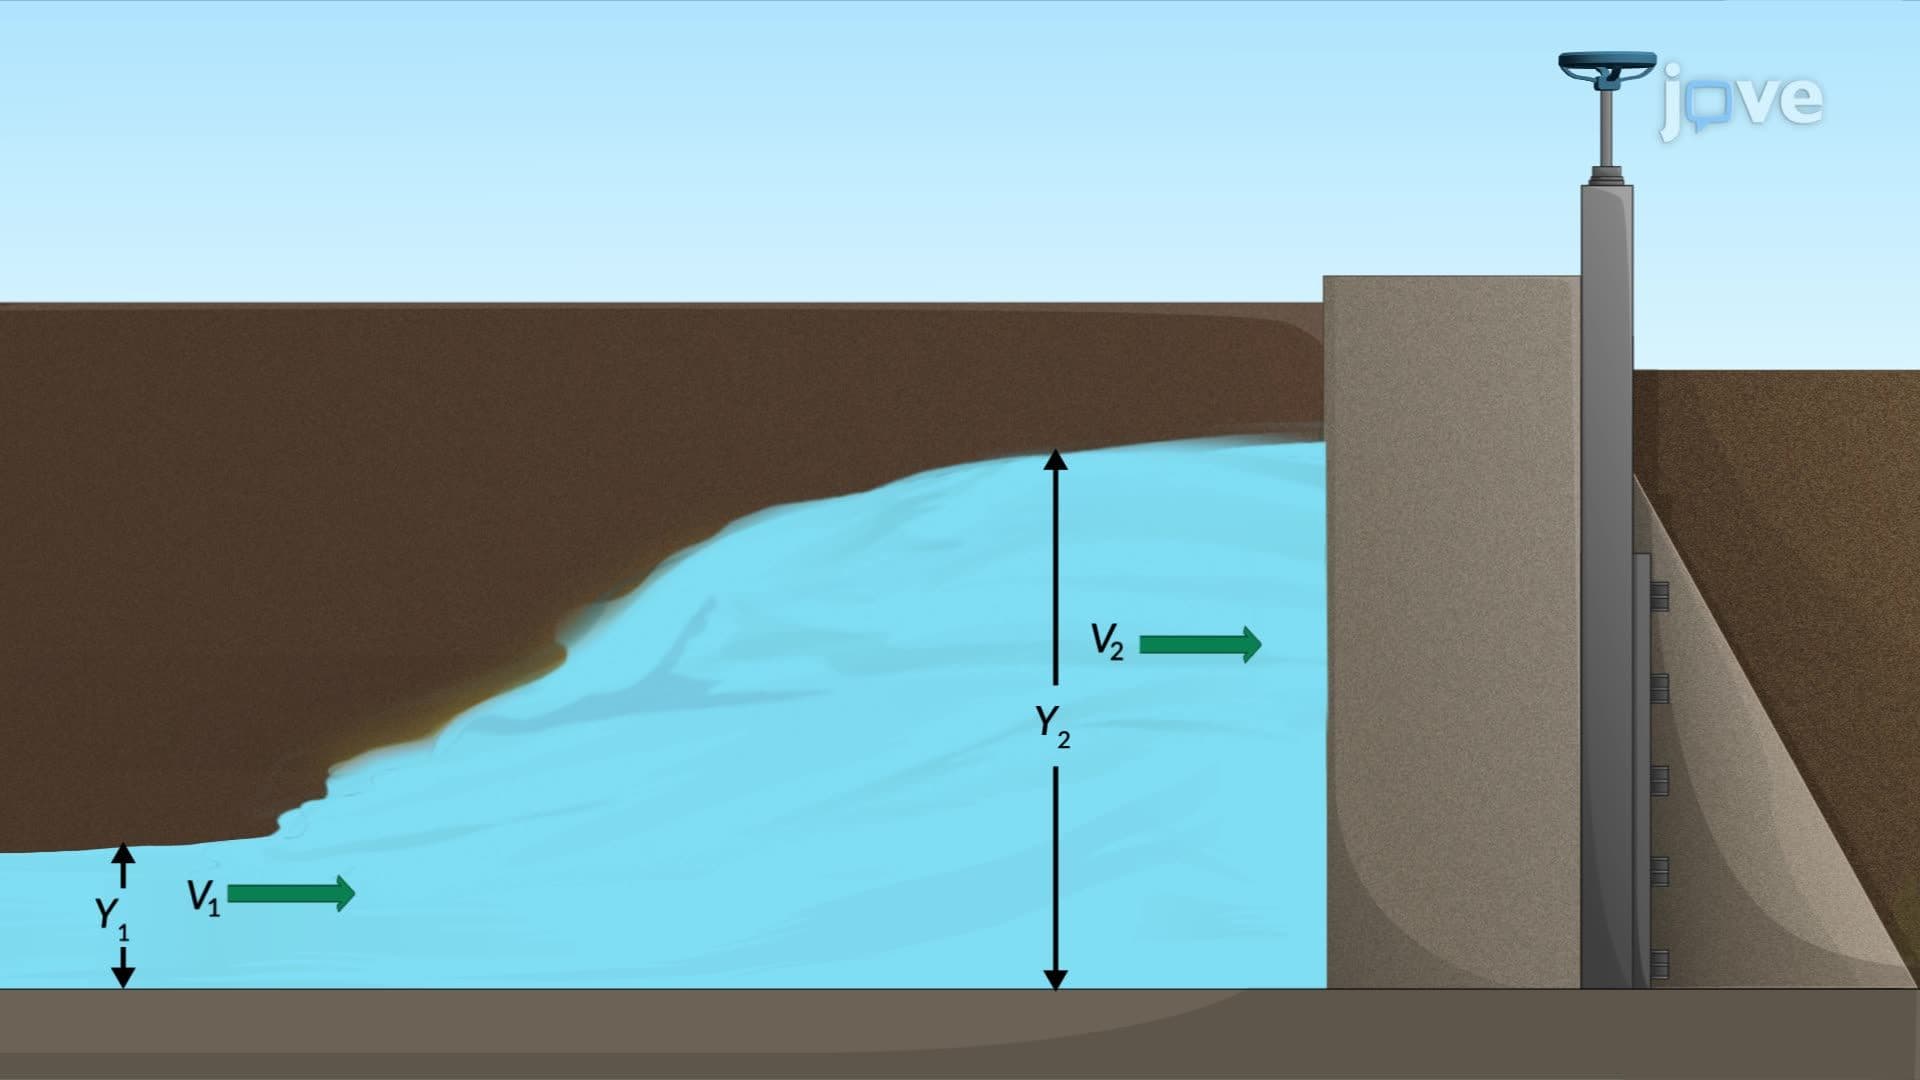
Hydraulic Jump: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:47
Osmoregulation in Insects
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...