Related Experiment Video
Updated: Jun 13, 2026
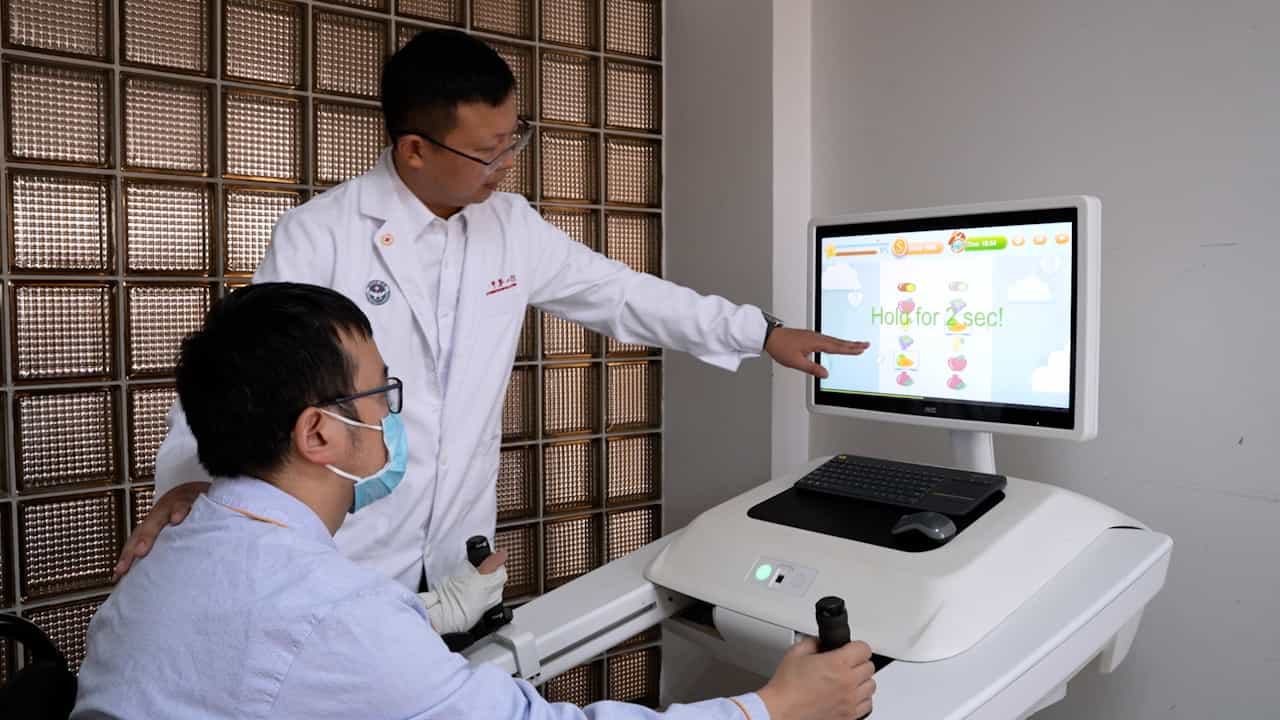
Application of a Dual Upper Limb Task-Oriented Robotic System for the Functional Recovery of the Upper Limb in Stroke Patients
Published on: October 11, 2024
Robot therapy of the upper limb in stroke patients: preliminary experiences for the principle-based use of this
Maura Casadio1, Psiche Giannoni, Lorenzo Masia
1Rehabilitation Institute of Chicago, Sensory Motor Performance Program, Chicago, USA.

Abstract:
Robotic systems for neuromotor rehabilitation have been a part of clinical practice for more than a decade but the efficacy of this new technology is still debated. One reason for this, in our opinion, is that there is still no consensus on the most important features of these systems, or on the underlying theoretical basis, essential for the rational design of treatment protocols. The aim of this paper, born of our long experience in the study of the neural control of movement and the use of robots for characterizing motor control mechanisms, is to make a small contribution to clarifying this issue. What is needed in the future is a "research pipeline" encompassing experimentally validated models of neural control of movement, models of motor learning, models of functional recovery, and finally principle-based robot therapy control strategies. We believe this is a necessary prerequisite for carrying out well formulated comparisons of different control strategies as well as mixed strategies of robot/human treatment, in the framework of randomised, controlled clinical trials.