Related Experiment Video
Updated: Jun 13, 2026

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Groupwise registration and atlas construction of 4th-order tensor fields using the R+ Riemannian metric
Angelos Barmpoutis1, Baba C Vemuri
1CISE Department, University of Florida, Gainesville, FL 32611, USA. abarmpou@cise.ufl.edu

Abstract:
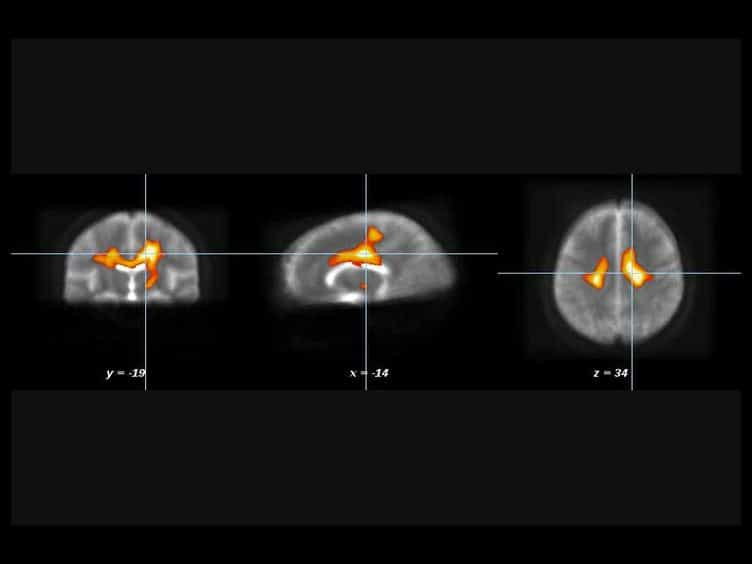
Registration of Diffusion-Weighted MR Images (DW-MRI) can be achieved by registering the corresponding 2nd-order Diffusion Tensor Images (DTI). However, it has been shown that higher-order diffusion tensors (e.g. order-4) outperform the traditional DTI in approximating complex fiber structures such as fiber crossings. In this paper we present a novel method for unbiased group-wise non-rigid registration and atlas construction of 4th-order diffusion tensor fields. To the best of our knowledge there is no other existing method to achieve this task. First we define a metric on the space of positive-valued functions based on the Riemannian metric of real positive numbers (denoted by R+). Then, we use this metric in a novel functional minimization method for non-rigid 4th-order tensor field registration. We define a cost function that accounts for the 4th-order tensor re-orientation during the registration process and has analytic derivatives with respect to the transformation parameters. Finally, the tensor field atlas is computed as the minimizer of the variance defined using the Riemannian metric. We quantitatively compare the proposed method with other techniques that register scalar-valued or diffusion tensor (rank-2) representations of the DWMRI.
Related Concept Videos
 01:28
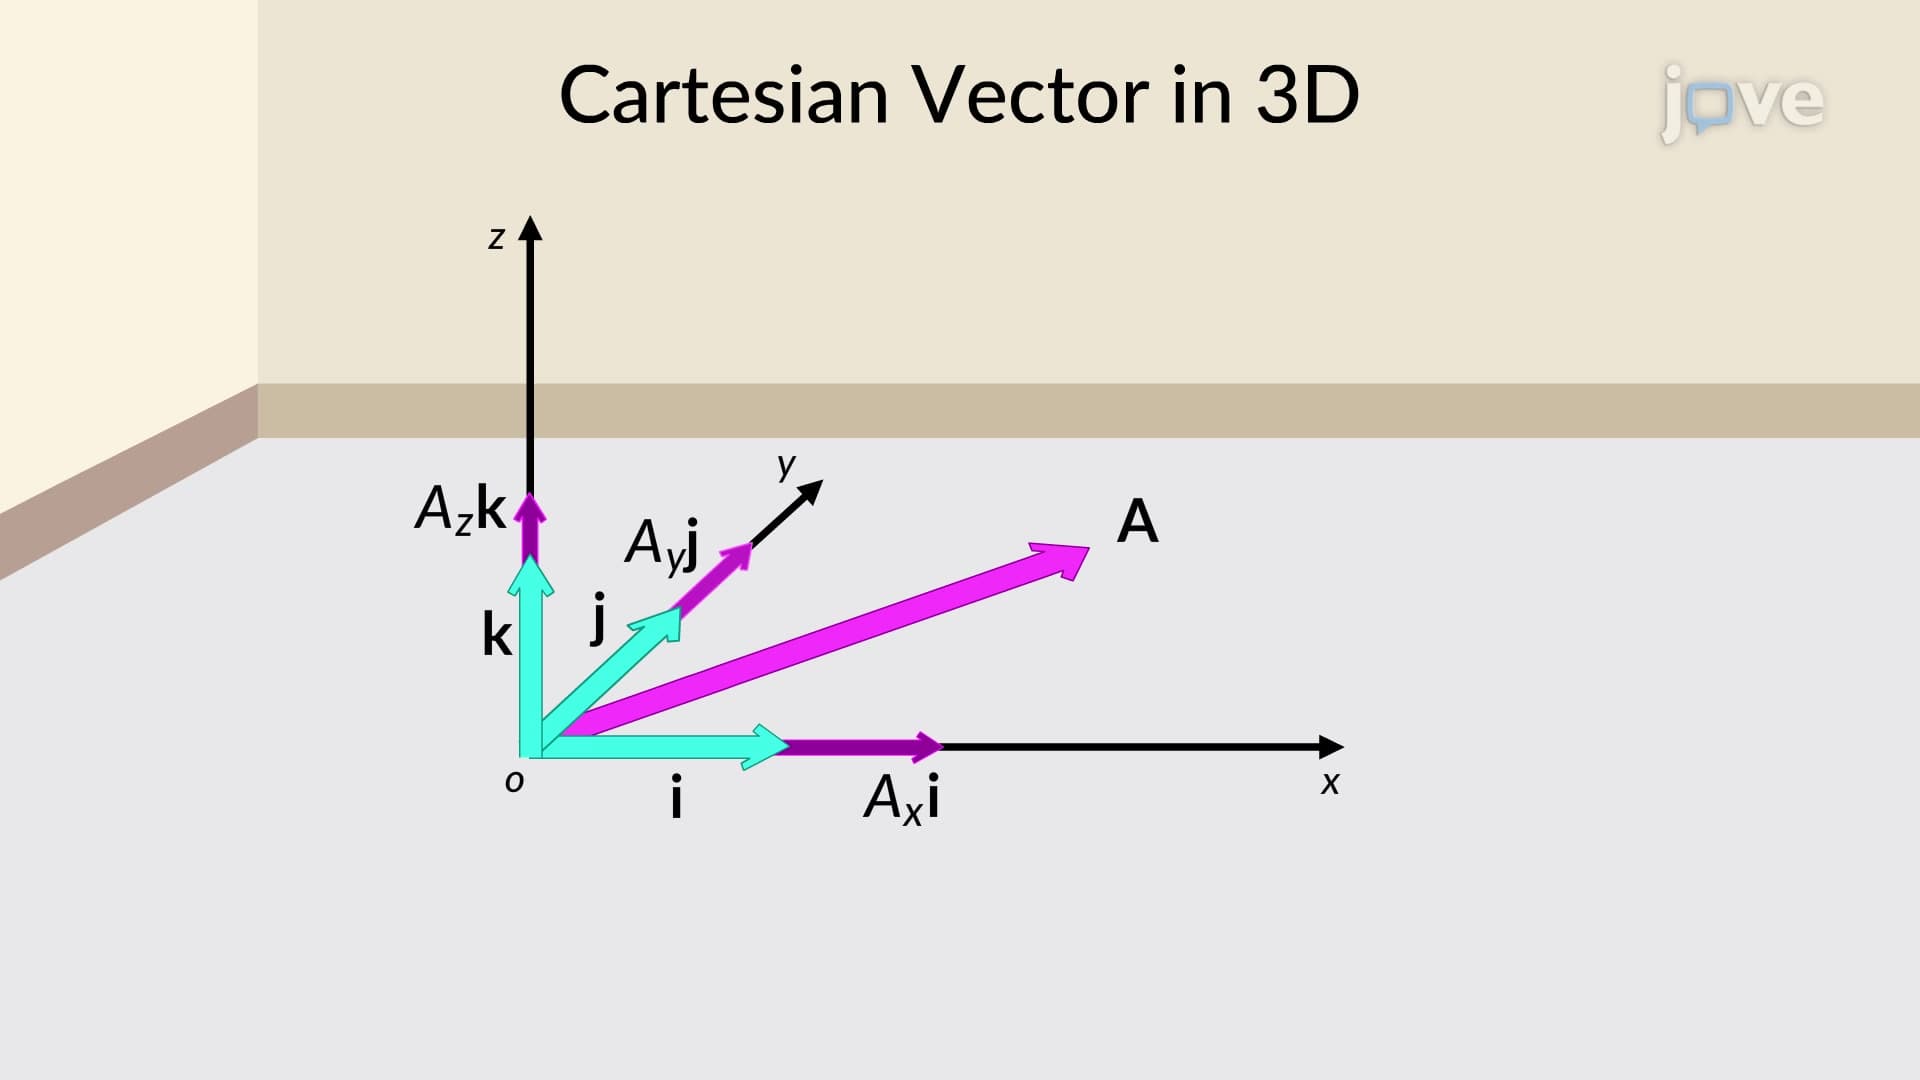
Cartesian Vector Notation
 01:26
Cartesian Form for Vector Formulation
 01:20
Torsion in Vector Calculus
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:24
Inertia Tensor
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
 01:10
Vector Algebra: Graphical Method
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...