Motion estimation for nonoverlapping multicamera rigs: linear algebraic and L{infinity} geometric solutions
Related Experiment Video
Updated: Jun 13, 2026

Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Jae-Hak Kim1, Hongdong Li, Richard Hartley
1Department of Computer Science, Queen Mary, University of London, Mile End Road, London E14NS, United Kingdom. jaehak@dcs.qmul.ac.uk

Abstract:
We investigate the problem of estimating the ego-motion of a multicamera rig from two positions of the rig. We describe and compare two new algorithms for finding the 6 degrees of freedom (3 for rotation and 3 for translation) of the motion. One algorithm gives a linear solution and the other is a geometric algorithm that minimizes the maximum measurement error-the optimal L{infinity} solution. They are described in the context of the General Camera Model (GCM), and we pay particular attention to multicamera systems in which the cameras have nonoverlapping or minimally overlapping field of view. Many nonlinear algorithms have been developed to solve the multicamera motion estimation problem. However, no linear solution or guaranteed optimal geometric solution has previously been proposed. We made two contributions: 1) a fast linear algebraic method using the GCM and 2) a guaranteed globally optimal algorithm based on the L{infinity} geometric error using the branch-and-bound technique. In deriving the linear method using the GCM, we give a detailed analysis of degeneracy of camera configurations. In finding the globally optimal solution, we apply a rotation space search technique recently proposed by Hartley and Kahl. Our experiments conducted on both synthetic and real data have shown excellent results.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
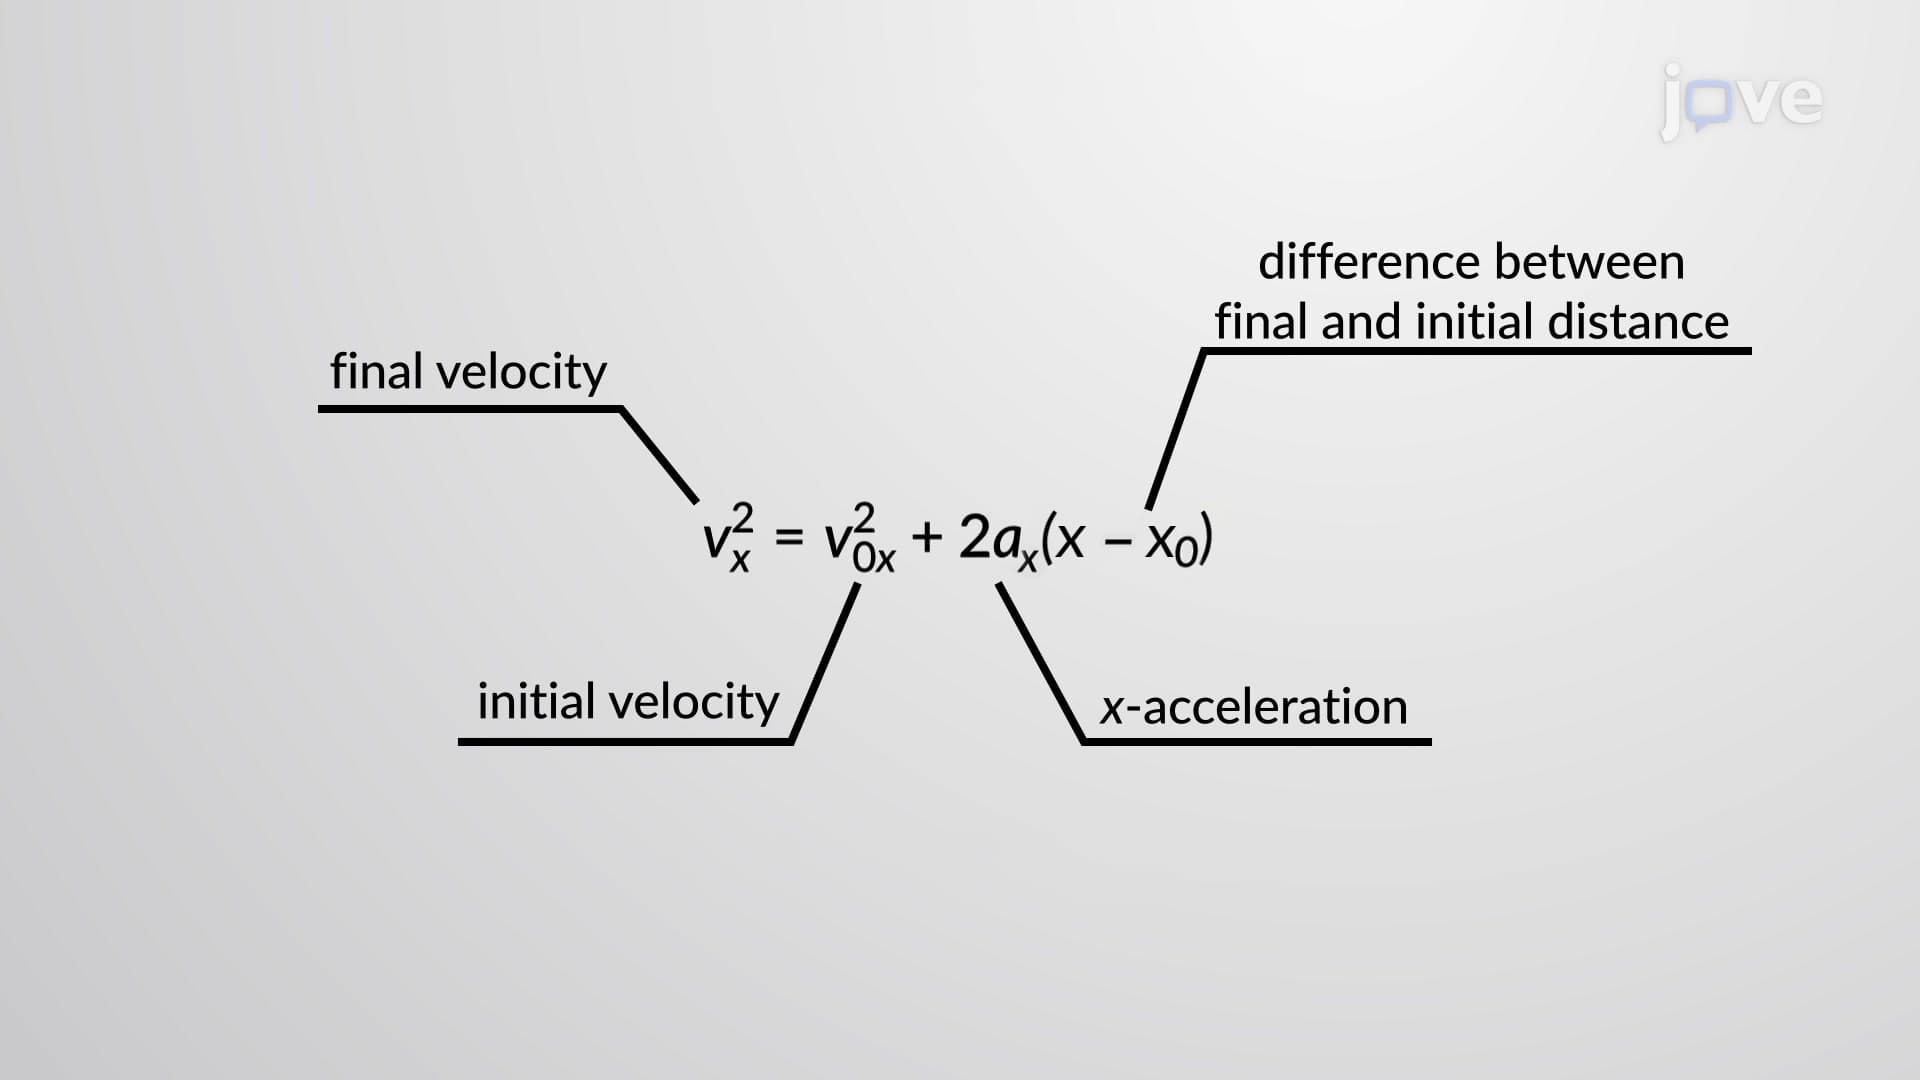
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:26
Kinematic Equations - I