Robust FFT-based scale-invariant image registration with image gradients
Related Experiment Video
Updated: Jun 13, 2026
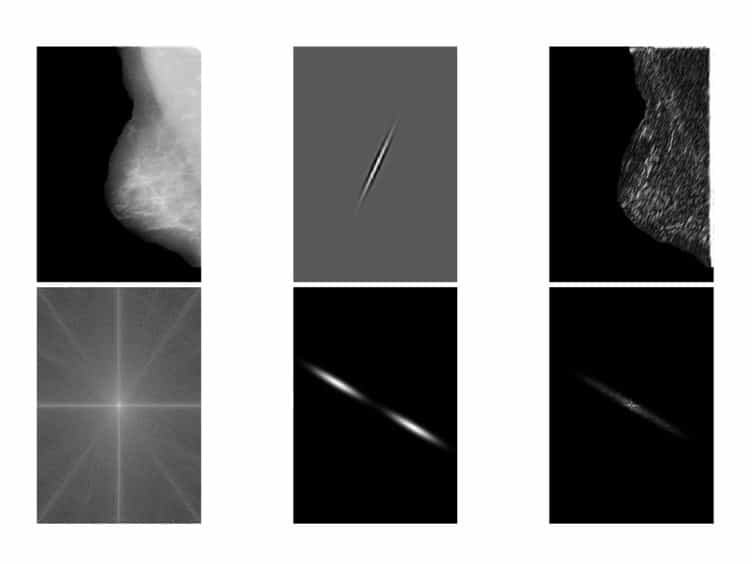
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Georgios Tzimiropoulos1, Vasileios Argyriou, Stefanos Zafeiriou
1Department of Electrical and Electronic Engineering, Imperial College London, London SW7 2AZ, UK. gt204@imperial.ac.uk

Abstract:
We present a robust FFT-based approach to scale-invariant image registration. Our method relies on FFT-based correlation twice: once in the log-polar Fourier domain to estimate the scaling and rotation and once in the spatial domain to recover the residual translation. Previous methods based on the same principles are not robust. To equip our scheme with robustness and accuracy, we introduce modifications which tailor the method to the nature of images. First, we derive efficient log-polar Fourier representations by replacing image functions with complex gray-level edge maps. We show that this representation both captures the structure of salient image features and circumvents problems related to the low-pass nature of images, interpolation errors, border effects, and aliasing. Second, to recover the unknown parameters, we introduce the normalized gradient correlation. We show that, using image gradients to perform correlation, the errors induced by outliers are mapped to a uniform distribution for which our normalized gradient correlation features robust performance. Exhaustive experimentation with real images showed that, unlike any other Fourier-based correlation techniques, the proposed method was able to estimate translations, arbitrary rotations, and scale factors up to 6.
Related Concept Videos
 01:19
Gradient Vectors and Their Applications
 01:27
Significance of the Gradient Vector
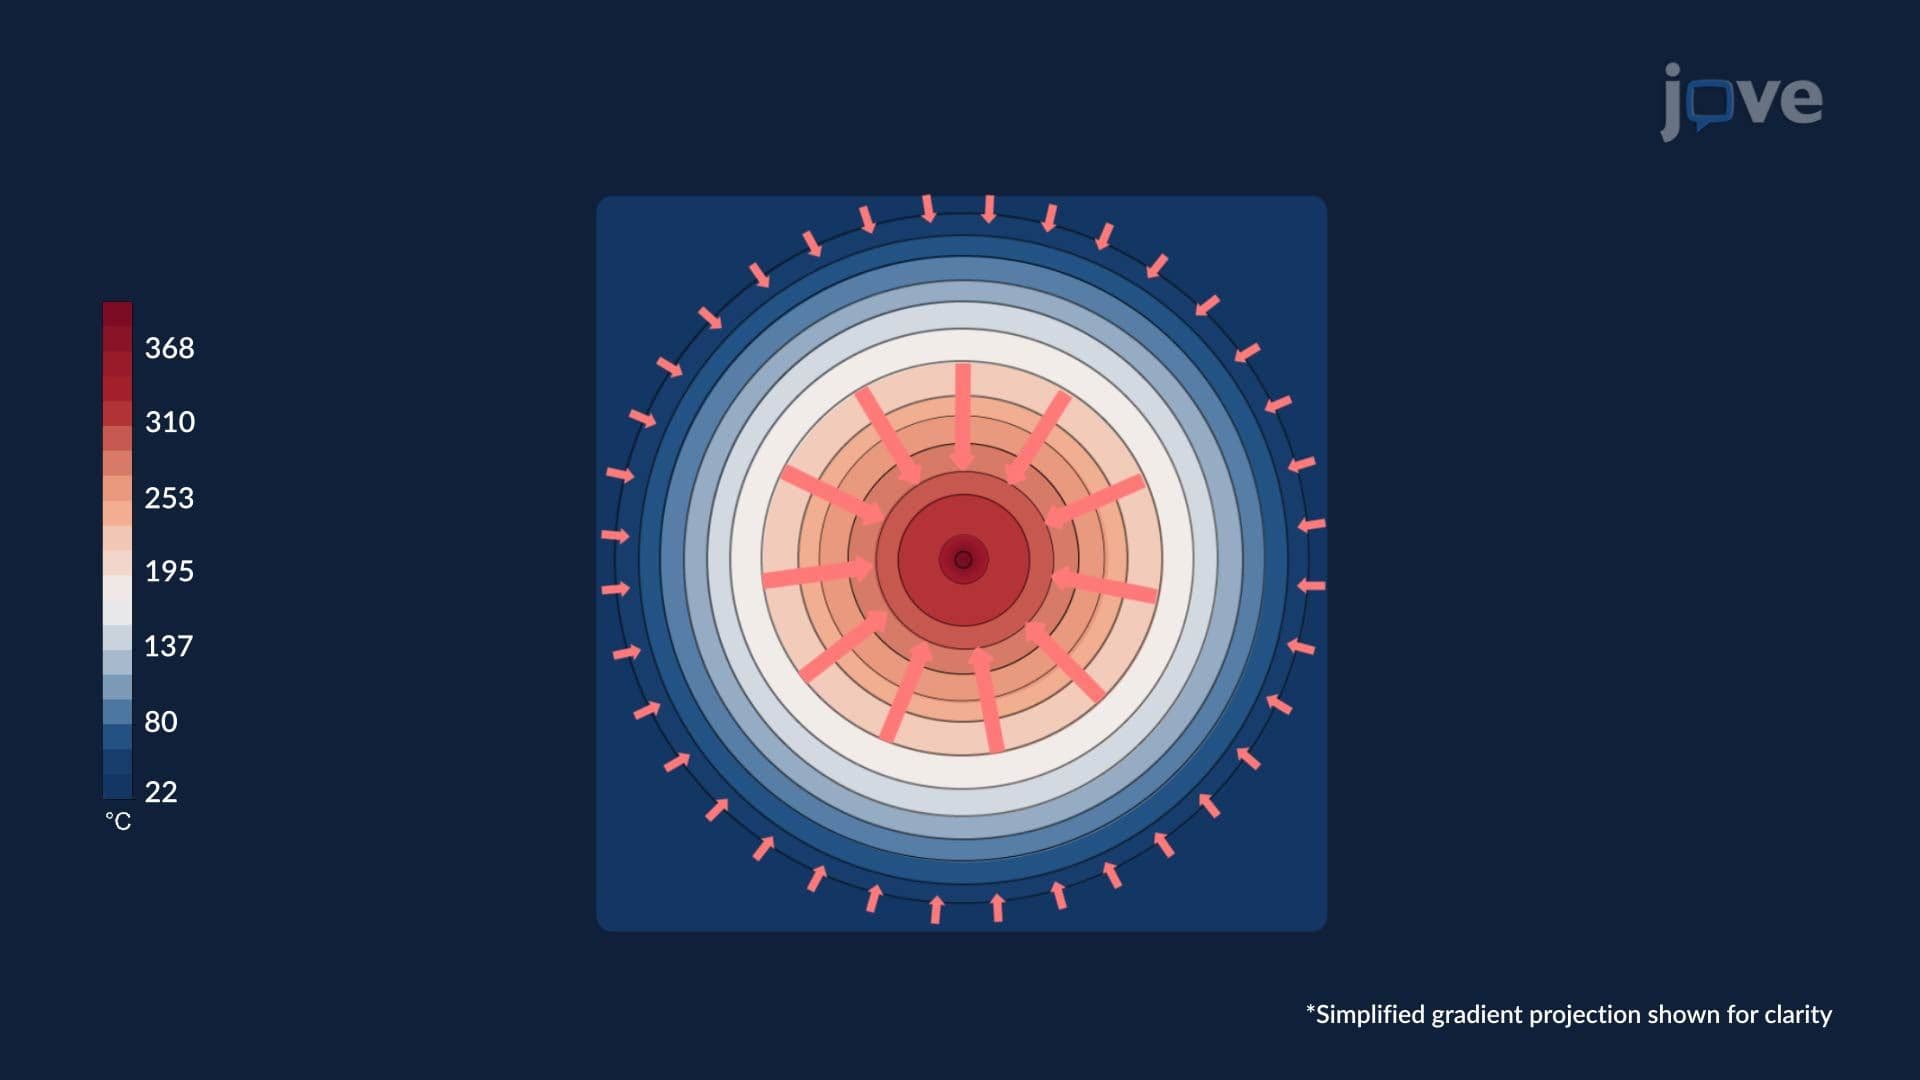 01:27
Gradient Fields
 01:10
Fast Fourier Transform
The computational efficiency of the FFT becomes...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.