JanusVF: accurate navigation using SCAAT and virtual fiducials
Related Experiment Video
Updated: Jun 12, 2026
Technical Approach for Infrared Tracking for Soft Tissue Navigation with a Holographic Head-Mounted Display and Preclinical Validation
Published on: September 2, 2025
1University of Louisiana at Lafayette, 537 Cajundome Blvd #239, Lafayette, LA 70506, USA. malcolm@louisiana.edu

Abstract:
Several critical limitations exist in the currently available tracking technologies for fully enclosed virtual reality (VR) systems. While several 6DOF tracking projects such as Hedgehog have successfully demonstrated excellent accuracy, precision, and robustness within moderate budgets, these projects still include elements of hardware that can interfere with the user's visual experience. The objective of this project is to design a tracking solution for fully enclosed VR displays that achieves comparable performance to available commercial solutions but without any artifacts that can obscure the user's view. JanusVF is a tracking solution involving a cooperation of both the hardware sensors and the software rendering system. A small, high-resolution camera is worn on the user's head, but faces backward (180 degree rotation about vertical from the user's perspective). After acquisition of the initial state, the VR rendering software draws specific fiducial markers with known size and absolute position inside the VR scene. These virtual markers are only drawn behind the user and in view of the camera. These fiducials are tracked by ARToolkitPlus and integrated by a single-constraint-at-a-time (SCAAT) filter algorithm to update the head pose. Experiments analyzing accuracy, precision, and latency in a six-sided CAVE-like system show performance that is comparable to alternative commercial technologies.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:19
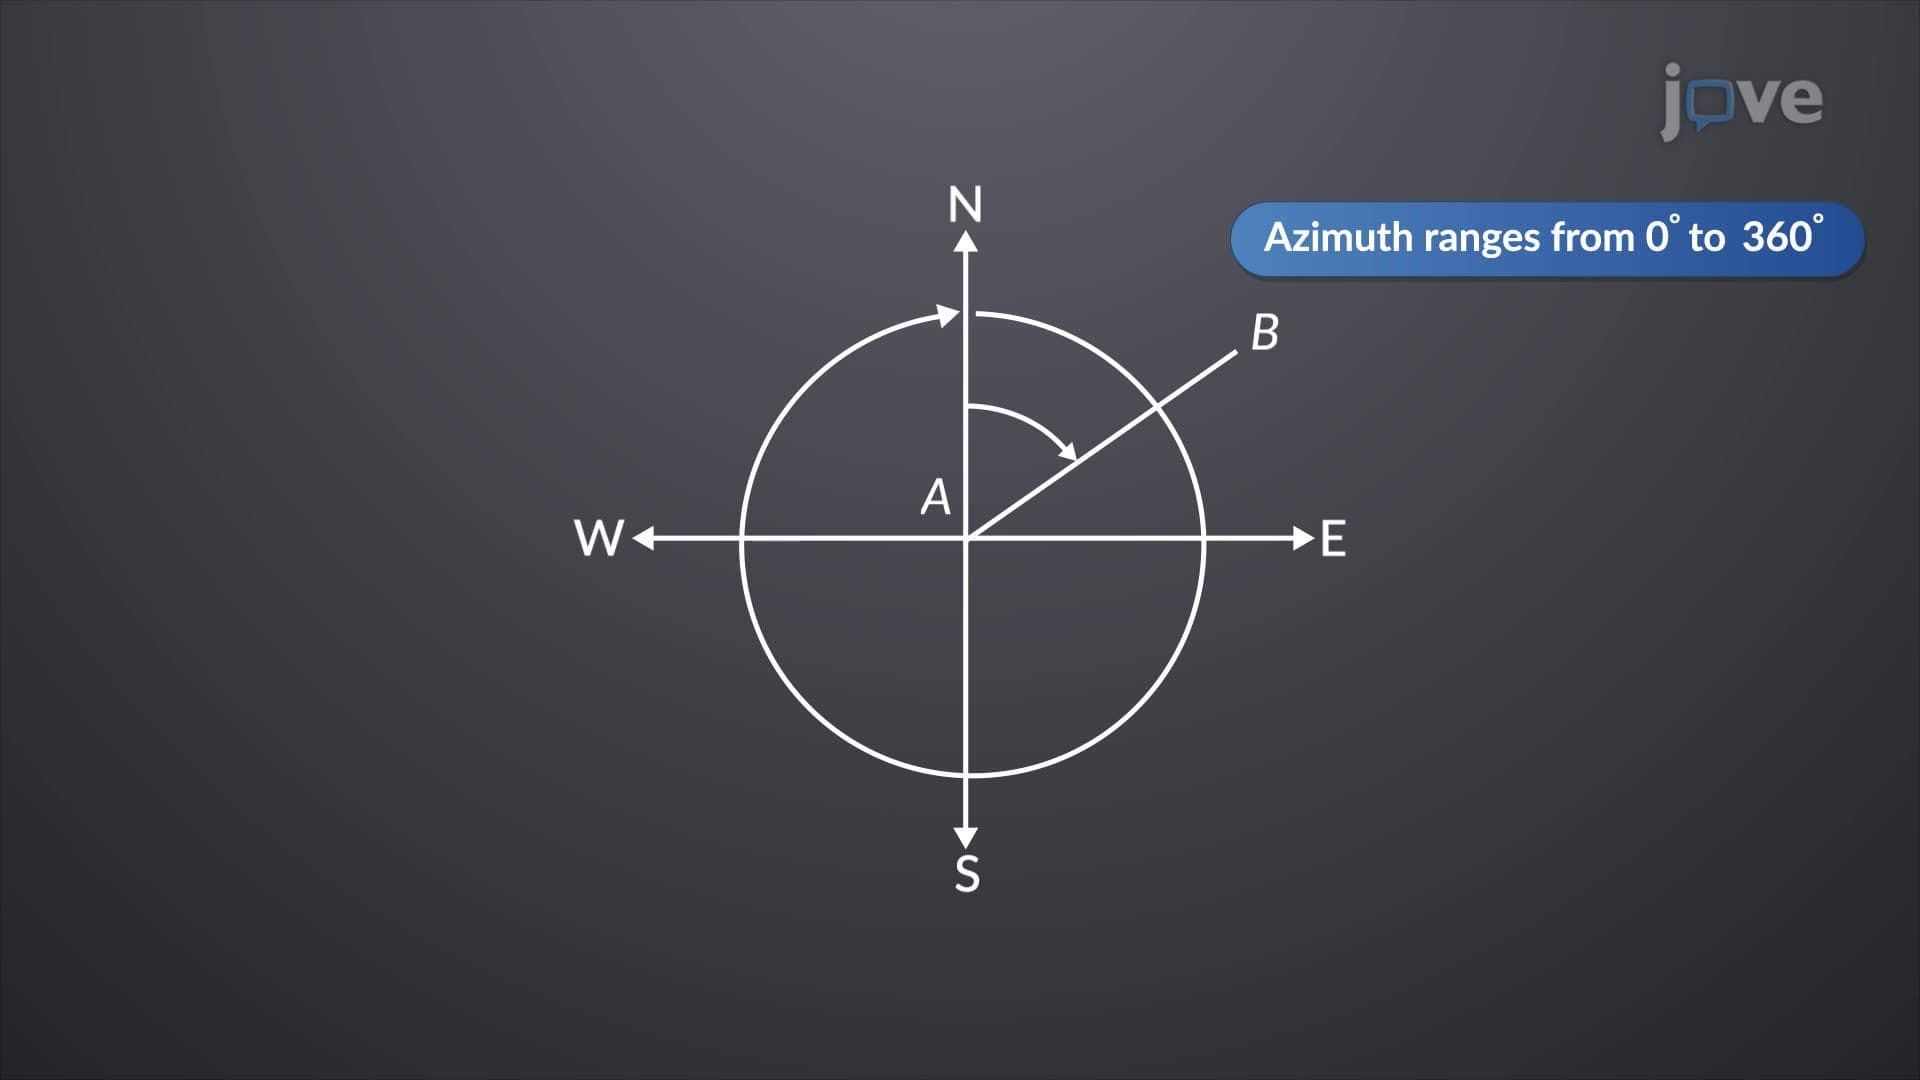
Azimuths and Bearings
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
 01:03
Inertial Frames of Reference
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...