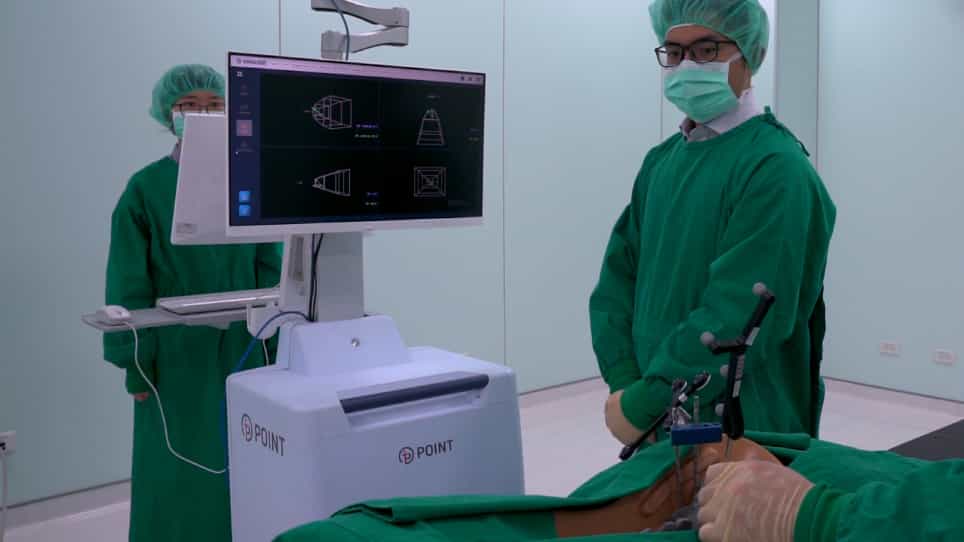
Robot arm based flat panel CT-guided electromagnetic tracked spine interventions: phantom and animal model experiments
Related Experiment Video
Updated: Jun 12, 2026
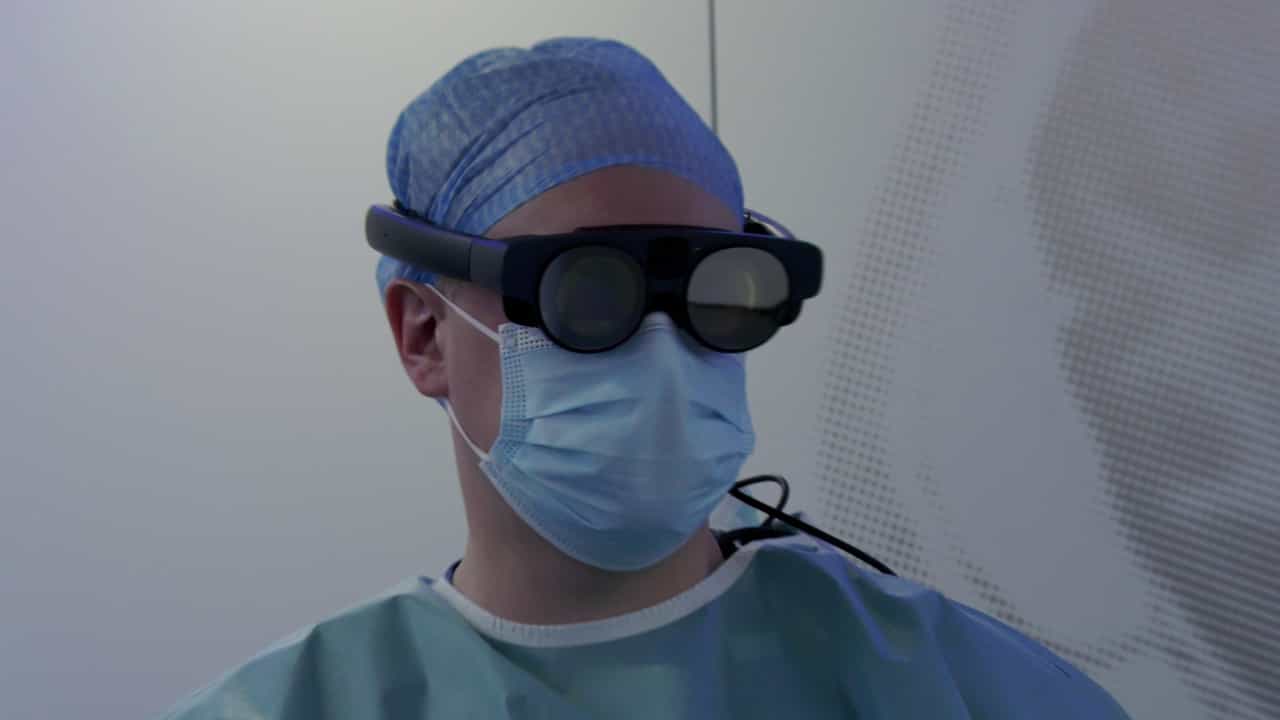
Pedicle Screw Placement Using an Augmented Reality Head-Mounted Display in a Porcine Model
Published on: May 24, 2024
Tobias Penzkofer1, Peter Isfort, Philipp Bruners
1Applied Medical Engineering, Helmholtz-Institute Aachen, RWTH Aachen University, Pauwelsstr. 20, 52074 Aachen, Germany. penzkofer@rad.rwth-aachen.de

Purpose:
To evaluate accuracy and procedure times of electromagnetic tracking (EMT) in a robotic arm mounted flat panel setting using phantom and animal cadaveric models.
Methods And Materials:
A robotic arm mounted flat panel (RMFP) was used in combination with EMT to perform anthropomorphic phantom (n = 90) and ex vivo pig based punctures (n = 120) of lumbar facet joints (FJ, n = 120) and intervertebral discs (IVD, n = 90). Procedure accuracies and times were assessed and evaluated.
Results:
FJ punctures were carried out with a spatial accuracy of 0.8 ± 0.9 mm (phantom) and 0.6 ± 0.8 mm (ex vivo) respectively. While IVD punctures showed puncture deviations of 0.6 ± 1.2 mm (phantom) and 0.5 ± 0.6 mm (ex vivo), direct and angulated phantom based punctures had accuracies of 0.8 ± 0.9 mm and 1.0 ± 1.3 mm. Planning took longer for ex vivo IVD punctures compared to phantom model interventions (39.3 ± 17.3 s vs. 20.8 ± 5.0 s, p = 0.001) and for angulated vs. direct phantom FJ punctures (19.7 ± 5.1 s vs. 28.6 ± 7.8 s, p < 0.001). Puncture times were longer for ex vivo procedures when compared to phantom model procedures in both FJ (37.9 ± 9.0 s vs. 23.6 ± 7.2 s, p = 0.001) and IVD punctures (43.9 ± 16.1 s vs. 31.1 ± 6.4 s, p = 0.026).
Conclusion:
The combination of RMFP with EMT provides an accurate method of navigation for spinal interventions such as facet joint punctures and intervertebral disc punctures.