Related Experiment Video
Updated: Jun 10, 2026
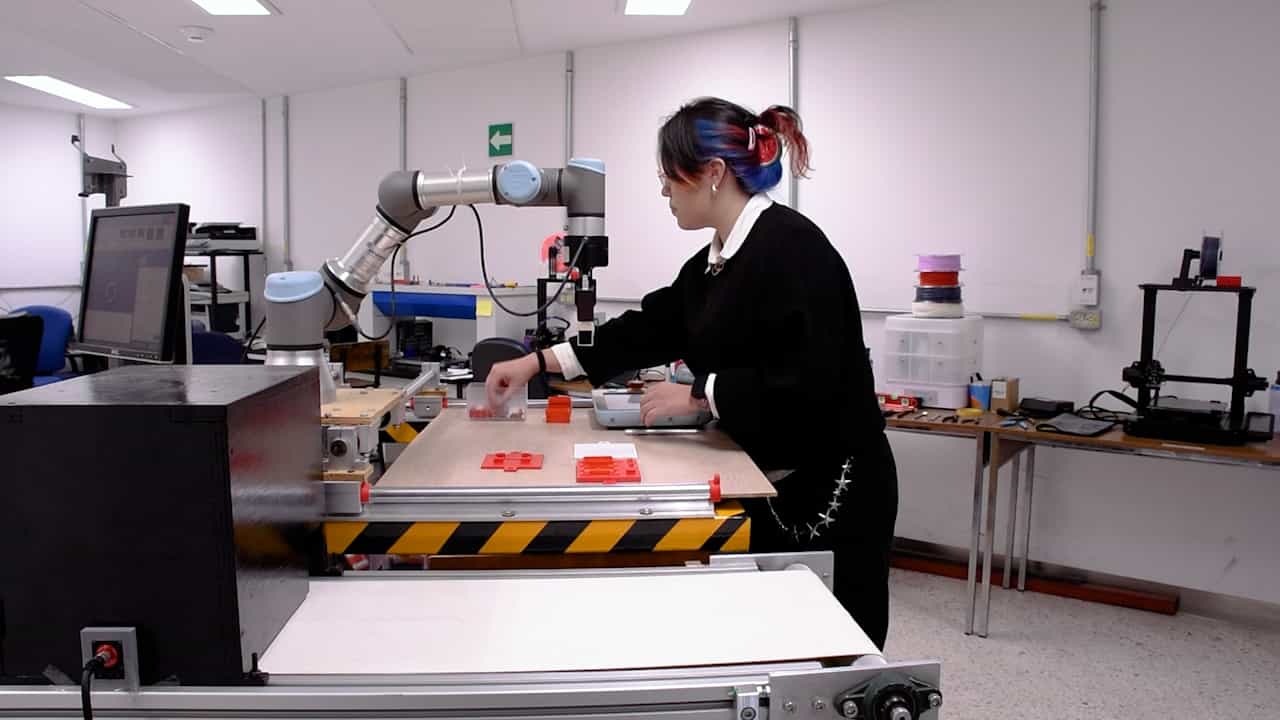

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Effects of automation and task load on task switching during human supervision of multiple semi-autonomous robots in
1Naval Surface Warfare Center, Dahglren Division, Dahlgren, Virginia, USA. peter.squire@navy.mil

Abstract:
The present study assessed the impact of task load and level of automation (LOA) on task switching in participants supervising a team of four or eight semi-autonomous robots in a simulated 'capture the flag' game. Participants were faster to perform the same task than when they chose to switch between different task actions. They also took longer to switch between different tasks when supervising the robots at a high compared to a low LOA. Task load, as manipulated by the number of robots to be supervised, did not influence switch costs. The results suggest that the design of future unmanned vehicle (UV) systems should take into account not simply how many UVs an operator can supervise, but also the impact of LOA and task operations on task switching during supervision of multiple UVs. The findings of this study are relevant for the ergonomics practice of UV systems. This research extends the cognitive theory of task switching to inform the design of UV systems and results show that switching between UVs is an important factor to consider.
