Related Experiment Video
Updated: Jun 10, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Zero-velocity detection --- an algorithm evaluation

Abstract:
In this study, we investigate the problem of detecting time epochs when zero-velocity updates can be applied in a foot-mounted inertial navigation (motion tracking) system. We examine three commonly used detectors: the acceleration moving variance detector, the acceleration magnitude detector, and the angular rate energy detector. We demonstrate that all detectors can be derived within the same general likelihood ratio test framework given the different prior knowledge about the sensor signals. Further, by combining all prior knowledge, we derive a new likelihood ratio test detector. Subsequently, we develop a methodology to evaluate the performance of the detectors. Employing the developed methodology, we evaluate the performance of the detectors using leveled ground, slow (approx. 3 km/h) and normal (approx. 5 km/h) gait data. The test results are presented in terms of detection versus false-alarm probability. Our preliminary results shows that the new detector performs marginally better than the angular rate energy detector that outperforms both the acceleration moving variance detector and the acceleration magnitude detector.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:29
Distance Problem
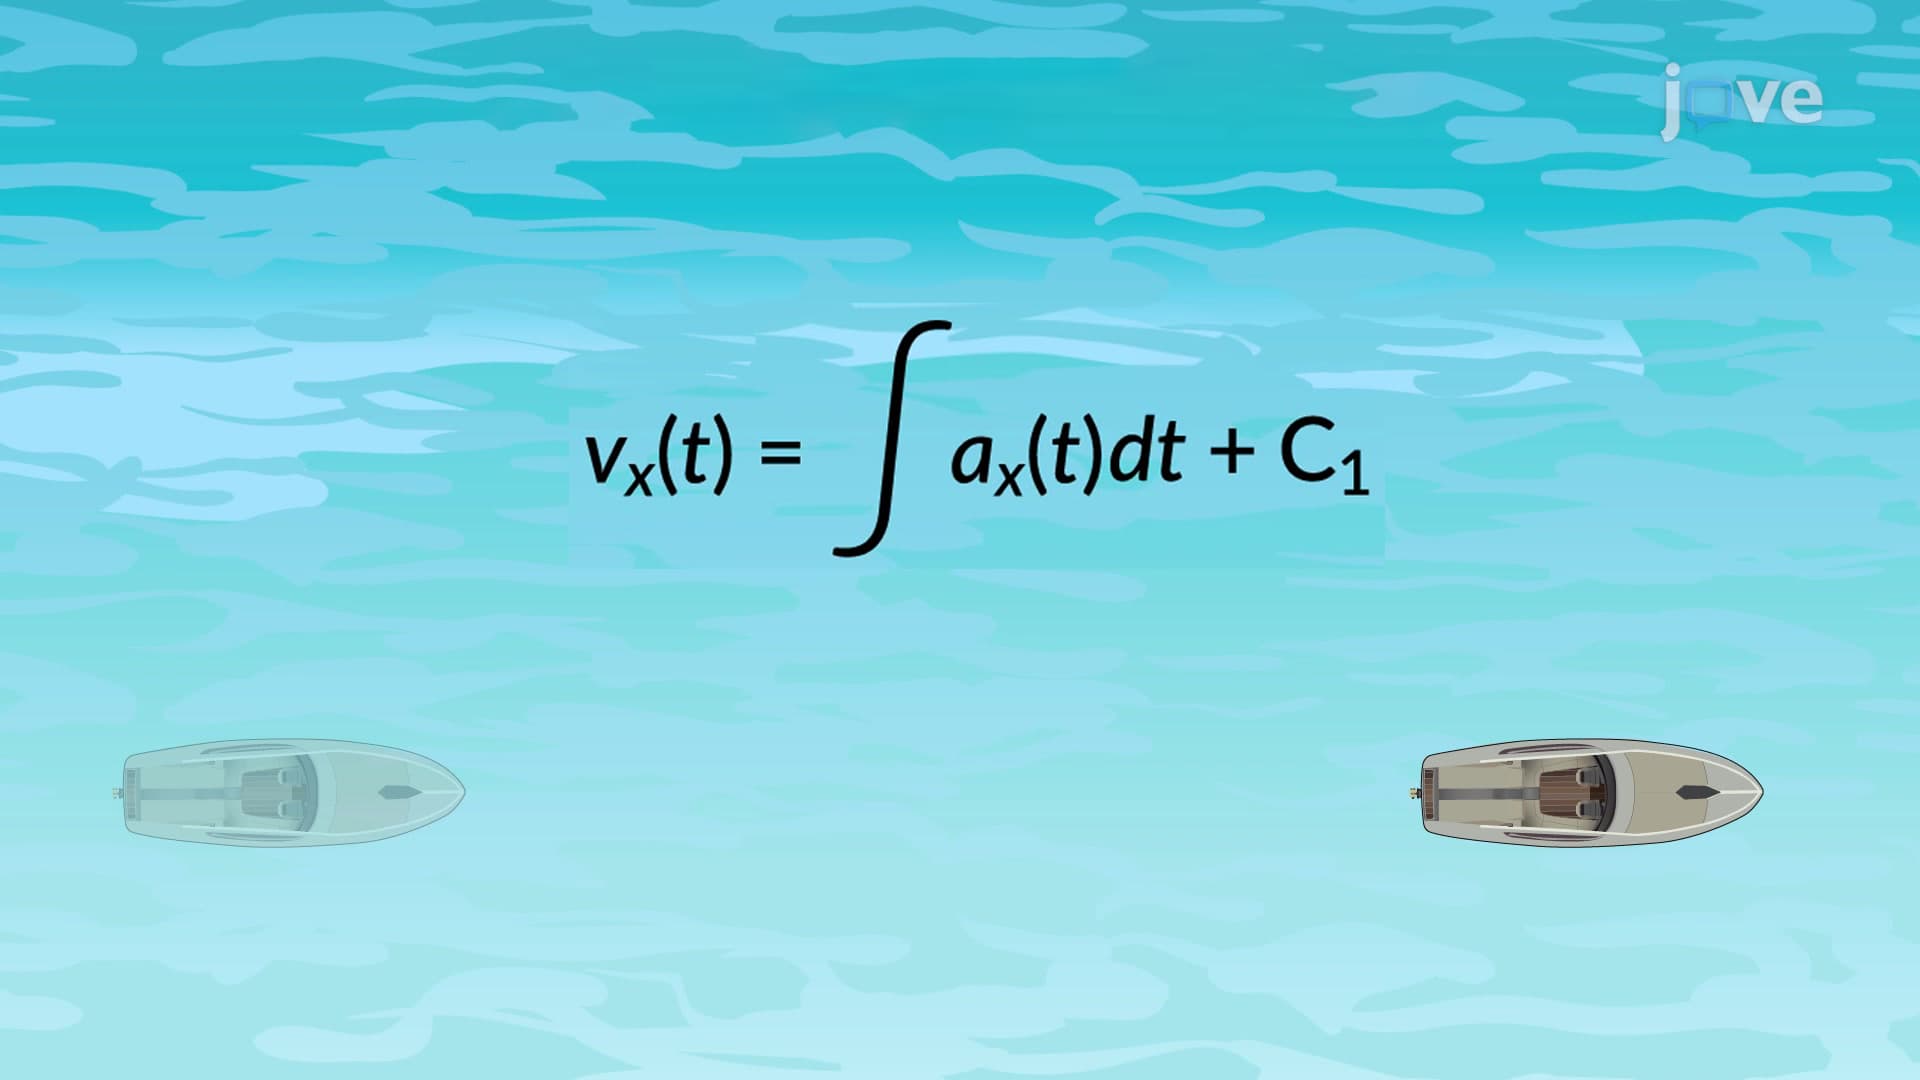 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...