Related Experiment Video
Updated: Jun 10, 2026
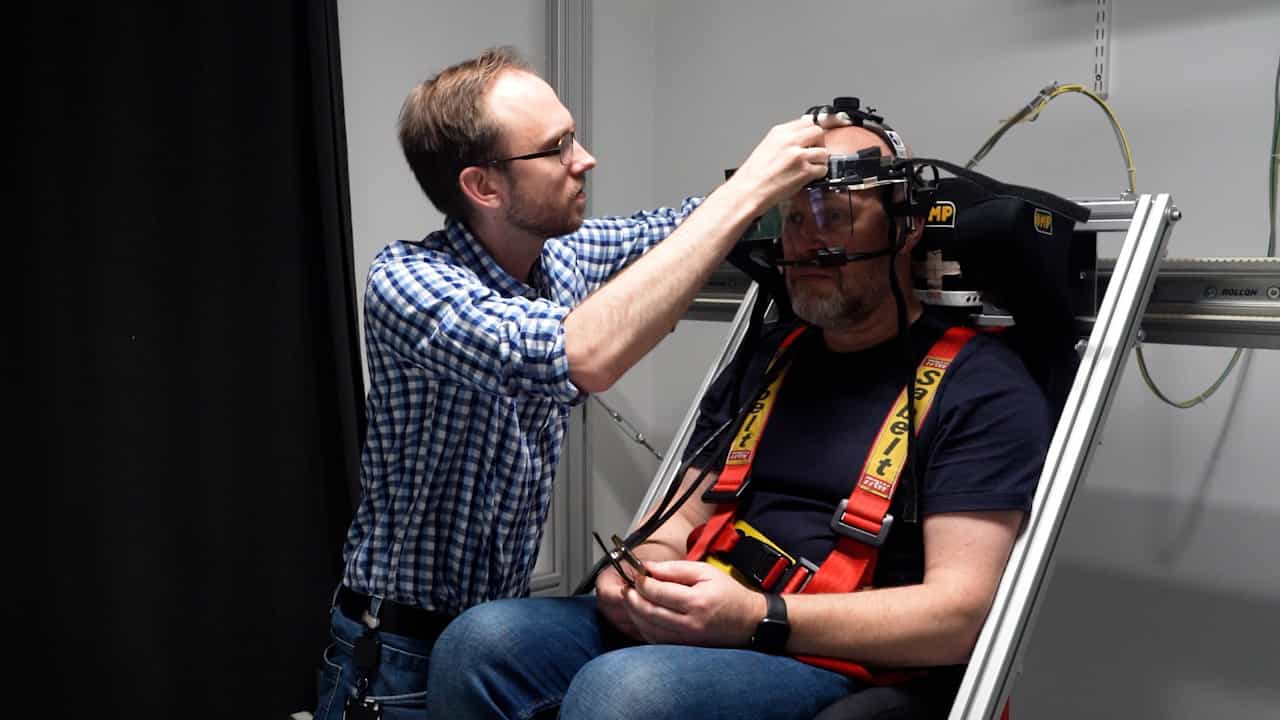

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Control theoretic interpretation of directional motion preferences in optic flow processing interneurons
Andrew Hyslop1, Holger G Krapp, J Sean Humbert
1Department of Aerospace Engineering, University of Maryland, College Park, MD 20742, USA. ahyslop@umd.edu

Abstract:
In this article, we formalize the processing of optic flow in identified fly lobula plate tangential cells and develop a control theoretic framework that suggests how the signals of these cells may be combined and used to achieve reflex-like navigation behavior. We show that this feedback gain synthesis task can be cast as a combined static state estimation and linear feedback control problem. Our framework allows us to analyze and determine the relationship between optic flow measurements and actuator commands, which greatly simplifies the implementation of biologically inspired control architectures on terrestrial and aerial robotic platforms.
Related Concept Videos
 01:24
Vision
 01:25
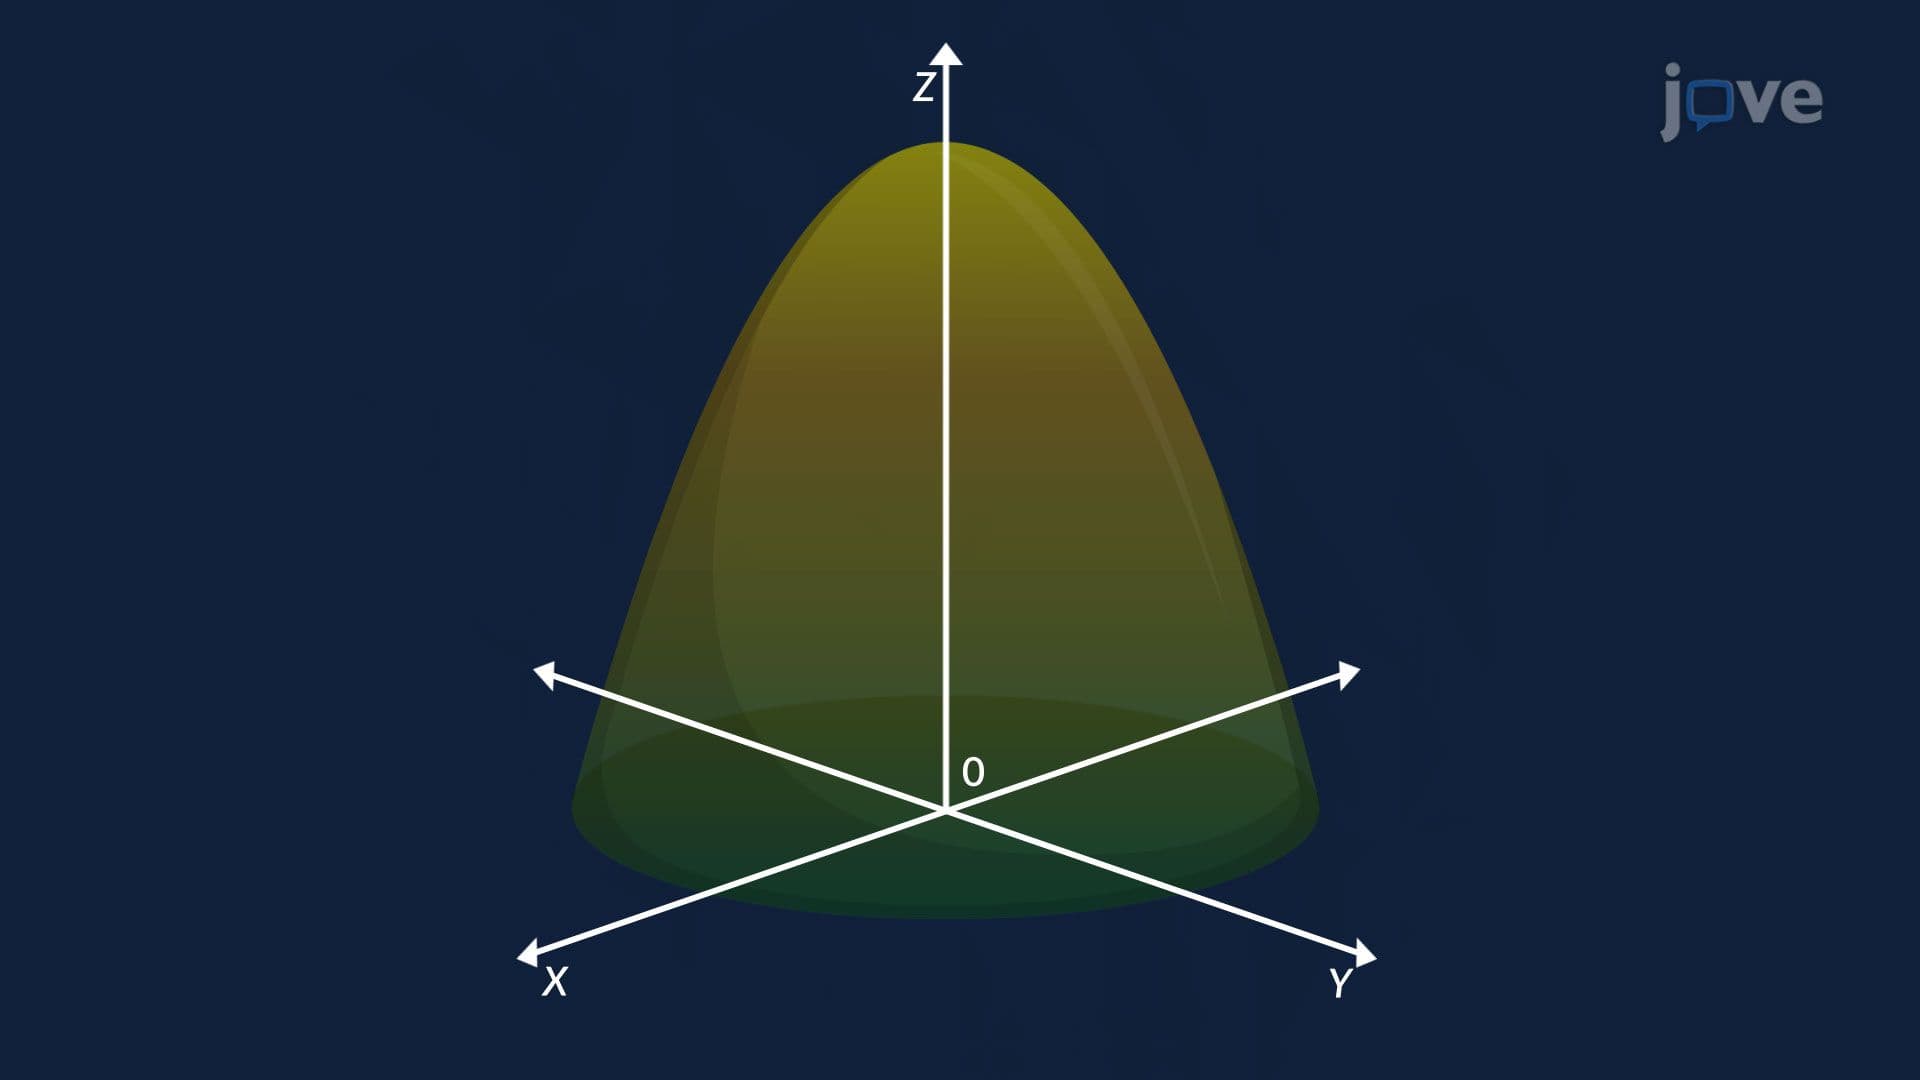
Maximizing the Directional Derivative
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
01:05Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:27
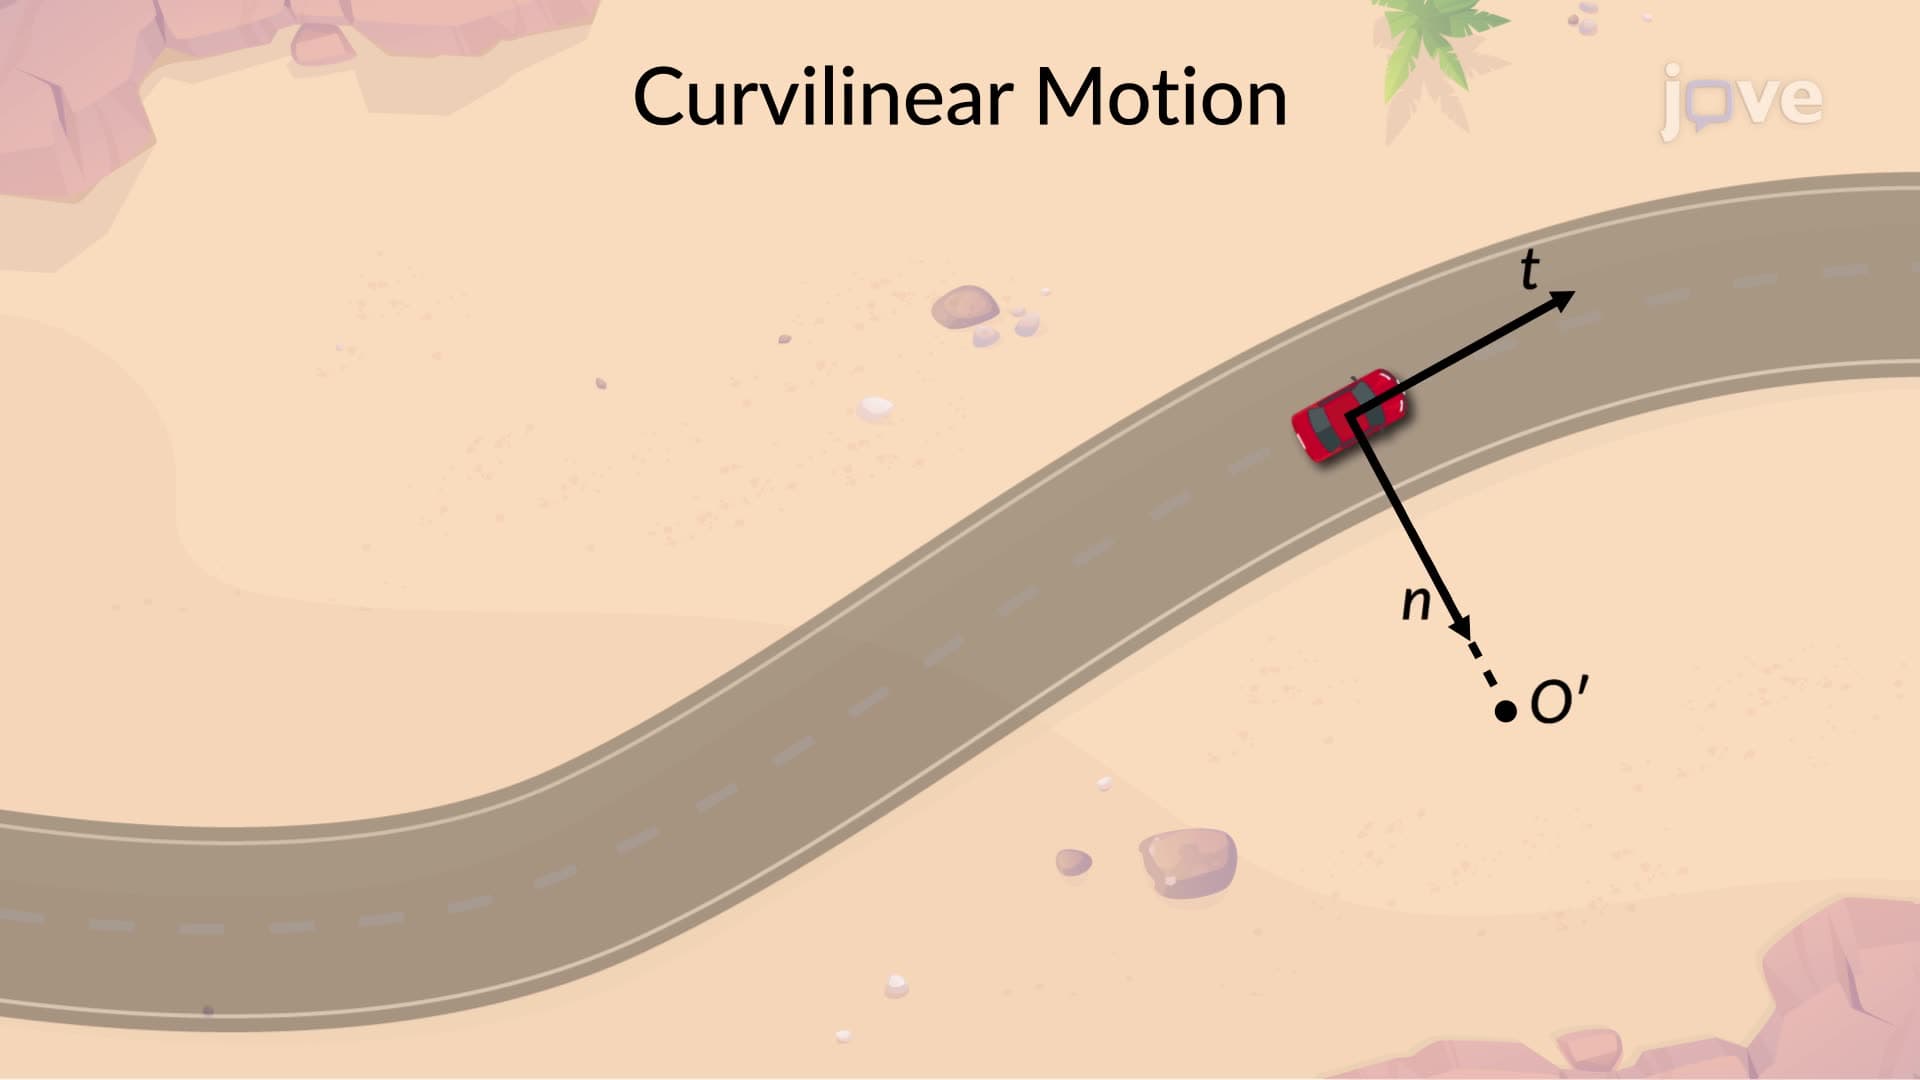
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...