Related Experiment Video
Updated: Jun 10, 2026
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
Motor synergies and the equilibrium-point hypothesis
1Department of Kinesiology, The Pennsylvania State University, University Park, PA.

Abstract:
The article offers a way to unite three recent developments in the field of motor control and coordination: (1) The notion of synergies is introduced based on the principle of motor abundance; (2) The uncontrolled manifold hypothesis is described as offering a computational framework to identify and quantify synergies; and (3) The equilibrium-point hypothesis is described for a single muscle, single joint, and multijoint systems. Merging these concepts into a single coherent scheme requires focusing on control variables rather than performance variables. The principle of minimal final action is formulated as the guiding principle within the referent configuration hypothesis. Motor actions are associated with setting two types of variables by a controller, those that ultimately define average performance patterns and those that define associated synergies. Predictions of the suggested scheme are reviewed, such as the phenomenon of anticipatory synergy adjustments, quick actions without changes in synergies, atypical synergies, and changes in synergies with practice. A few models are briefly reviewed.
Related Concept Videos
 01:13
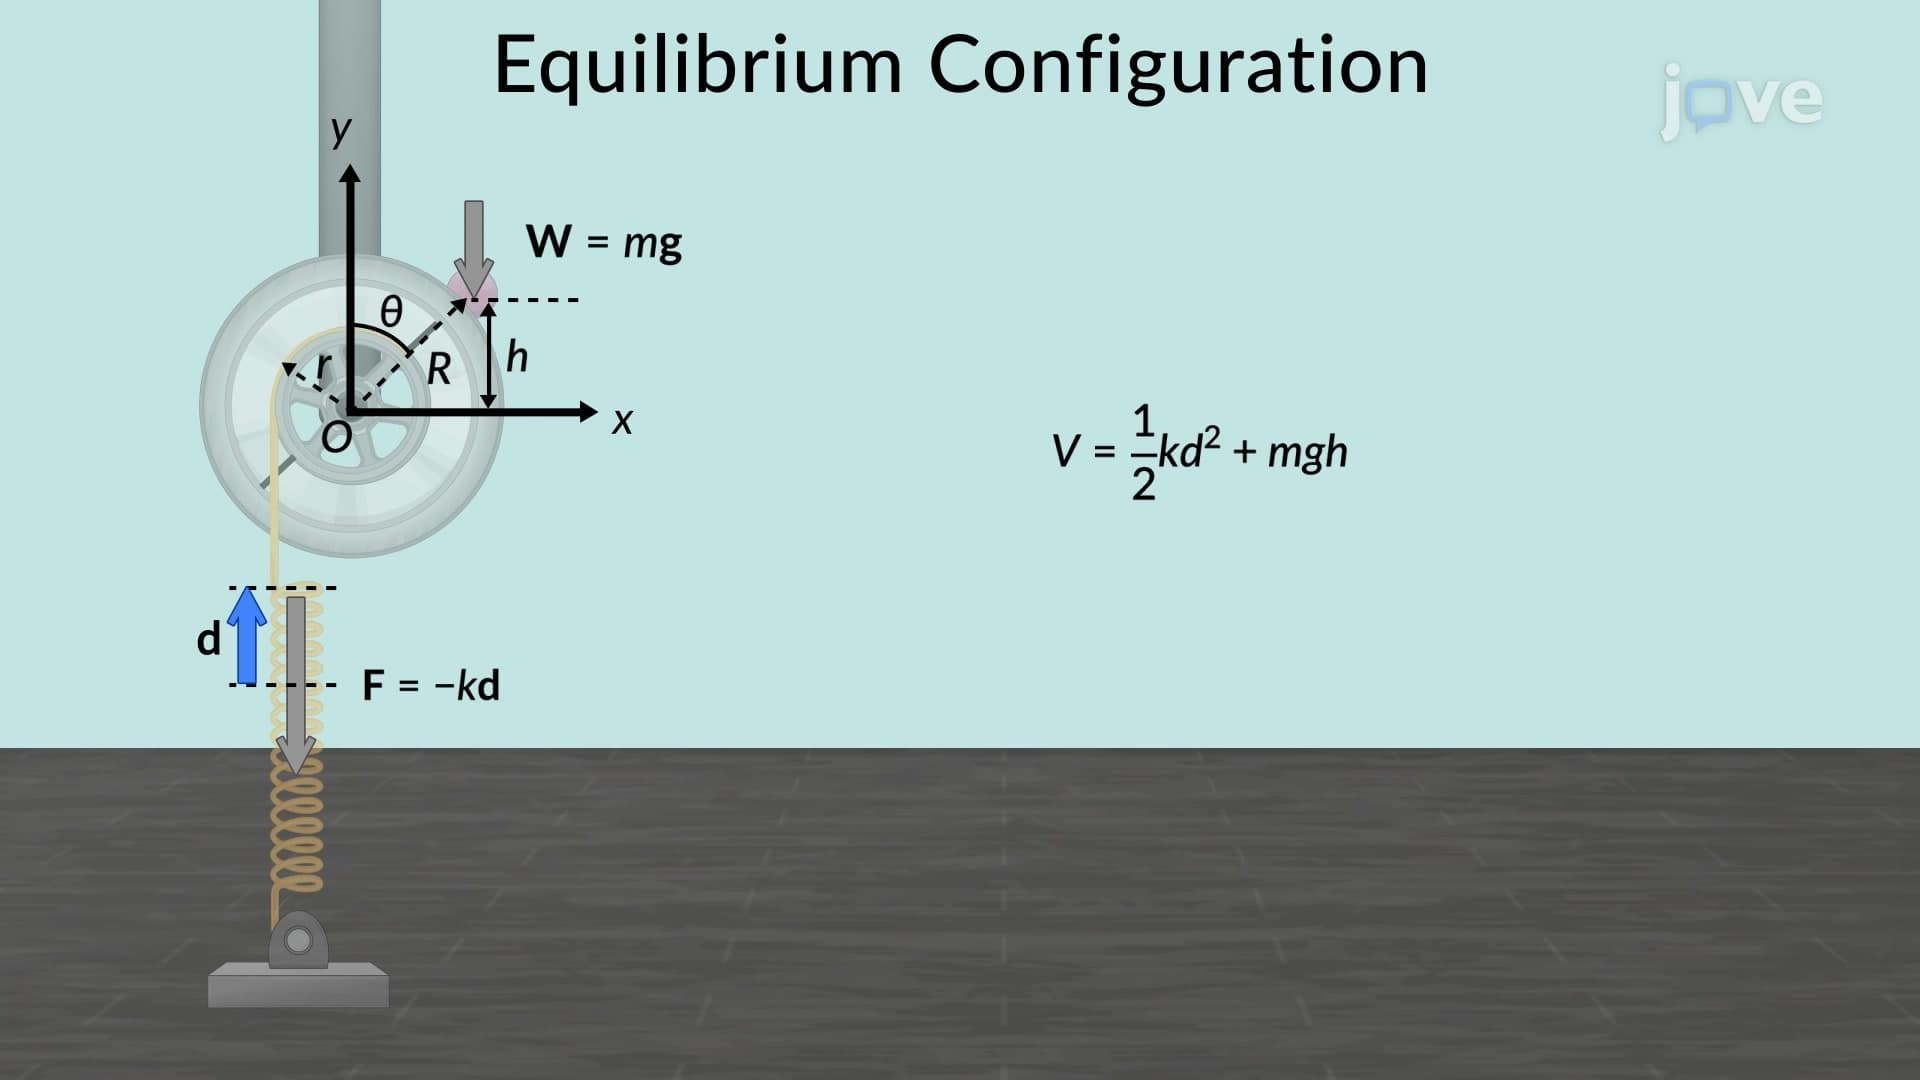
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:04
Oscillations about an Equilibrium Position
 01:30
Categories of Equilibrium
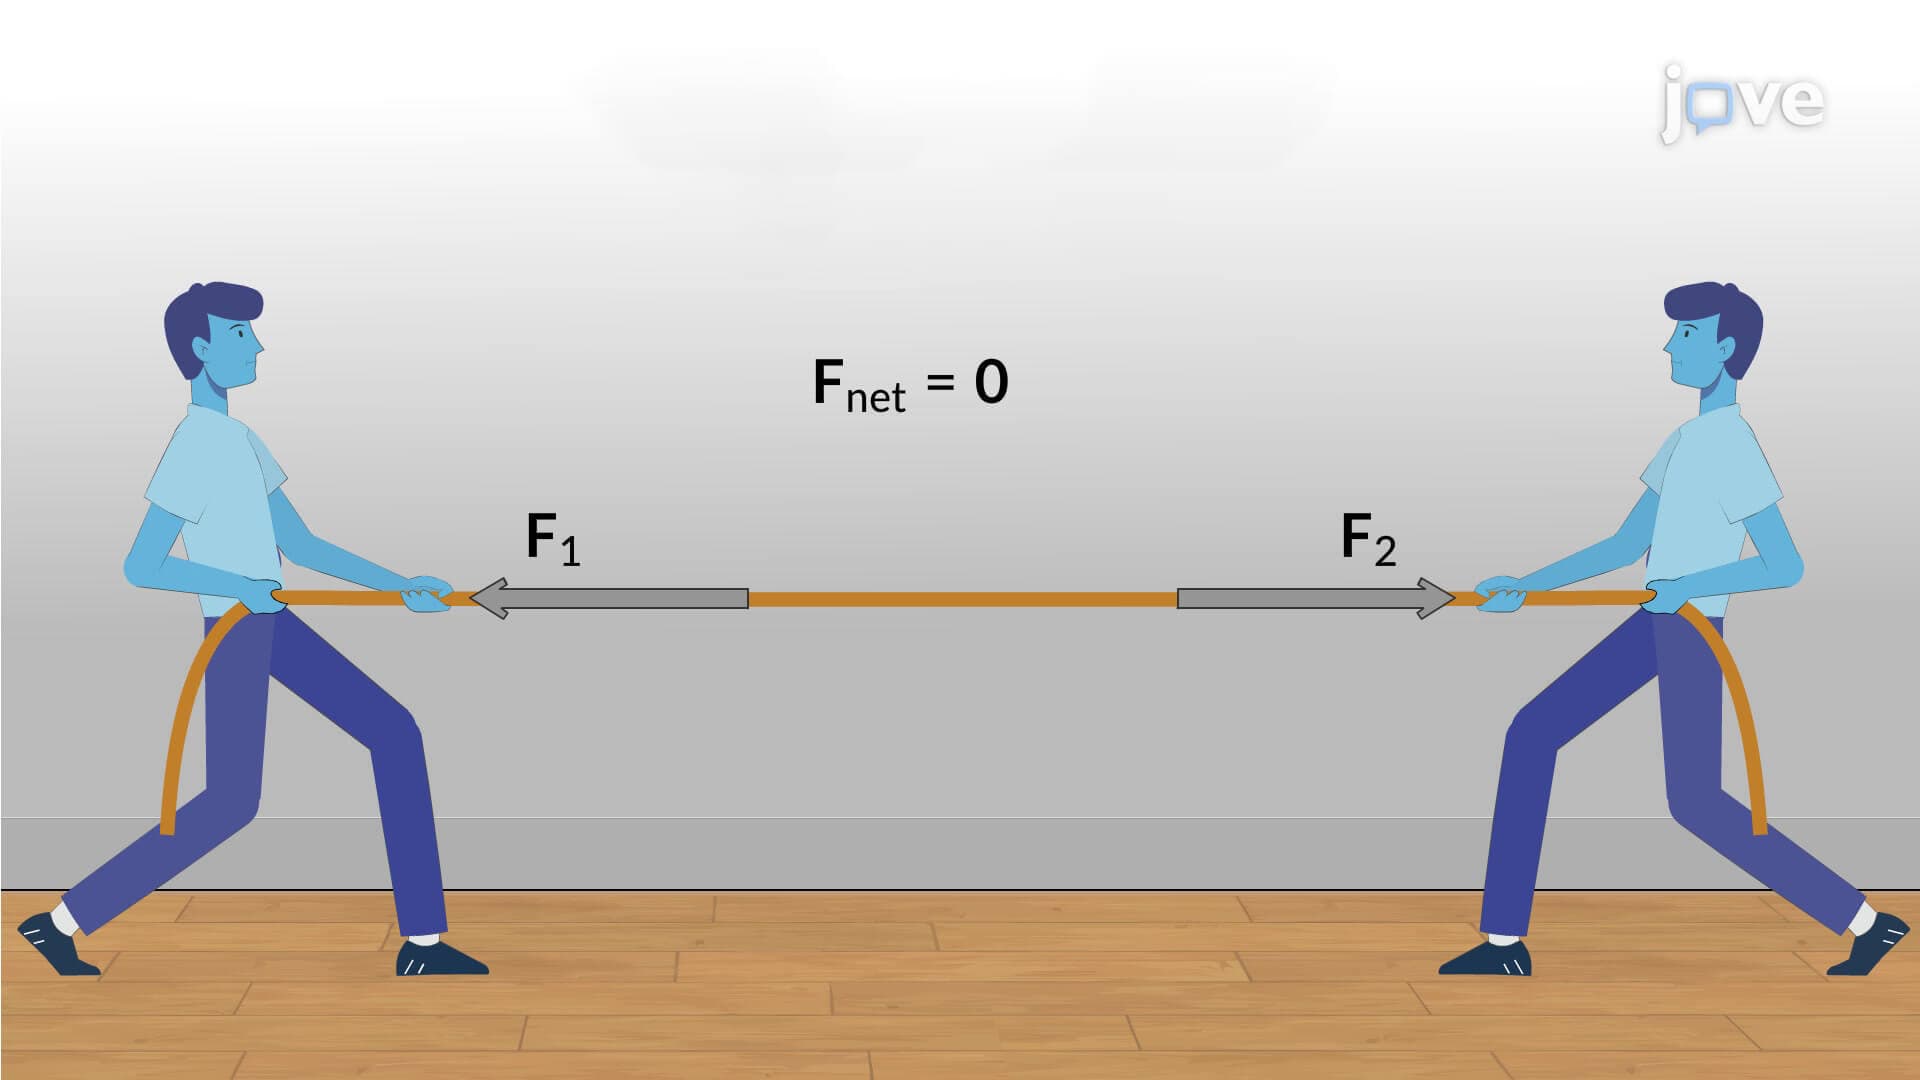
One of the categories of equilibrium is collinear equilibrium, which involves forces acting along a straight line. This type of equilibrium requires only one force equation in the direction of the forces, as the other equations are...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:21
Rigid Body Equilibrium Problems - II
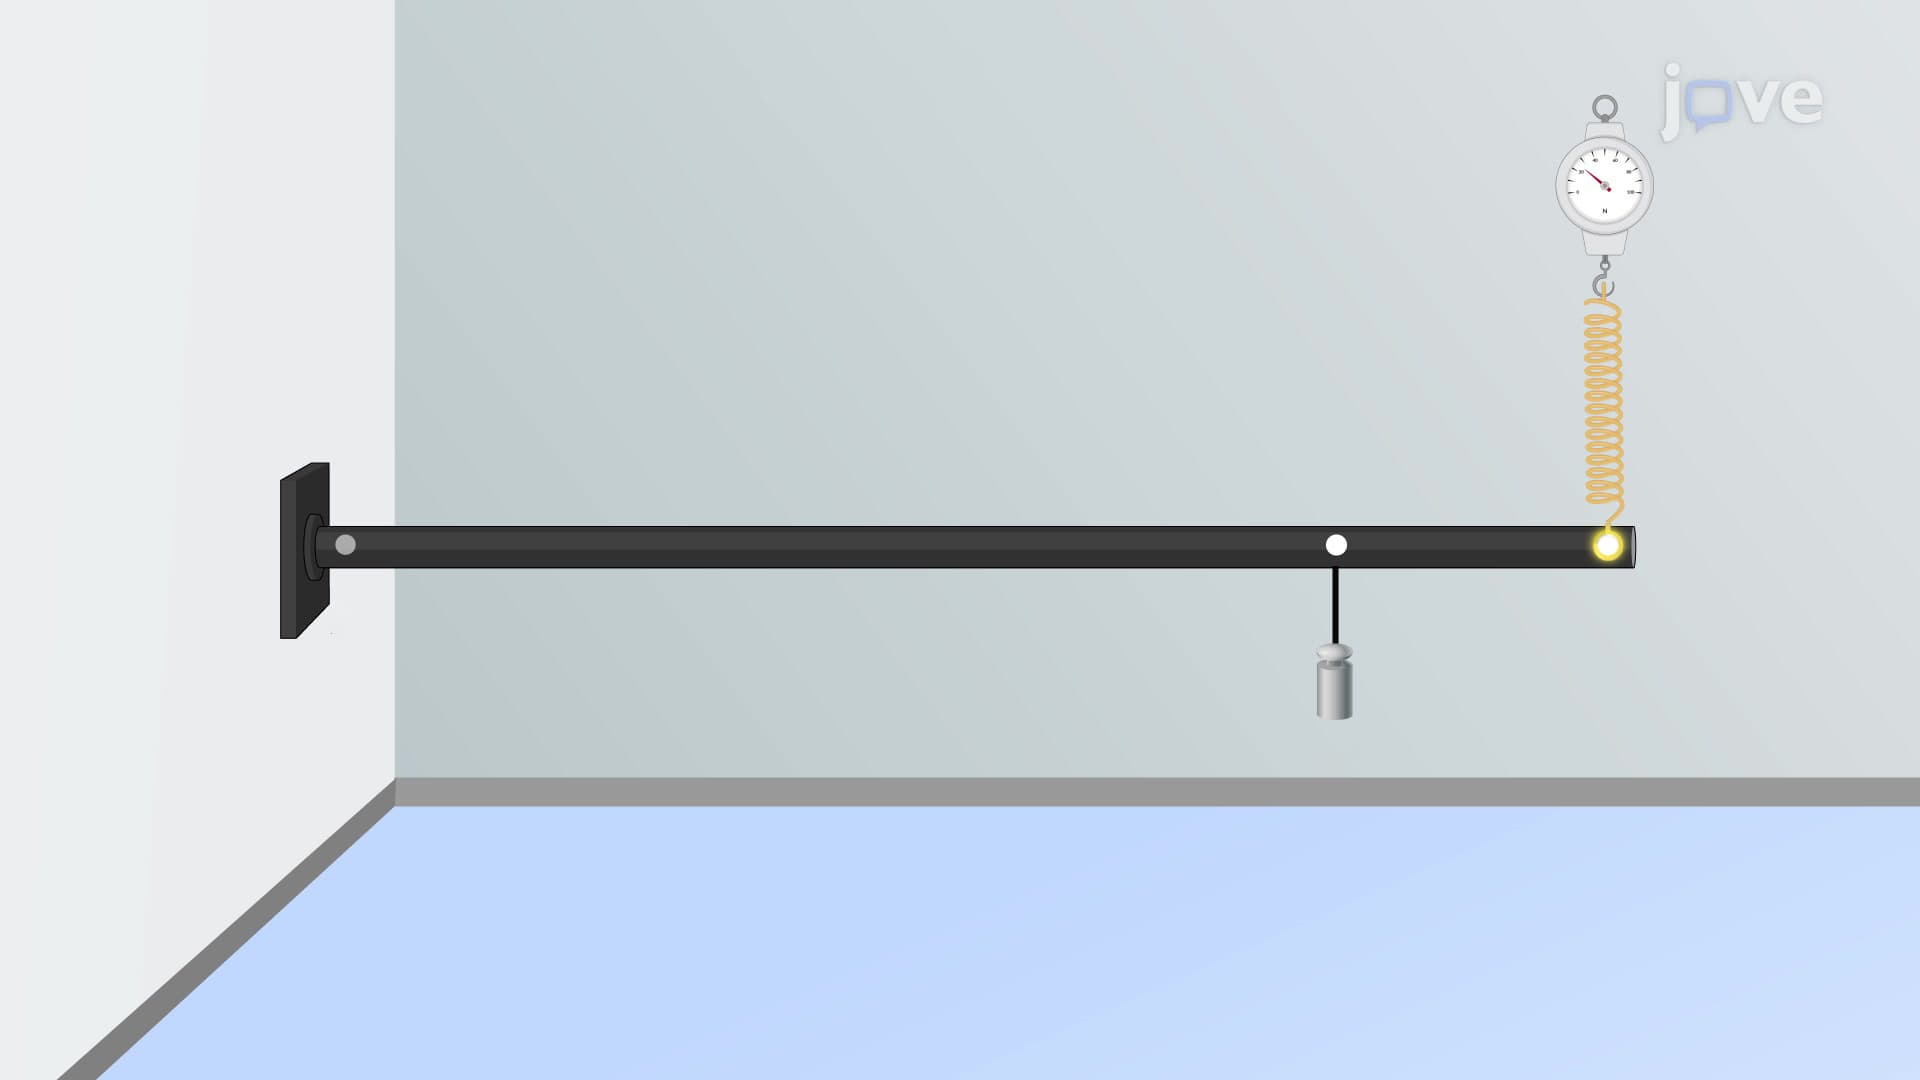
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?