A fast bilinear structure from motion algorithm using a video sequence and inertial sensors
Related Experiment Video
Updated: Jun 9, 2026
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
Mahesh Ramachandran1, Ashok Veeraraghavan, Rama Chellappa
1Qualcomm Inc., 5775 Morehouse Dr., San Diego, CA 92121-1714, USA. maheshr@umiacs.umd.edu

Abstract:
In this paper, we study the benefits of the availability of a specific form of additional information—the vertical direction (gravity) and the height of the camera, both of which can be conveniently measured using inertial sensors and a monocular video sequence for 3D urban modeling. We show that in the presence of this information, the SfM equations can be rewritten in a bilinear form. This allows us to derive a fast, robust, and scalable SfM algorithm for large scale applications. The SfM algorithm developed in this paper is experimentally demonstrated to have favorable properties compared to the sparse bundle adjustment algorithm. We provide experimental evidence indicating that the proposed algorithm converges in many cases to solutions with lower error than state-of-art implementations of bundle adjustment. We also demonstrate that for the case of large reconstruction problems, the proposed algorithm takes lesser time to reach its solution compared to bundle adjustment. We also present SfM results using our algorithm on the Google StreetView research data set.
Related Concept Videos
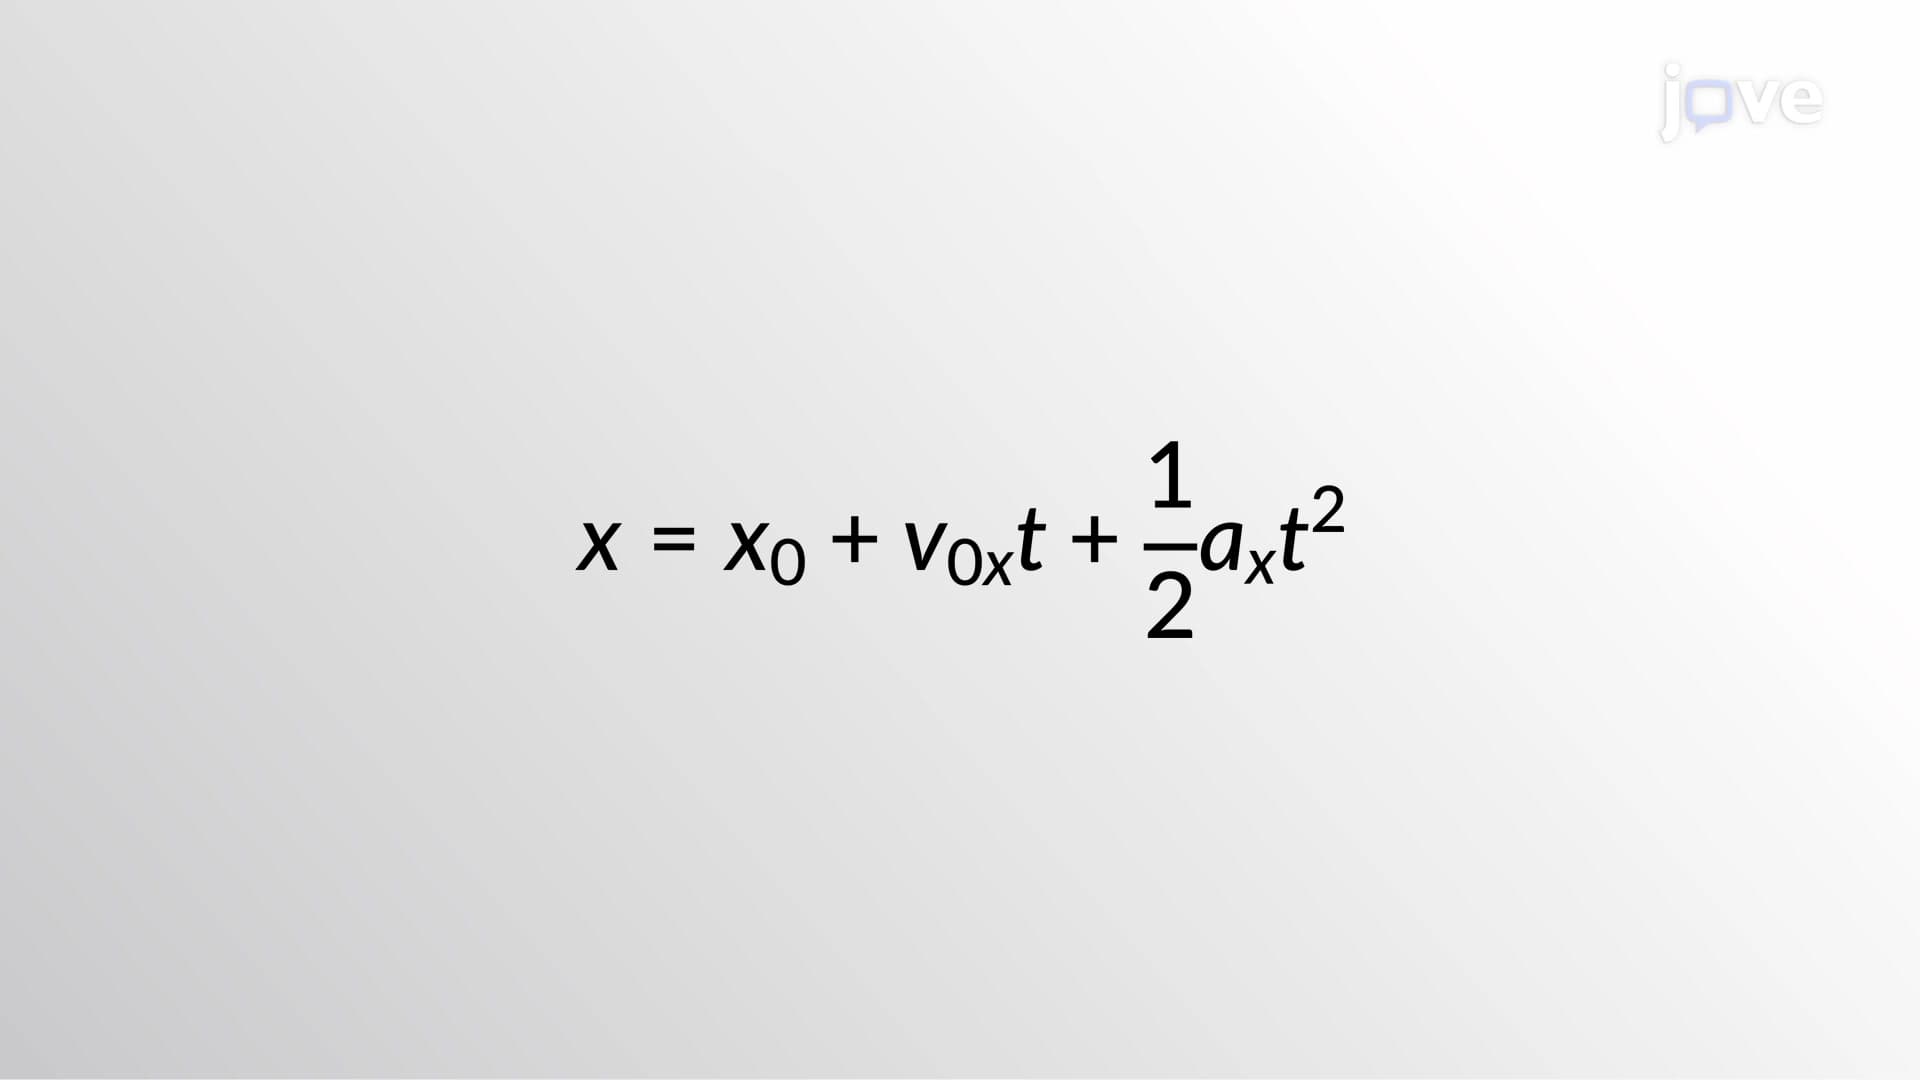 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
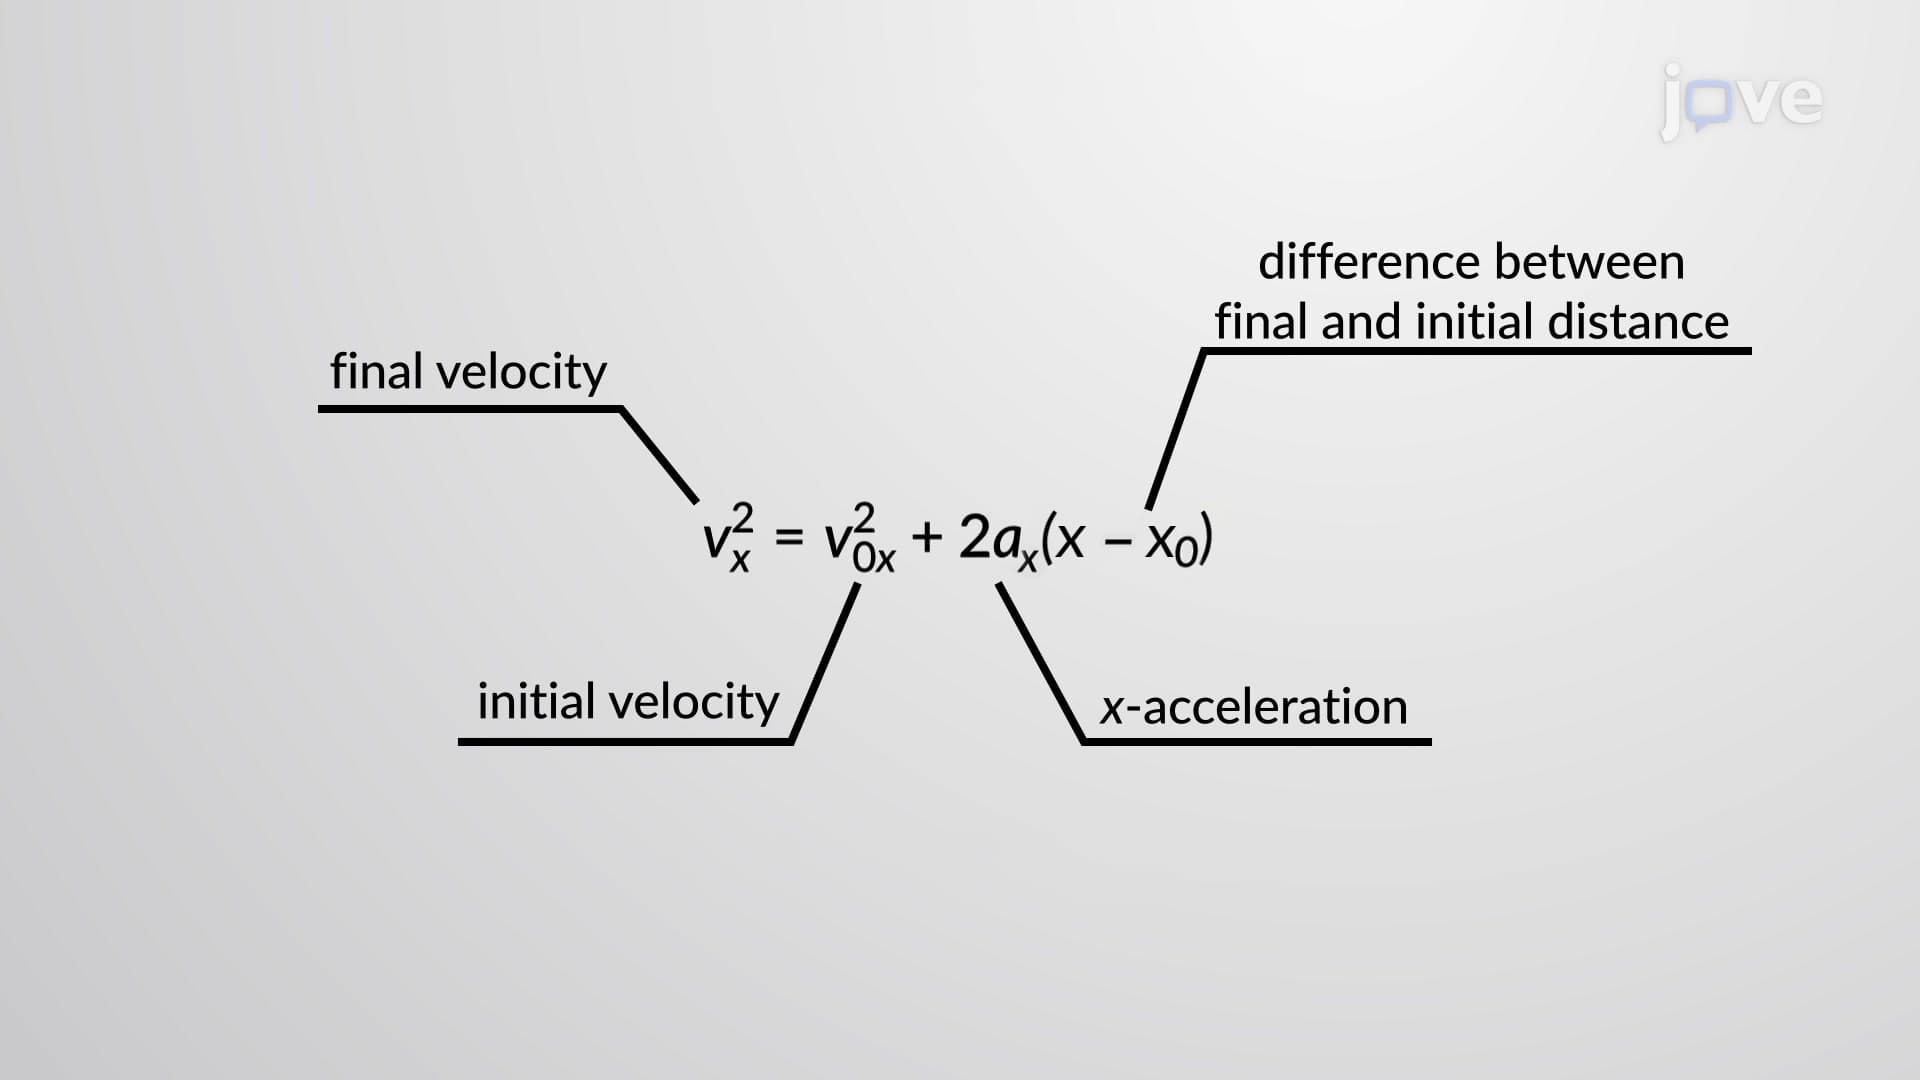
Kinematic Equations - III
Using the kinematic equations,...
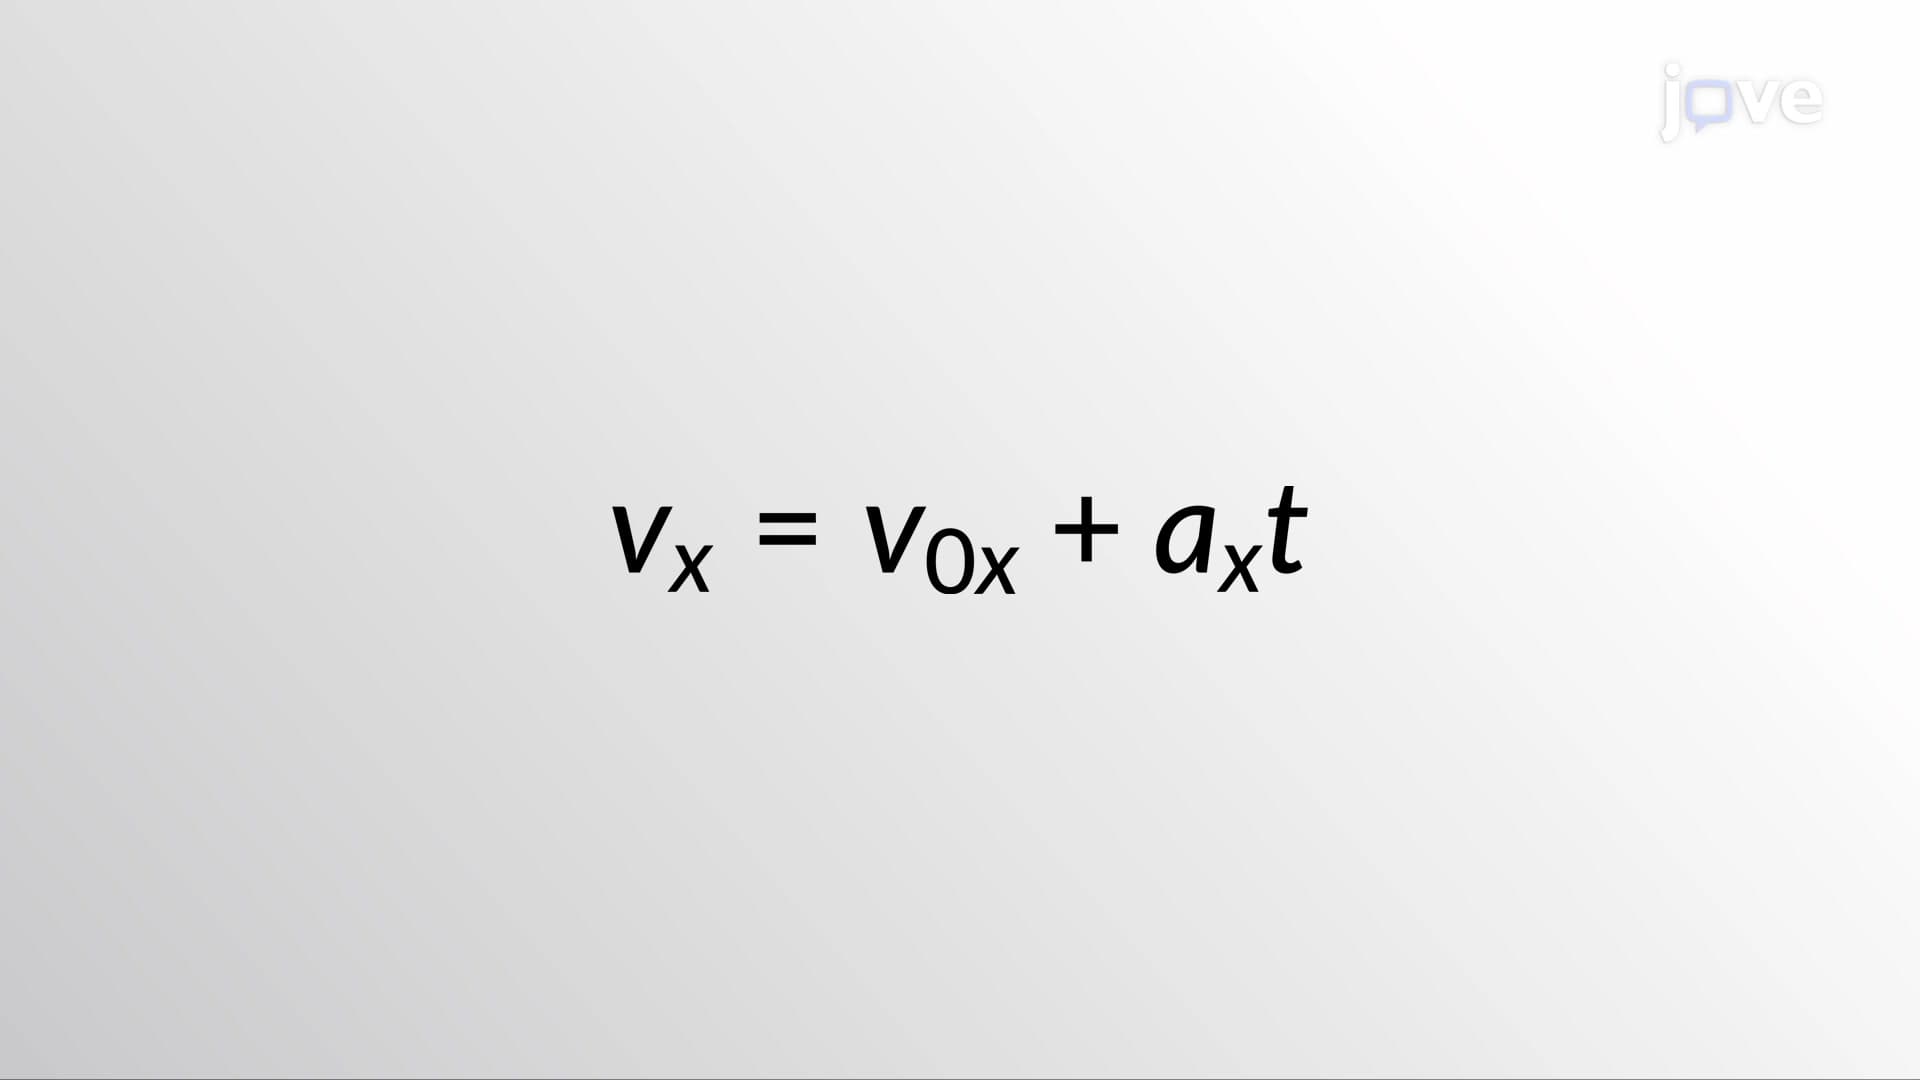 01:26
Kinematic Equations - I
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:15
Kinematic Equations: Problem Solving