Related Experiment Video
Updated: Jun 8, 2026

Measuring Sensitivity to Viewpoint Change with and without Stereoscopic Cues
Published on: December 4, 2013
Anisotropies in judging the direction of moving natural scenes
Steven C Dakin1, Deborah Apthorp, David Alais
1Institute of Ophthalmology, University College London, London, UK. s.dakin@ucl.ac.uk

Abstract:
Although visual systems are optimized to deal with the natural visual environment, our understanding of human motion perception is in large part based on the use of artificial stimuli. Here, we assessed observers' ability to estimate the direction of translating natural images and fractals by having them adjust the orientation of a subsequently viewed line. A system of interleaved staircases, driven by observers' direction estimates, ensured that stimuli were presented near one of 16 reference directions. The resulting error distributions (i.e., the differences between reported and true directions) reveal several anisotropies in global motion processing. First, observers' estimates are biased away from cardinal directions (reference repulsion). Second, the standard deviations of estimates show an "oblique effect" being ∼45% lower around cardinal directions. Third, errors around cardinal directions are more likely (∼22%) to approach zero than would be consistent with Gaussian-distributed errors, suggesting that motion processing minimizes the number as well as magnitude of errors. Fourth, errors are similar for natural scenes and fractals, indicating that observers do not use top-down information to improve performance. Finally, adaptation to unidirectional motion modifies observers' bias by amplifying existing repulsion (e.g., around cardinal directions). This bias change can improve direction discrimination but is not due to a reduction in variability.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:27
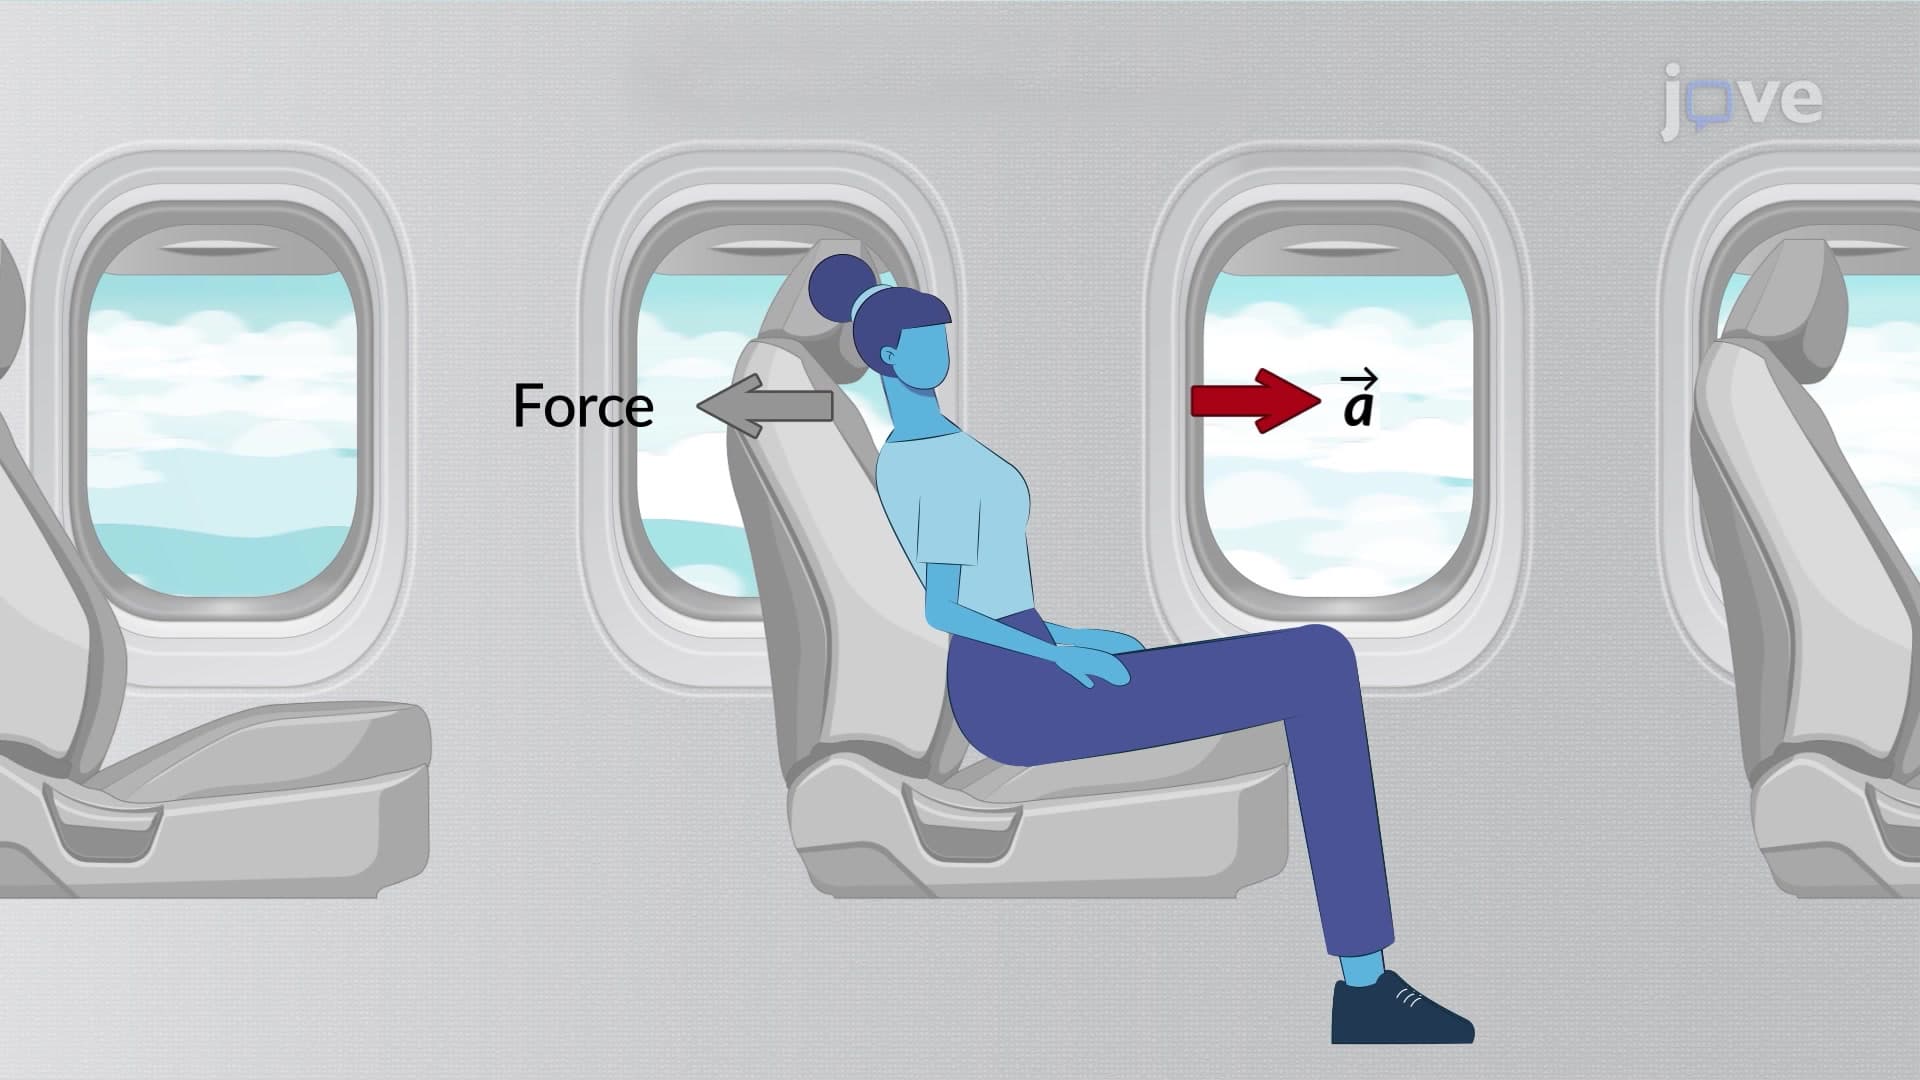
Non-inertial Frames of Reference
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:22
Local Attraction
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...