Related Experiment Video
Updated: Jun 8, 2026
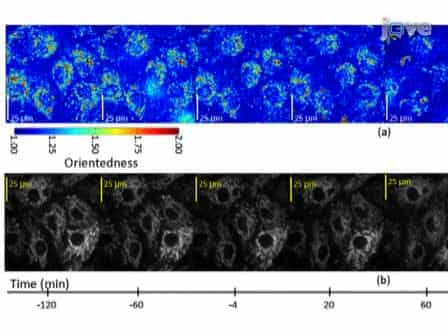

Optical Scatter Microscopy Based on Two-Dimensional Gabor Filters
Published on: June 2, 2010
Admittance of rugate filters derived from a 2 × 2 inhomogeneous matrix

Abstract:
Admittance diagrams are used to analyze qualitatively and quantitatively the behavior of inhomogeneous thin films with an arbitrary refractive-index function. From this study it follows that one can treat the behavior of rugate filters by using the concept of effective refractive indices, which are associated with the phase integral in a simple way. These results are applied to the study of periodic systems, and, as expected, one can consider high and low effective refractive indices to determine the important parameters of these stop bands. With these ideas it is possible that one can deal with rugate filters more closely as homogeneous periodic systems by taking advantage of the existing theory.
Related Concept Videos
 01:19
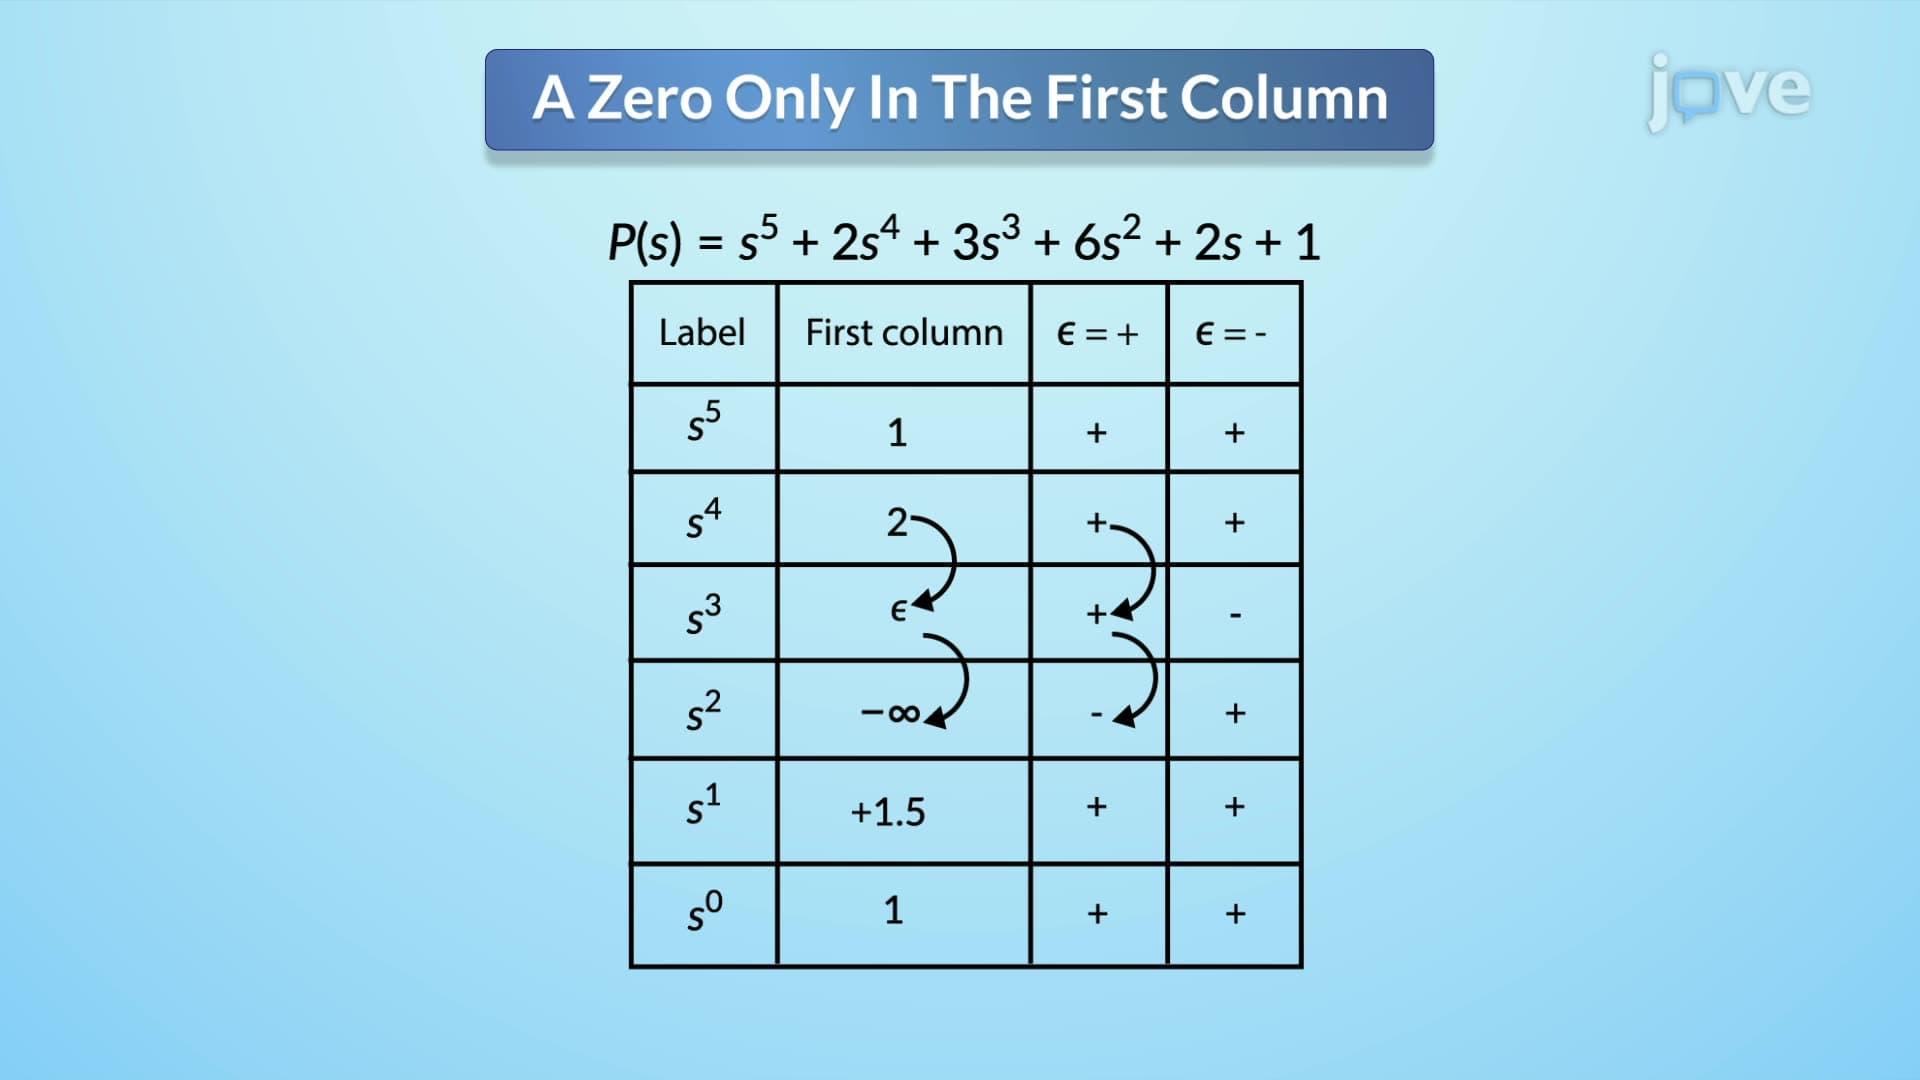
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first column of the Routh...
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:25
Active Filters
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:24
Bus Impedance Matrix
In the first circuit, all machine voltage sources are short-circuited, leaving only the prefault voltage source at the fault location. The positive-sequence bus impedance matrix can be determined by solving the nodal equations,...