

Stride-to-stride energy regulation for robust self-stability of a torque-actuated dissipative spring-mass hopper
M Mert Ankarali1, Uluç Saranli
1Department of Electrical and Electronics Engineering, Middle East Technical University, 06531 Ankara, Turkey. ankarali@eee.metu.edu.tr

Abstract:
In this paper, we analyze the self-stability properties of planar running with a dissipative spring-mass model driven by torque actuation at the hip. We first show that a two-dimensional, approximate analytic return map for uncontrolled locomotion with this system under a fixed touchdown leg angle policy and an open-loop ramp torque profile exhibits only marginal self-stability that does not always persist for the exact system. We then propose a per-stride feedback strategy for the hip torque that explicitly compensates for damping losses, reducing the return map to a single dimension and substantially improving the robust stability of fixed points. Subsequent presentation of simulation evidence establishes that the predictions of this approximate model are consistent with the behavior of the exact plant model. We illustrate the relevance and utility of our model both through the qualitative correspondence of its predictions to biological data as well as its use in the design of a task-level running controller.
Related Concept Videos
 01:14
Stability of structures
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:17
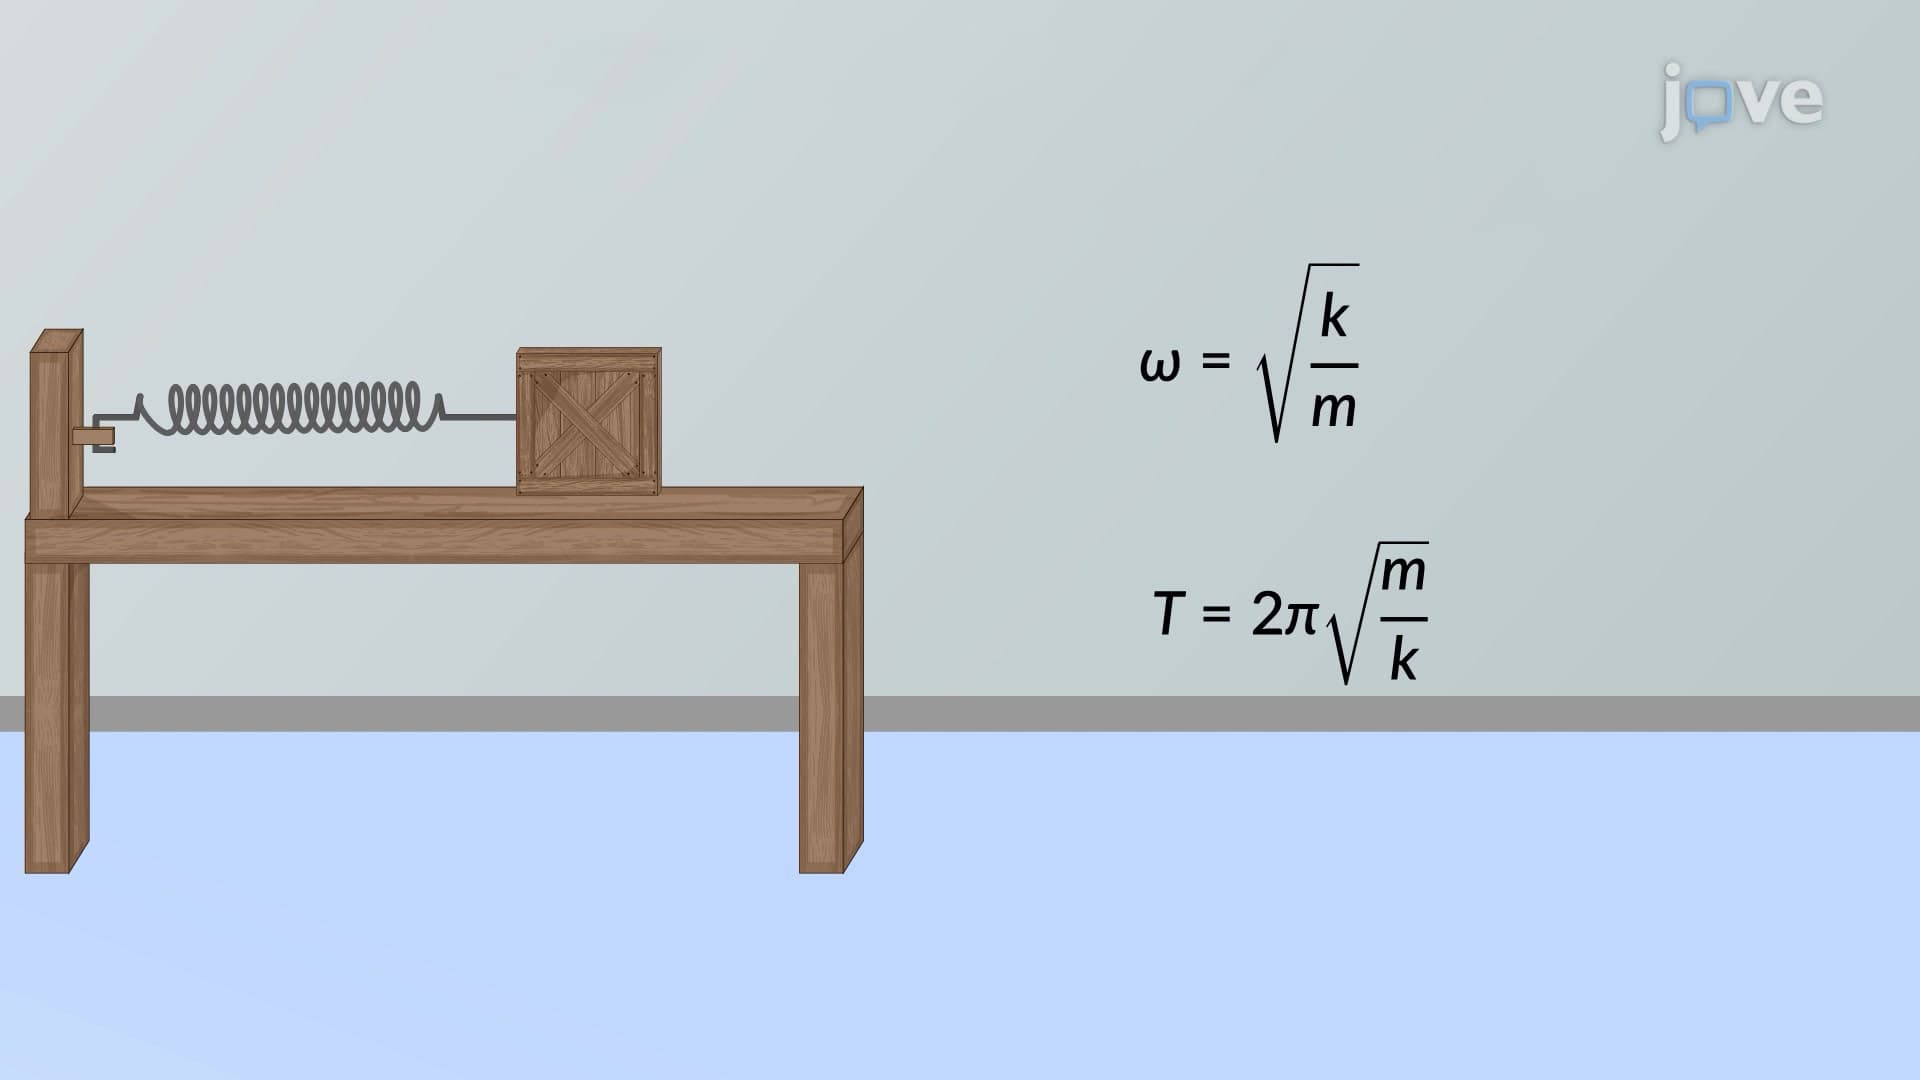
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...
 01:23
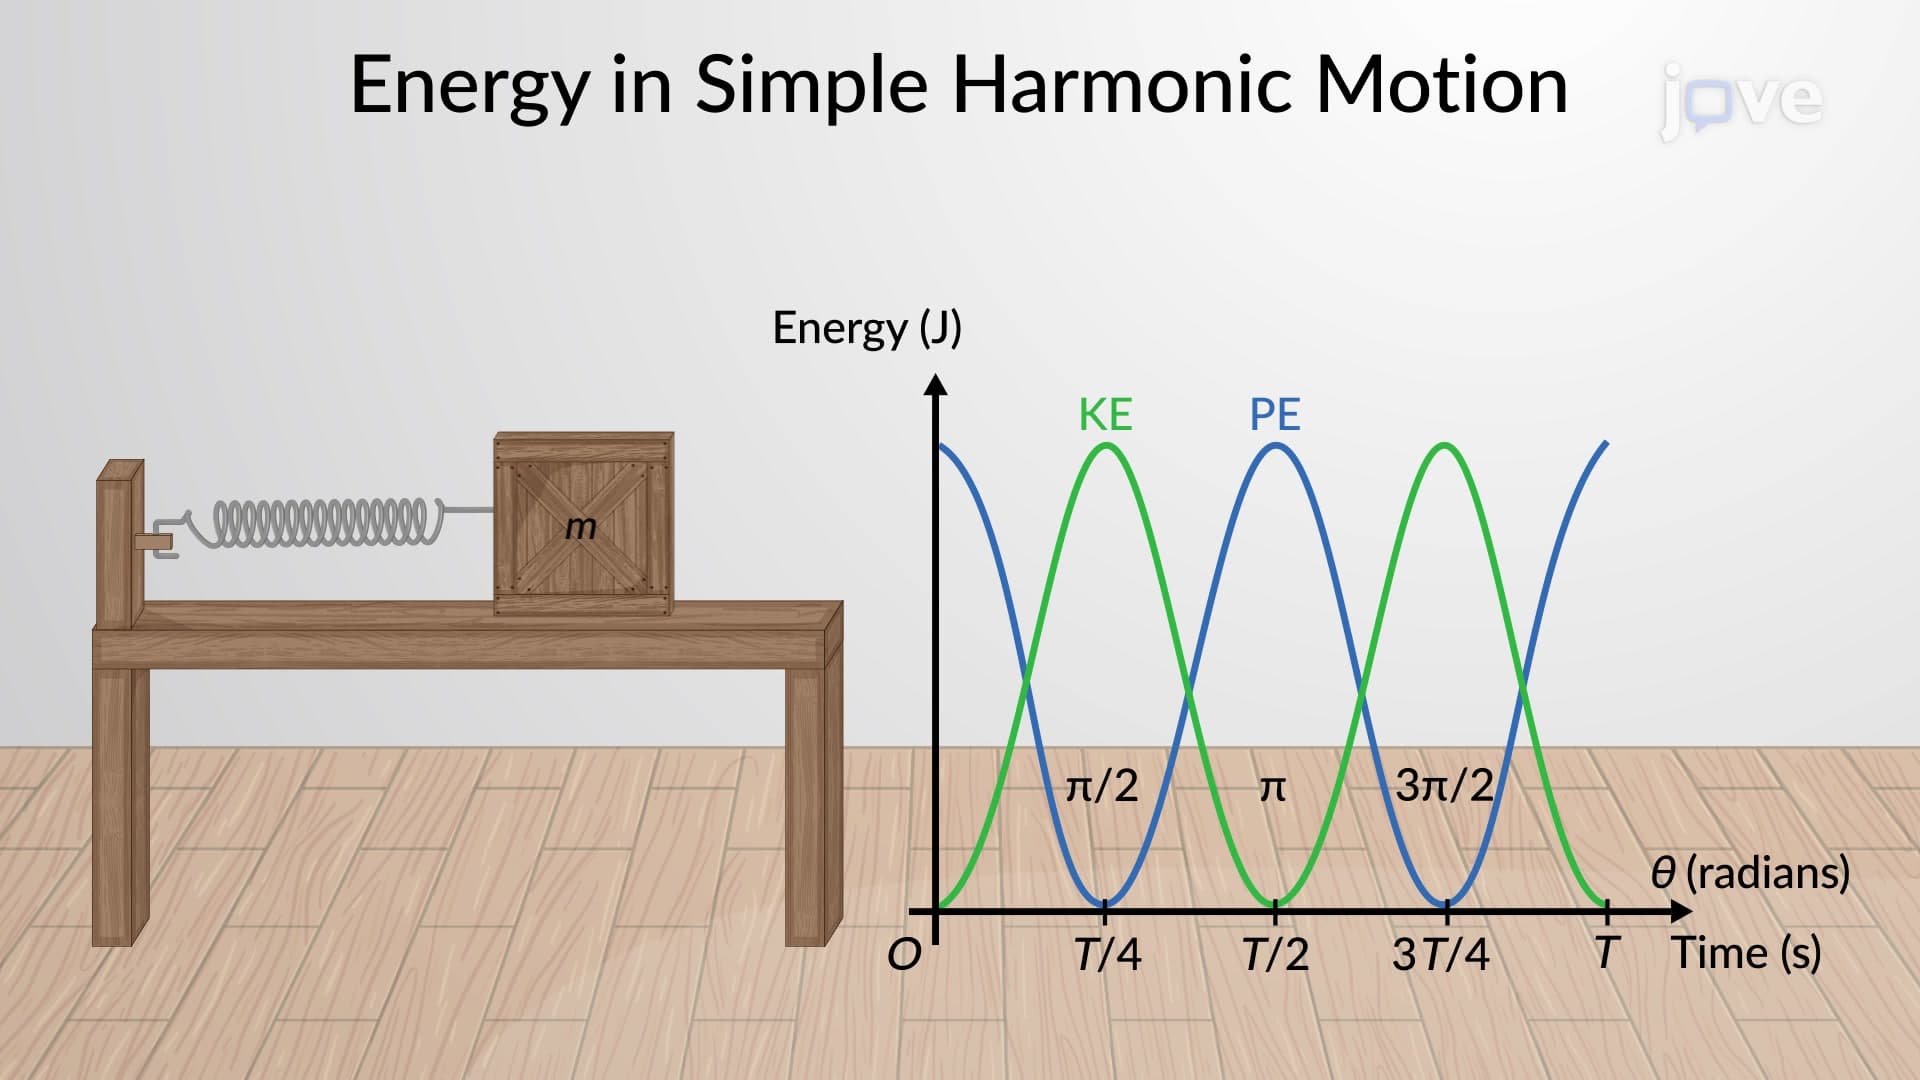
Energy in Simple Harmonic Motion
 01:10
Energy Diagrams - II
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The slope...