Backpropagation through time training of a neuro-fuzzy controller
Related Experiment Video
Updated: Jun 8, 2026
A Protocol for the Administration of Real-Time fMRI Neurofeedback Training
Published on: August 24, 2017
1Institute of Control and System Research, Bulgarian Academy of Sciences, Sofia, 1113, Bulgaria. pkoprinkova@icsr.bas.bg

Abstract:
The paper considers gradient training of fuzzy logic controller (FLC) presented in the form of neural network structure. The proposed neuro-fuzzy structure allows keeping linguistic meaning of fuzzy rule base. Its main adjustable parameters are shape determining parameters of the linguistic variables fuzzy values as well as that of the used as intersection operator parameterized T-norm. The backpropagation through time method was applied to train neuro-FLC for a highly non-linear plant (a biotechnological process). The obtained results are discussed with respect to adjustable parameters rationality. Conclusions are made with respect to the appropriate intersection operations too.


Related Concept Videos
 01:23
Propagation of Action Potentials
Neurons (nerve cells) have a resting membrane potential, with a slightly negative charge inside compared to outside. This is maintained by ion channels, such as sodium (Na+) and potassium (K+) channels, which control the flow of ions. When a stimulus, like a touch or a signal from another neuron, triggers the neuron, sodium channels open, allowing sodium ions to...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:21
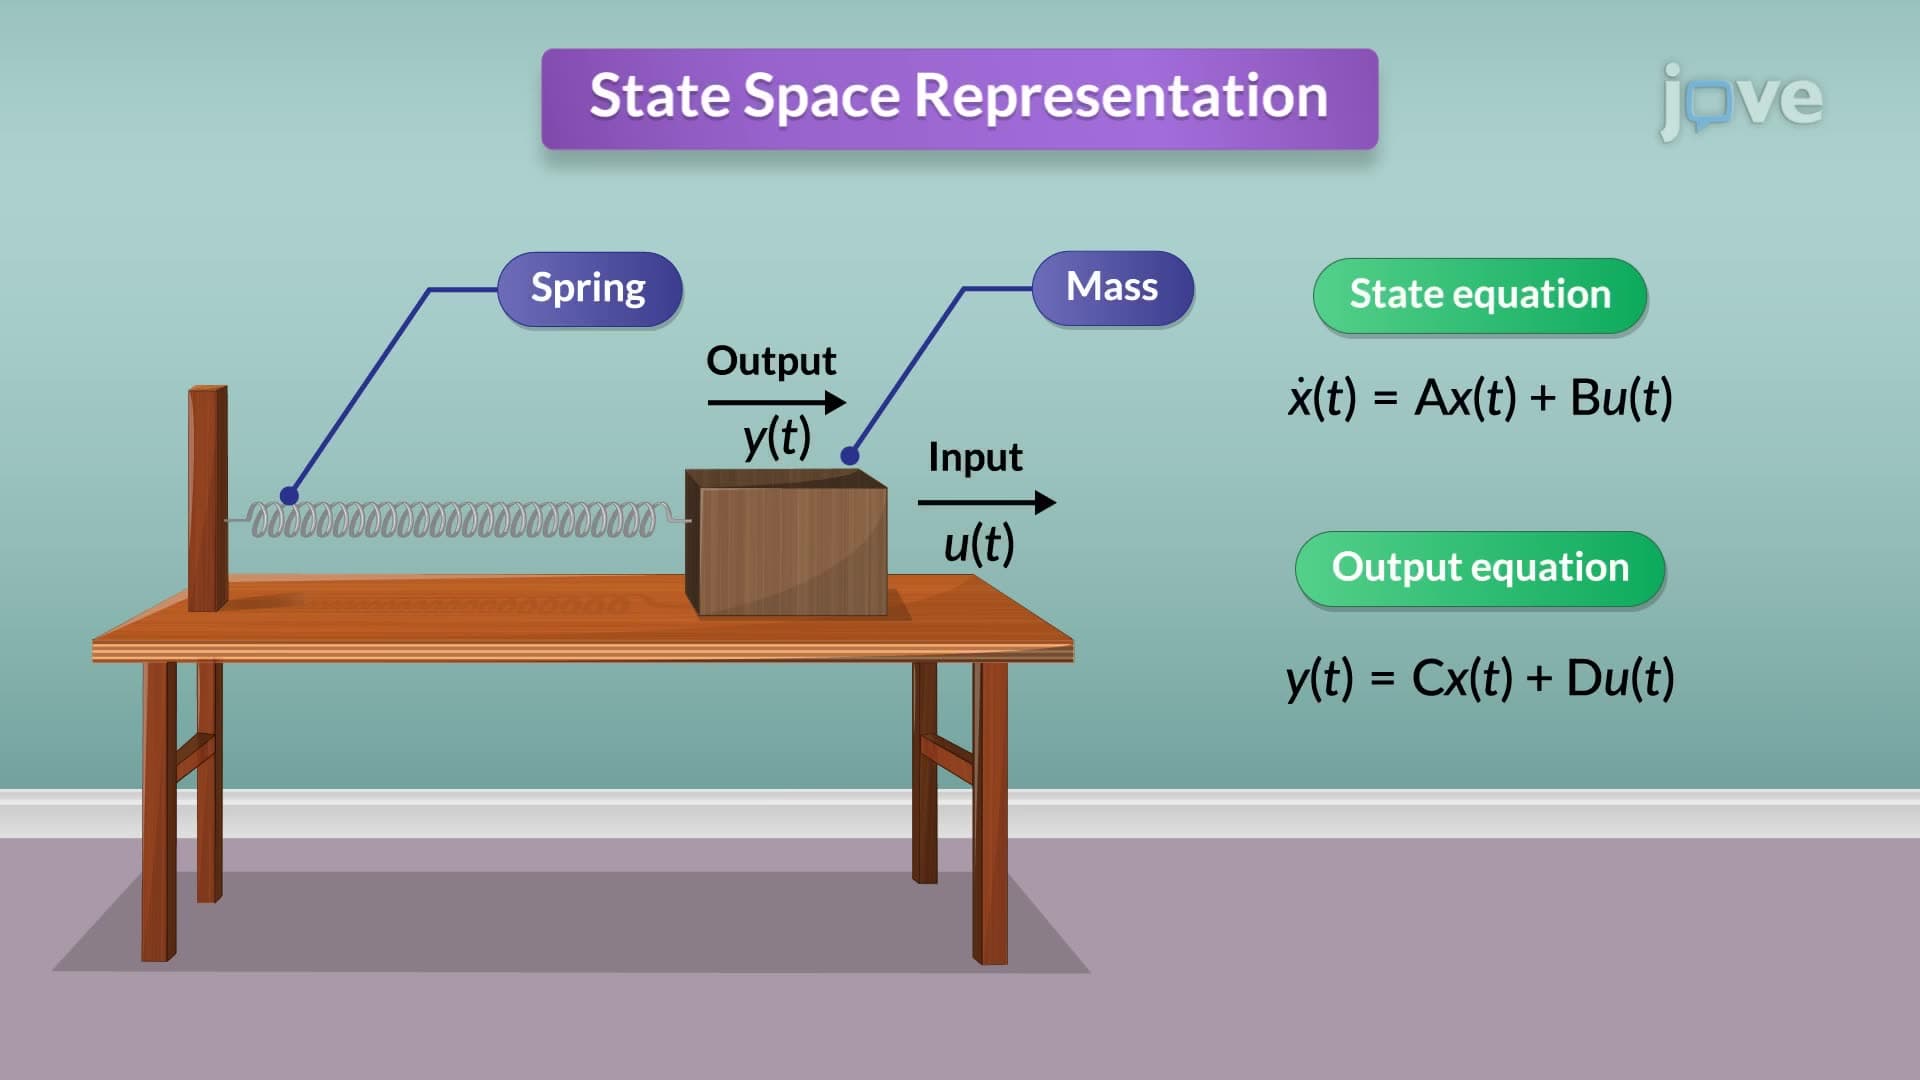
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...