Related Experiment Video
Updated: Jun 6, 2026
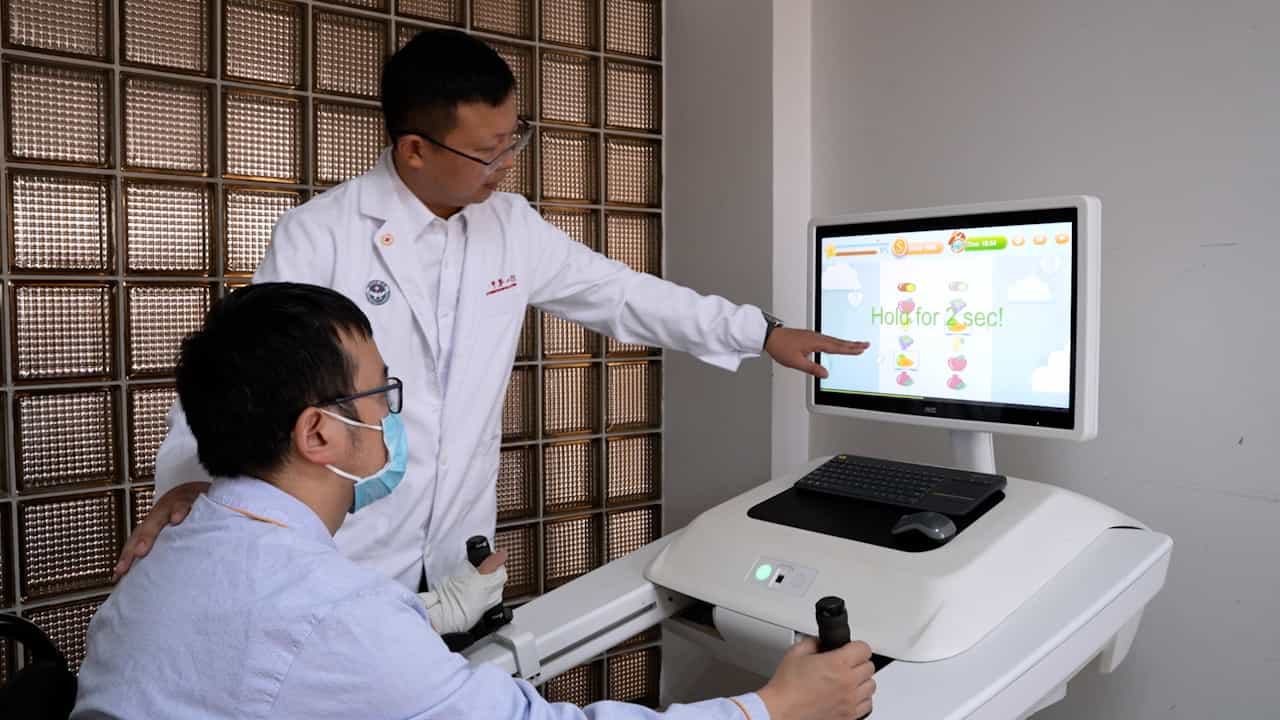
Enhancing Upper Limb Function and Motor Skills Post-Stroke Through an Upper Limb Rehabilitation Robot
Published on: September 6, 2024
Toward improved sensorimotor integration and learning using upper-limb prosthetic devices
R Brent Gillespie1, Jose Luis Contreras-Vidal, Patricia A Shewokis
1Department of Mechanical Engineering, University of Michigan, Ann Arbor, MI 48109, USA. brentg@umich.edu

Abstract:
To harness the increased dexterity and sensing capabilities in advanced prosthetic device designs, amputees will require interfaces supported by novel forms of sensory feedback and novel control paradigms. We are using a motorized elbow brace to feed back grasp forces to the user in the form of extension torques about the elbow. This force display complements myoelectric control of grip closure in which EMG signals are drawn from the biceps muscle. We expect that the action/reaction coupling experienced by the biceps muscle will produce an intuitive paradigm for object manipulation, and we hope to uncover neural correlates to support this hypothesis. In this paper we present results from an experiment in which 7 able-bodied persons attempted to distinguish three objects by stiffness while grasping them under myoelectric control and feeling reaction forces displayed to their elbow. In four conditions (with and without force display, and using biceps myoelectric signals ipsilateral and contralateral to the force display,) ability to correctly identify objects was significantly increased with sensory feedback.