Related Experiment Video
Updated: Jun 6, 2026

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Characterizing skin using a three-axis parallel drive force-sensitive micro-robot
Cormac Flynn1, Andrew J Taberner, Poul M F Nielsen
1Auckland Bioengineering Institute, The University of Auckland, New Zealand. c.flynn@auckland.ac.nz

Abstract:
There is a strong need to measure the complex mechanical properties of soft tissues such as skin. An in vivo experiment characterizing the mechanical response of human skin is presented. A rich set of deformations were applied to several positions on the arm using a novel force-sensitive micro-robot. All sites studied exhibit highly non-linear, anisotropic, and viscoelastic behavior. The experiments determined directions in which the skin response was stiffest. These directions agree with accepted orientations of Langer or relaxed skin tension lines.
Related Concept Videos
 01:30
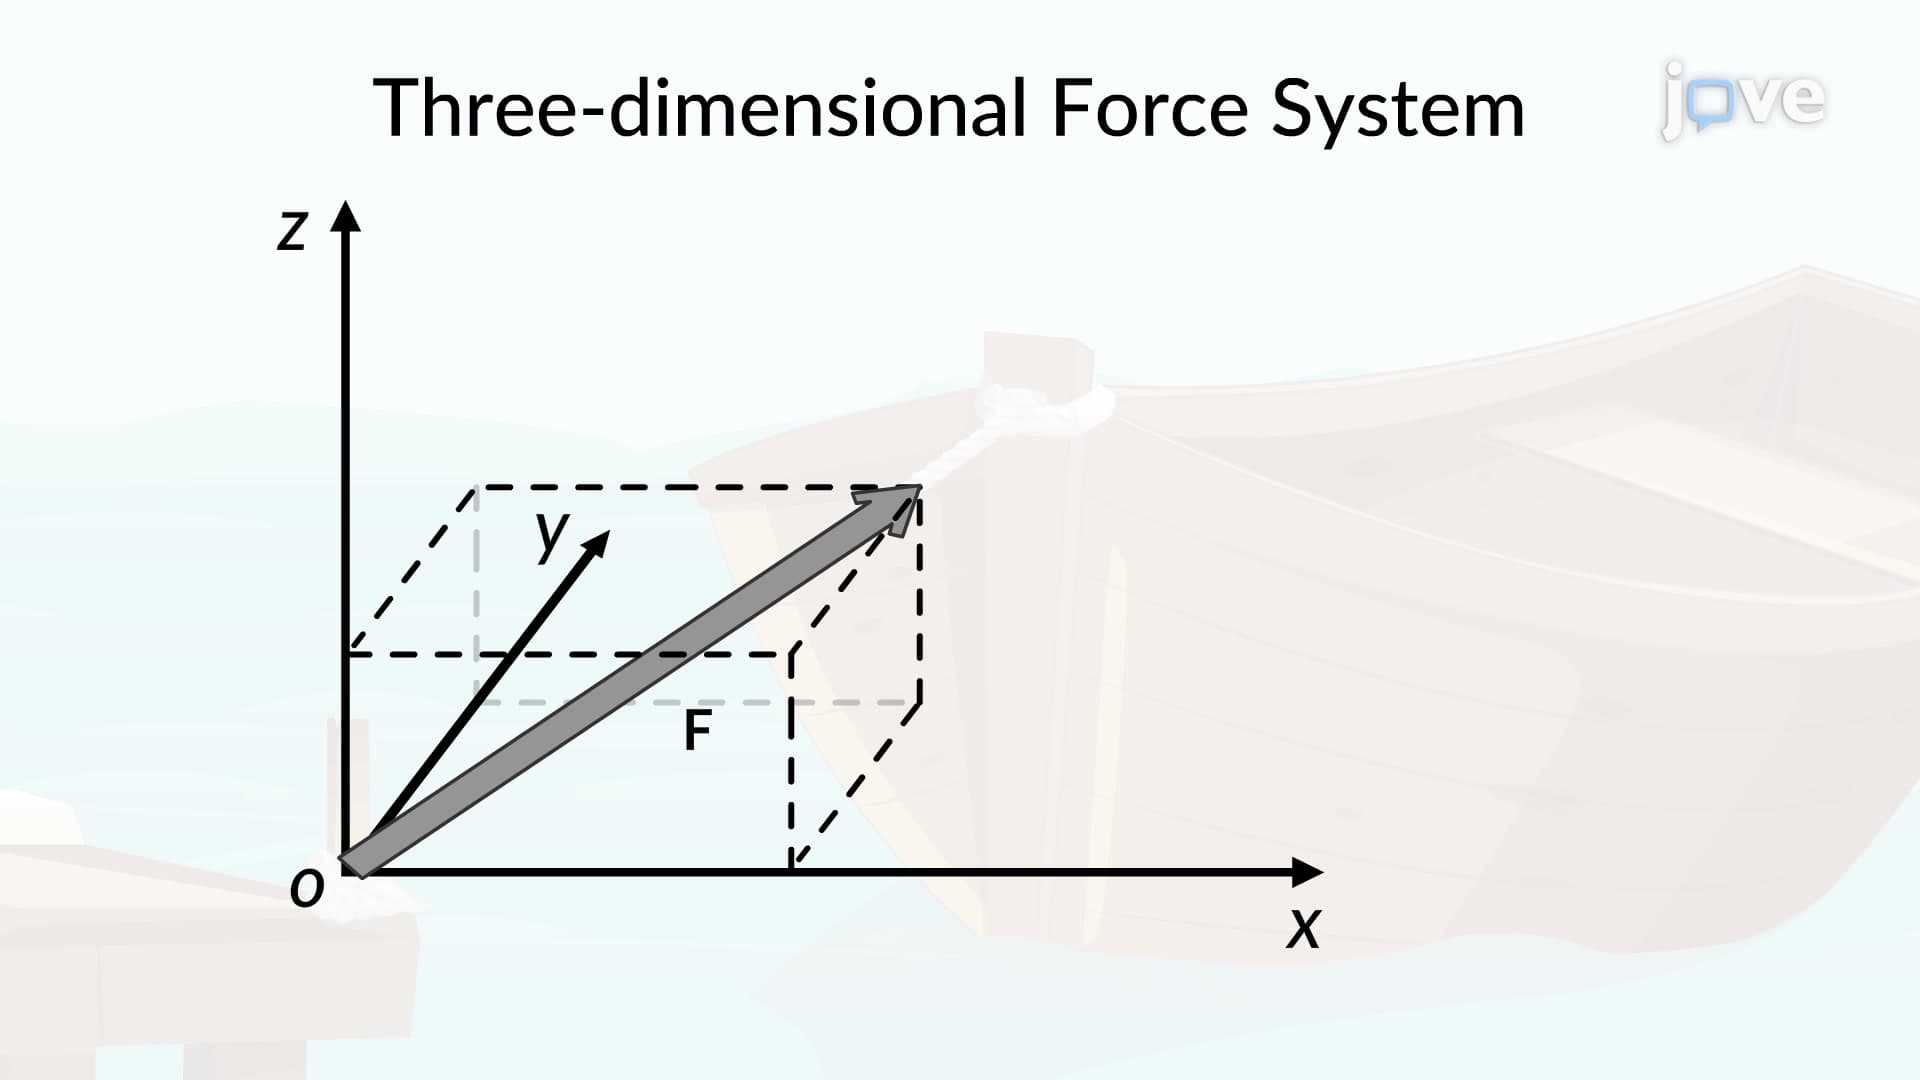
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...