Related Experiment Video
Updated: Jun 6, 2026
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy (iPALM)
Published on: December 1, 2016
Linear Scale and Rotation Invariant Matching

Abstract:
Matching visual patterns that appear scaled, rotated, and deformed with respect to each other is a challenging problem. We propose a linear formulation that simultaneously matches feature points and estimates global geometrical transformation in a constrained linear space. The linear scheme enables search space reduction based on the lower convex hull property so that the problem size is largely decoupled from the original hard combinatorial problem. Our method therefore can be used to solve large scale problems that involve a very large number of candidate feature points. Without using prepruning in the search, this method is more robust in dealing with weak features and clutter. We apply the proposed method to action detection and image matching. Our results on a variety of images and videos demonstrate that our method is accurate, efficient, and robust.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:16
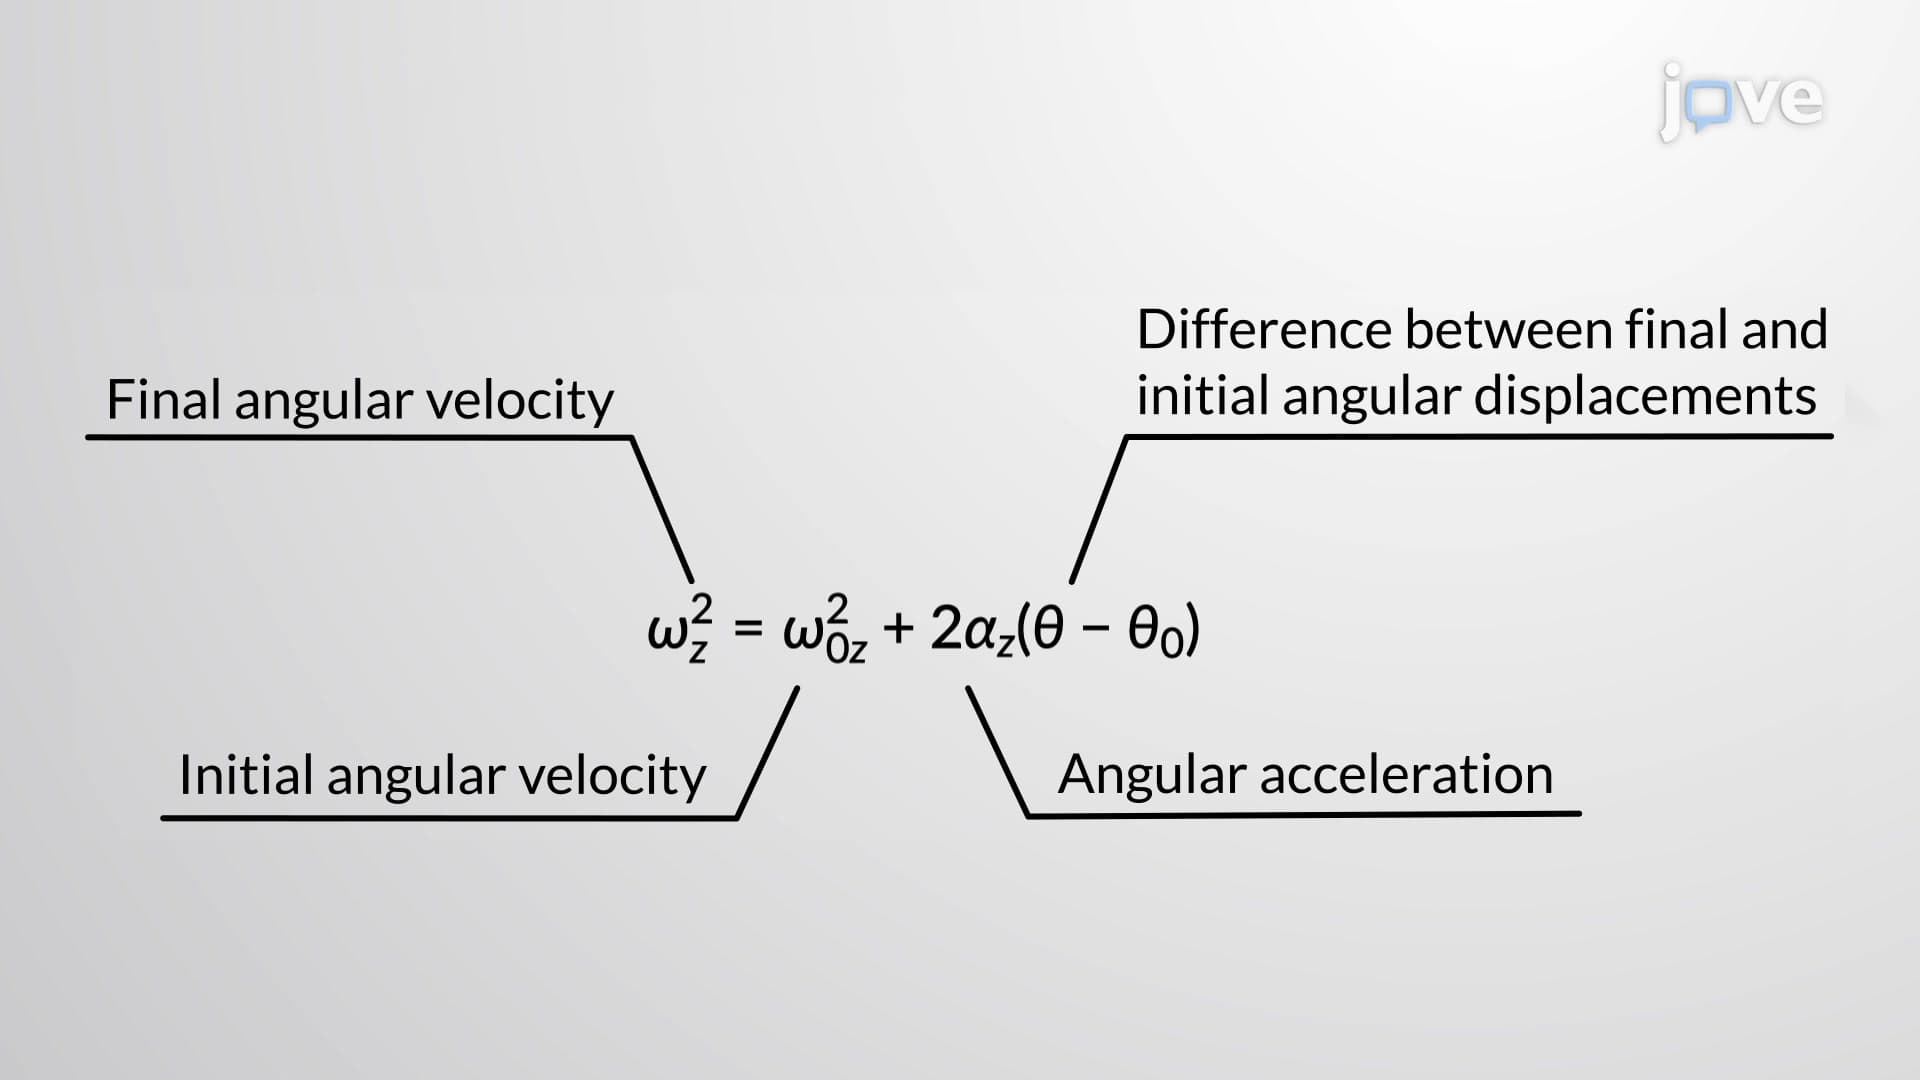
Rotation with Constant Angular Acceleration - II
The first...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:16
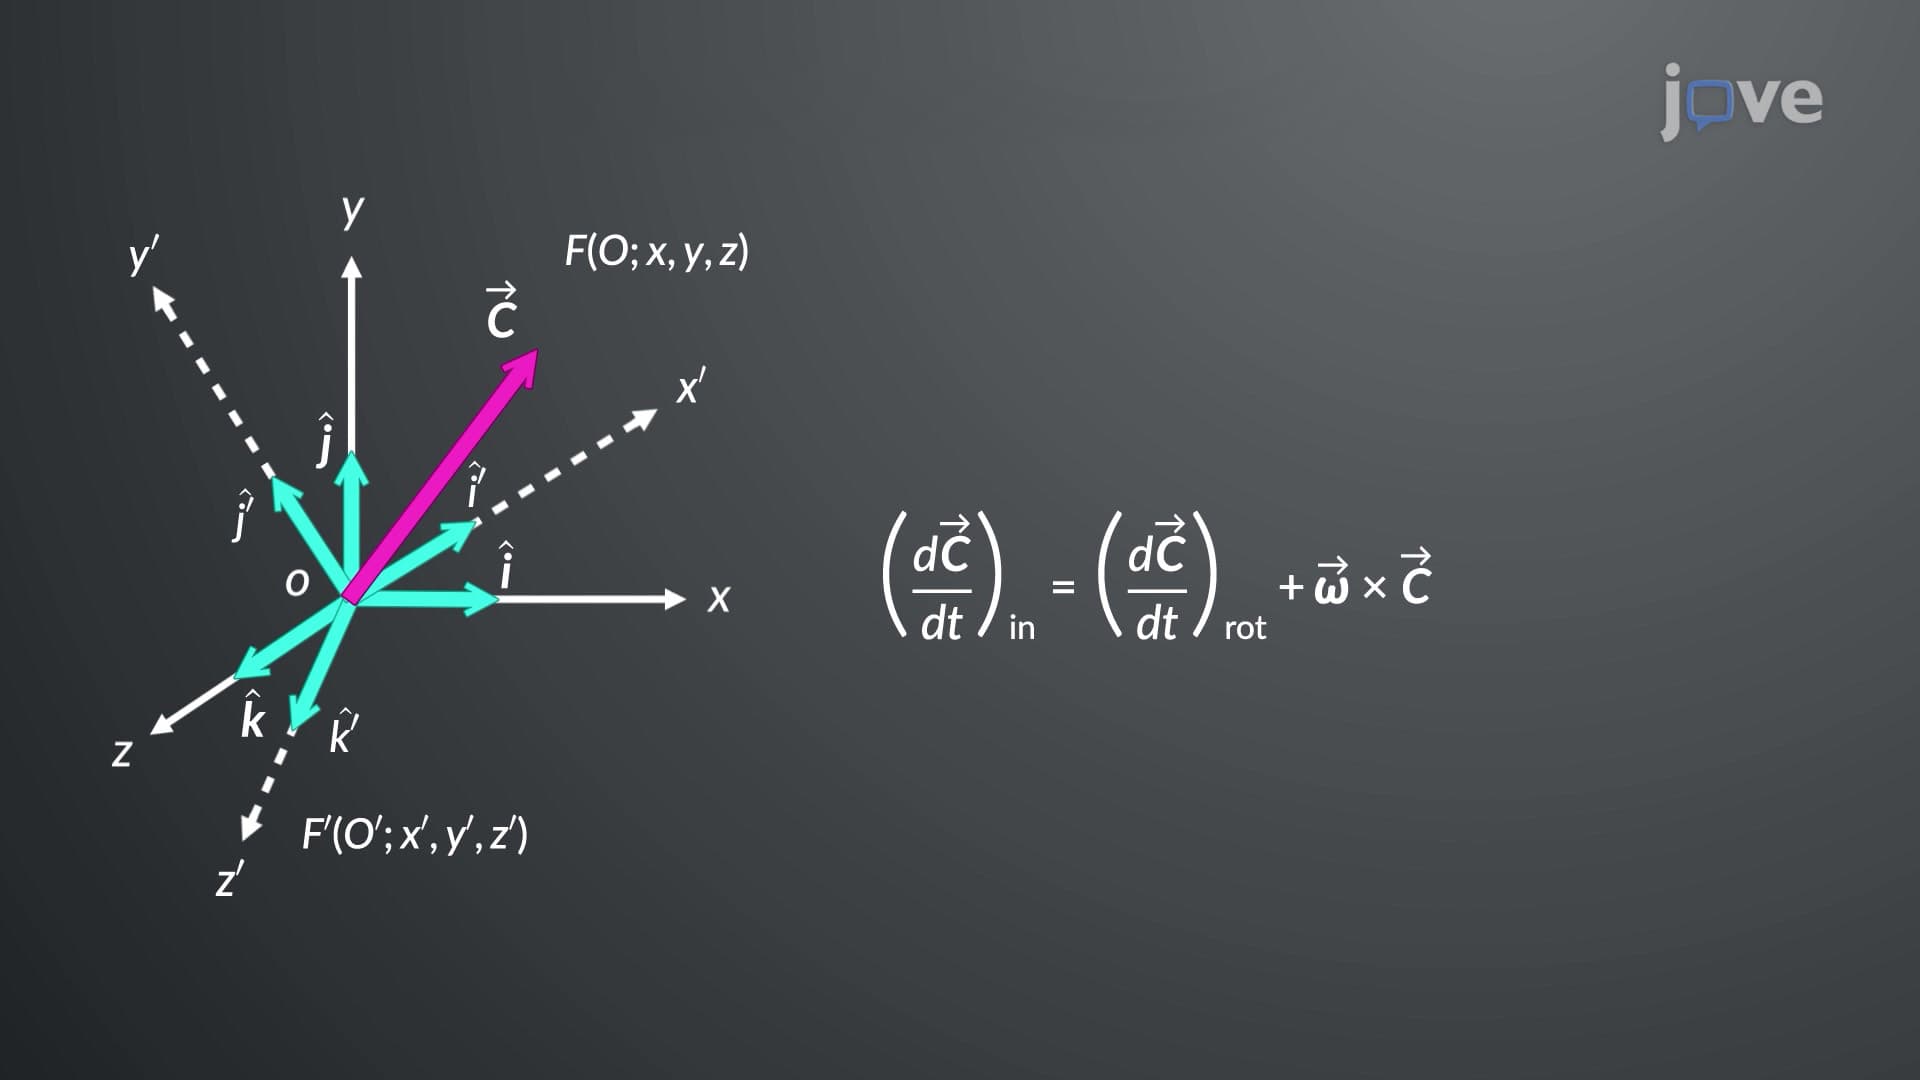
Vector Transformation in Rotating Coordinate Systems