Bouncing between model and data: stability, passivity, and optimality in hybrid dynamics
Related Experiment Video
Updated: Jun 5, 2026
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Renaud Ronsse1, Dagmar Sternad
1Biorobotics Laboratory, Institute of Bioengineering, École Polytechnique Fédérale de Lausanne, Switzerland.

Abstract:
Rhythmically bouncing a ball with a racket is a seemingly simple task, but it poses all the challenges critical for coordinative behavior: perceiving the ball's trajectory to adapt position and velocity of the racket for the next ball contact. To gain insight into the underlying control strategies, the authors conducted a series of studies that tested models with experimental data, with an emphasis on deriving model-based hypotheses and trying to falsify them. Starting with a simple dynamical model of the racket and ball interactions, stability analyses showed that open-loop dynamics affords dynamical stability, such that small perturbations do not require corrections. To obtain this passive stability, the ball has to be impacted with negative acceleration--a strategy that subjects adopted in a variety of conditions at steady state. However, experimental tests that applied perturbations revealed that after perturbations, subjects applied active perceptually guided corrections to reestablish steady state faster than by relying on the passive model's relaxation alone. Hence, the authors derived a model with active control based on optimality principles that considered each impact as a separate reaching-like movement. This model captured some additional features of the racket trajectory but failed to predict more fine-grained aspects of performance. The authors proceed to present a new model that accounts not only for fine-grained behavior but also reconciles passive and active control approaches with new predictions that will be put to test in the next set of experiments.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:04
Oscillations about an Equilibrium Position
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:20
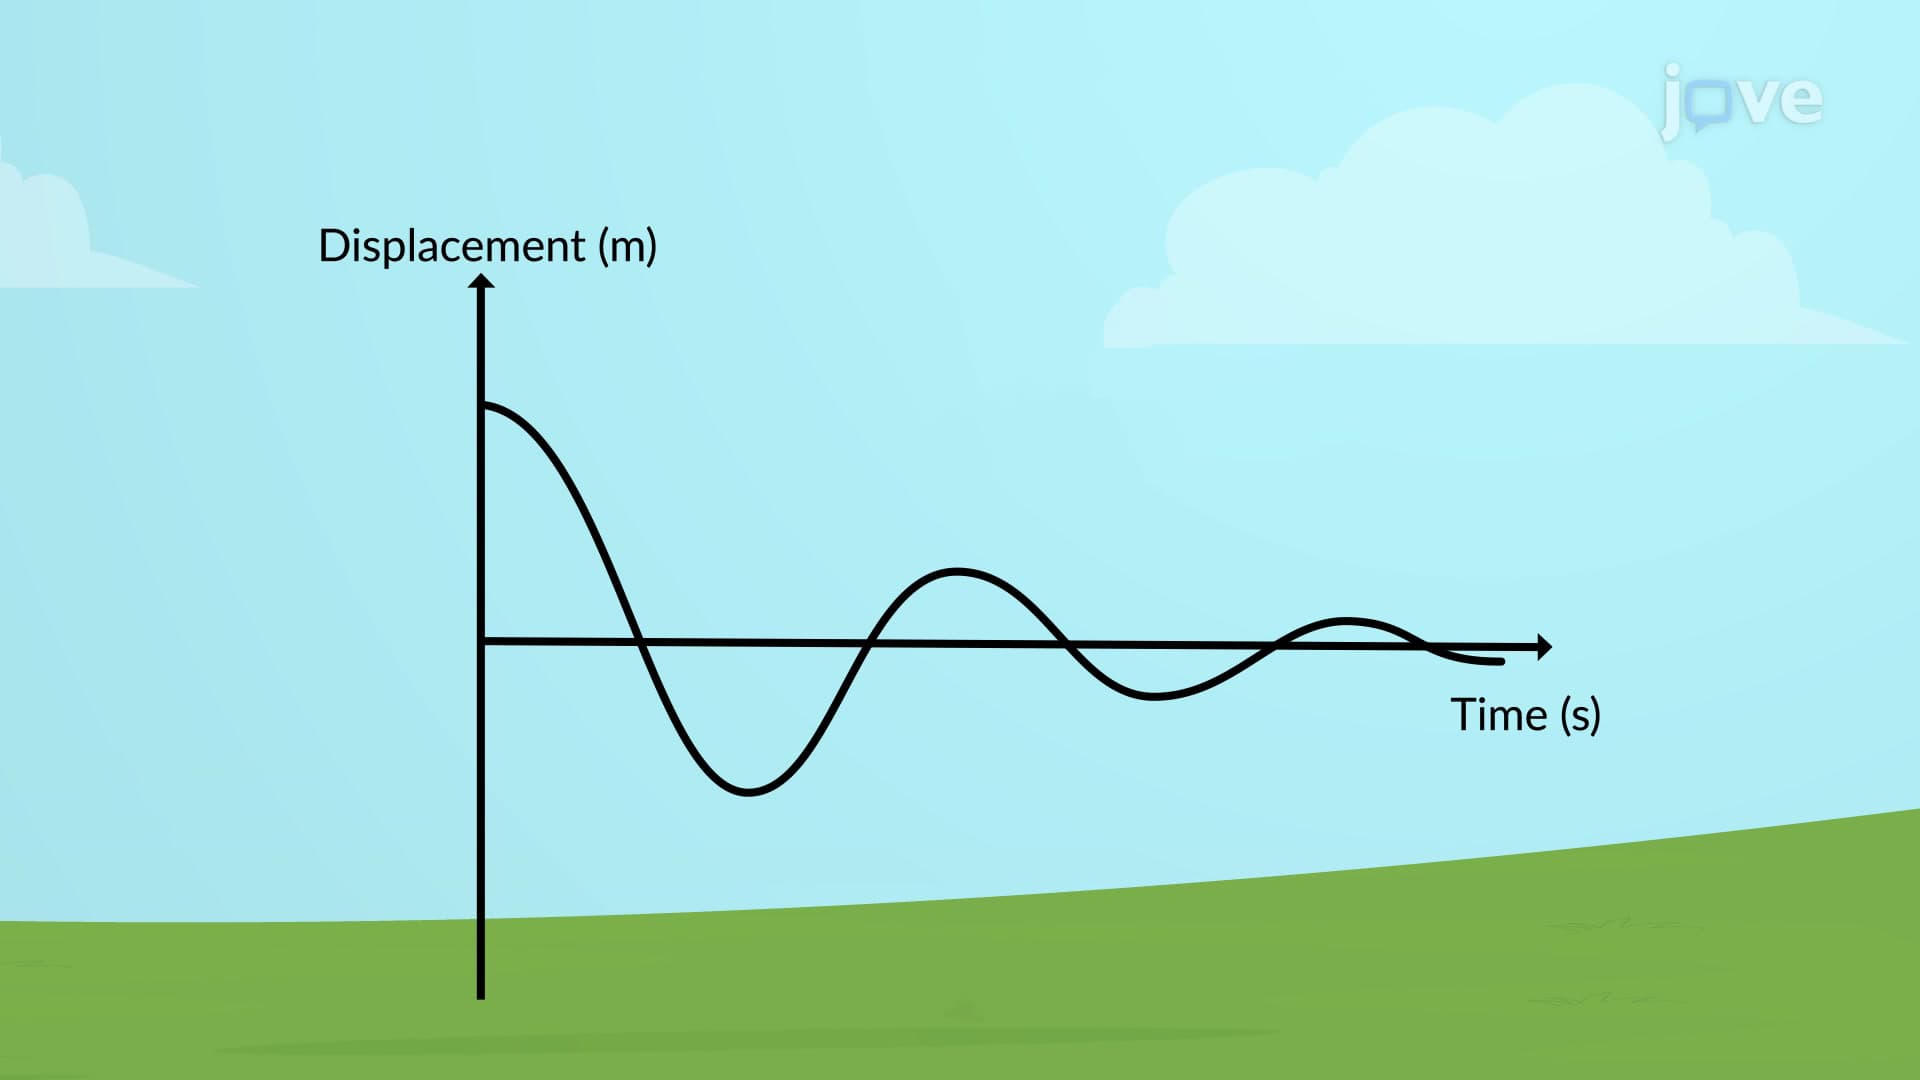
Types of Damping
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 02:20
Dynamic Equilibrium