Related Experiment Video
Updated: Jun 5, 2026
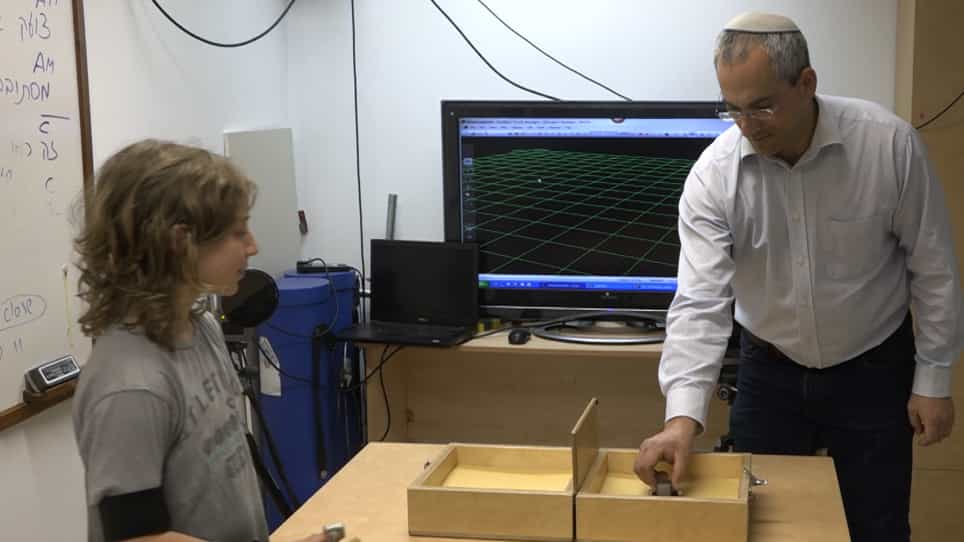

Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Integration of disparity and velocity information for haptic and perceptual judgments of object depth
Rachel Foster1, Carlo Fantoni, Corrado Caudek
1Department of Cognitive and Linguistic Sciences, Brown University, Providence, RI, USA. rachel.mary.foster@gmail.com

Abstract:
Do reach-to-grasp (prehension) movements require a metric representation of three-dimensional (3D) layouts and objects? We propose a model relying only on direct sensory information to account for the planning and execution of prehension movements in the absence of haptic feedback and when the hand is not visible. In the present investigation, we isolate relative motion and binocular disparity information from other depth cues and we study their efficacy for reach-to-grasp movements and visual judgments. We show that (i) the amplitude of the grasp increases when relative motion is added to binocular disparity information, even if depth from disparity information is already veridical, and (ii) similar distortions of derived depth are found for haptic tasks and perceptual judgments. With a quantitative test, we demonstrate that our results are consistent with the Intrinsic Constraint model and do not require 3D metric inferences (Domini, Caudek, & Tassinari, 2006). By contrast, the linear cue integration model (Landy, Maloney, Johnston, & Young, 1995) cannot explain the present results, even if the flatness cues are taken into account.
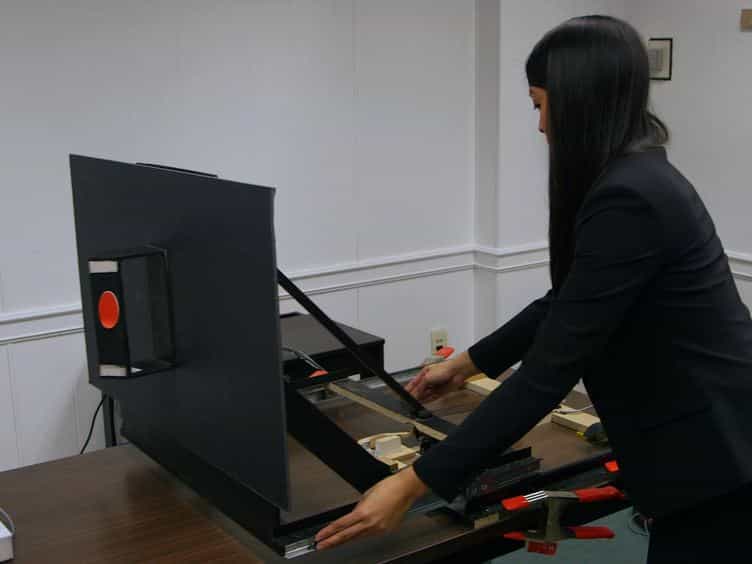
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:12
Perceptual Constancy
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
 01:11
Relative Velocity in Two Dimensions
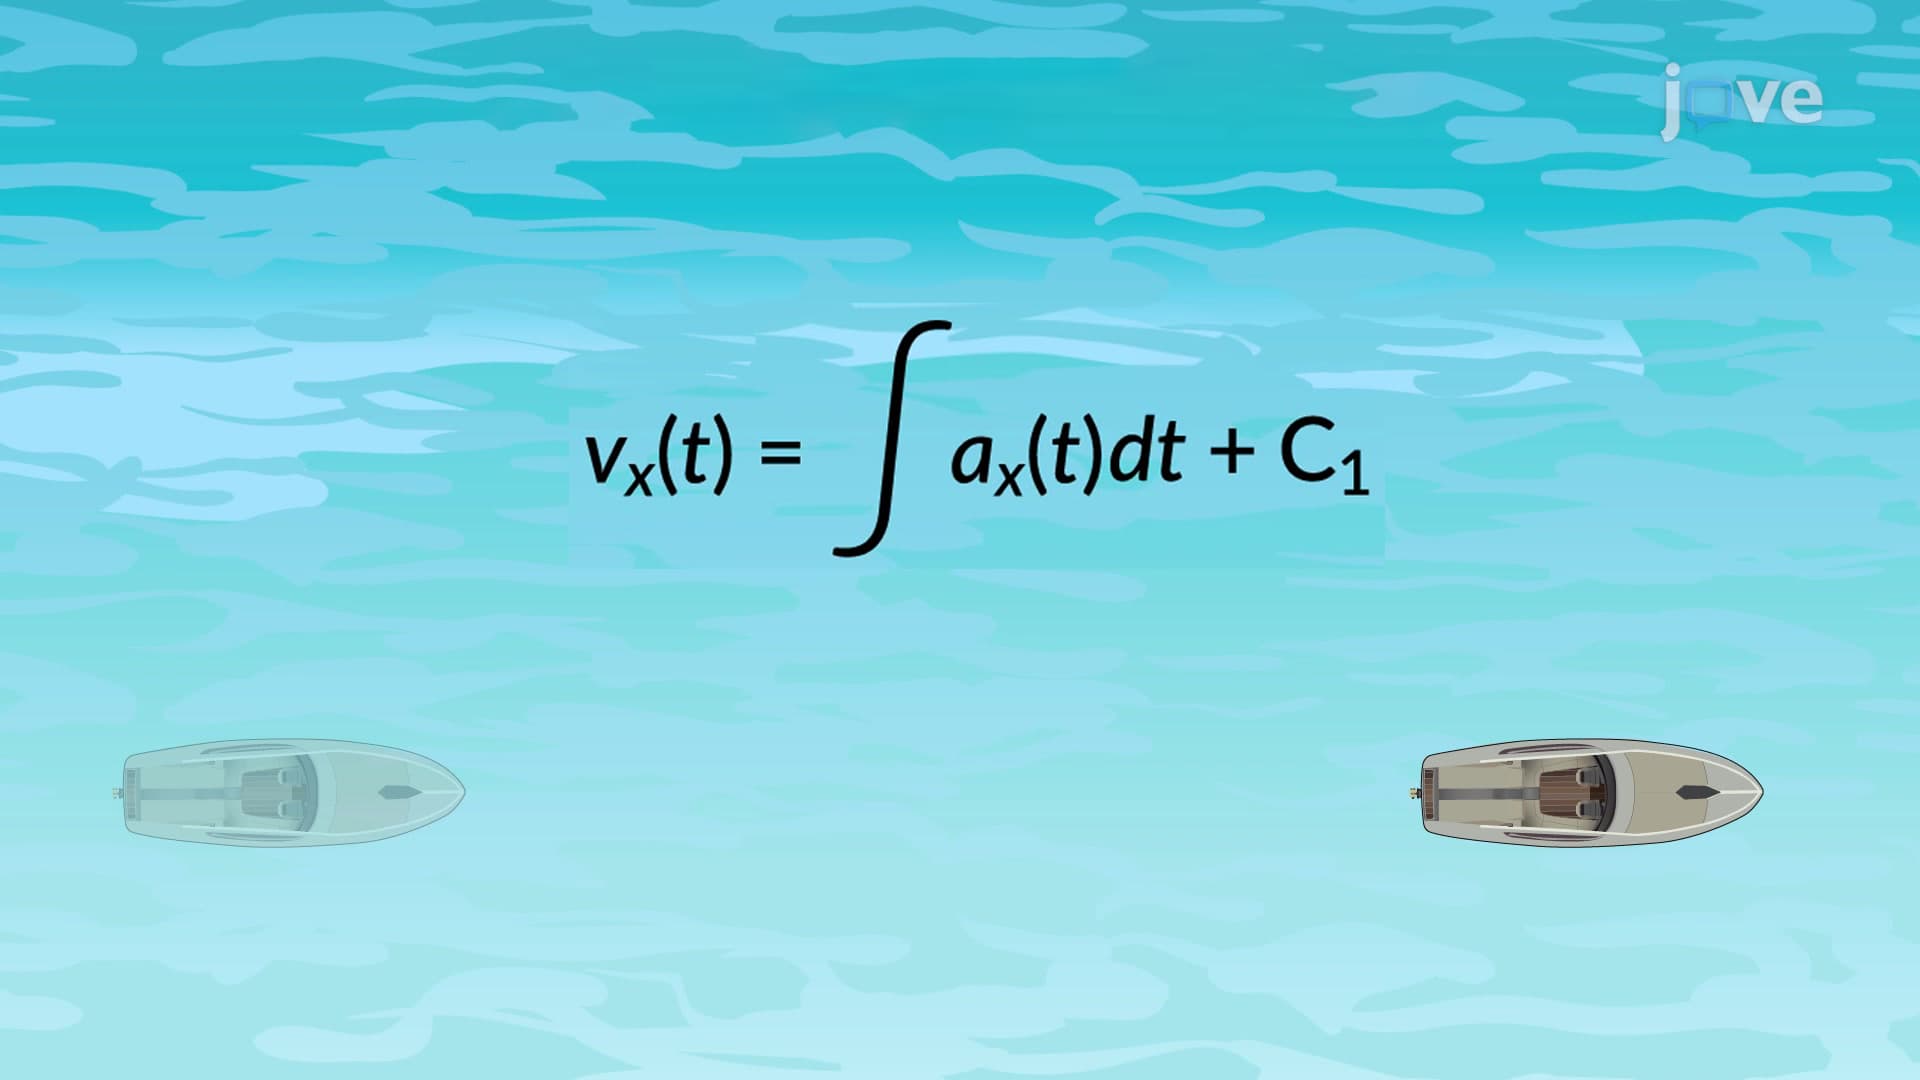 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Velocity in One Dimension