Related Experiment Video
Updated: Jun 4, 2026

Generating Strictly Controlled Stimuli for Figure Recognition Experiments
Published on: March 18, 2019
Force, Torque and Stiffness: Interactions in Perceptual Discrimination
Bing Wu1, Roberta L Klatzky, Ralph L Hollis
1Department of Psychology, Carnegie Mellon University, Pittsburgh PA 15213. bingwu@andrew.cmu.edu .

Abstract:
Three experiments investigated whether force and torque cues interact in haptic discrimination of force, torque and stiffness, and if so, how. The statistical relation between force and torque was manipulated across four experimental conditions: Either one type of cue varied while the other was constant, or both varied so as to be positively correlated, negatively correlated, or uncorrelated. Experiment 1 showed that the subjects' ability to discriminate force was improved by positively correlated torque but impaired with uncorrelated torque, as compared to the constant torque condition. Corresponding effects were found in Experiment 2 for the influence of force on torque discrimination. These findings indicate that force and torque are integrated in perception, rather than being processed as separate dimensions. A further experiment demonstrated facilitation of stiffness discrimination by correlated force and torque, whether the correlation was positive or negative. The findings suggest new means of augmenting haptic feedback to facilitate perception of the properties of soft objects.

Related Concept Videos
 01:25
Factors Affecting Perception
An illustrative example of a perceptual set is the scenario where an airline pilot told...
 01:10
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:15
Relation between Poisson's ratio, Modulus of Elasticity and Modulus of Rigidity
 01:12
Perceptual Constancy
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
 01:22
Mechanical Systems
 01:23
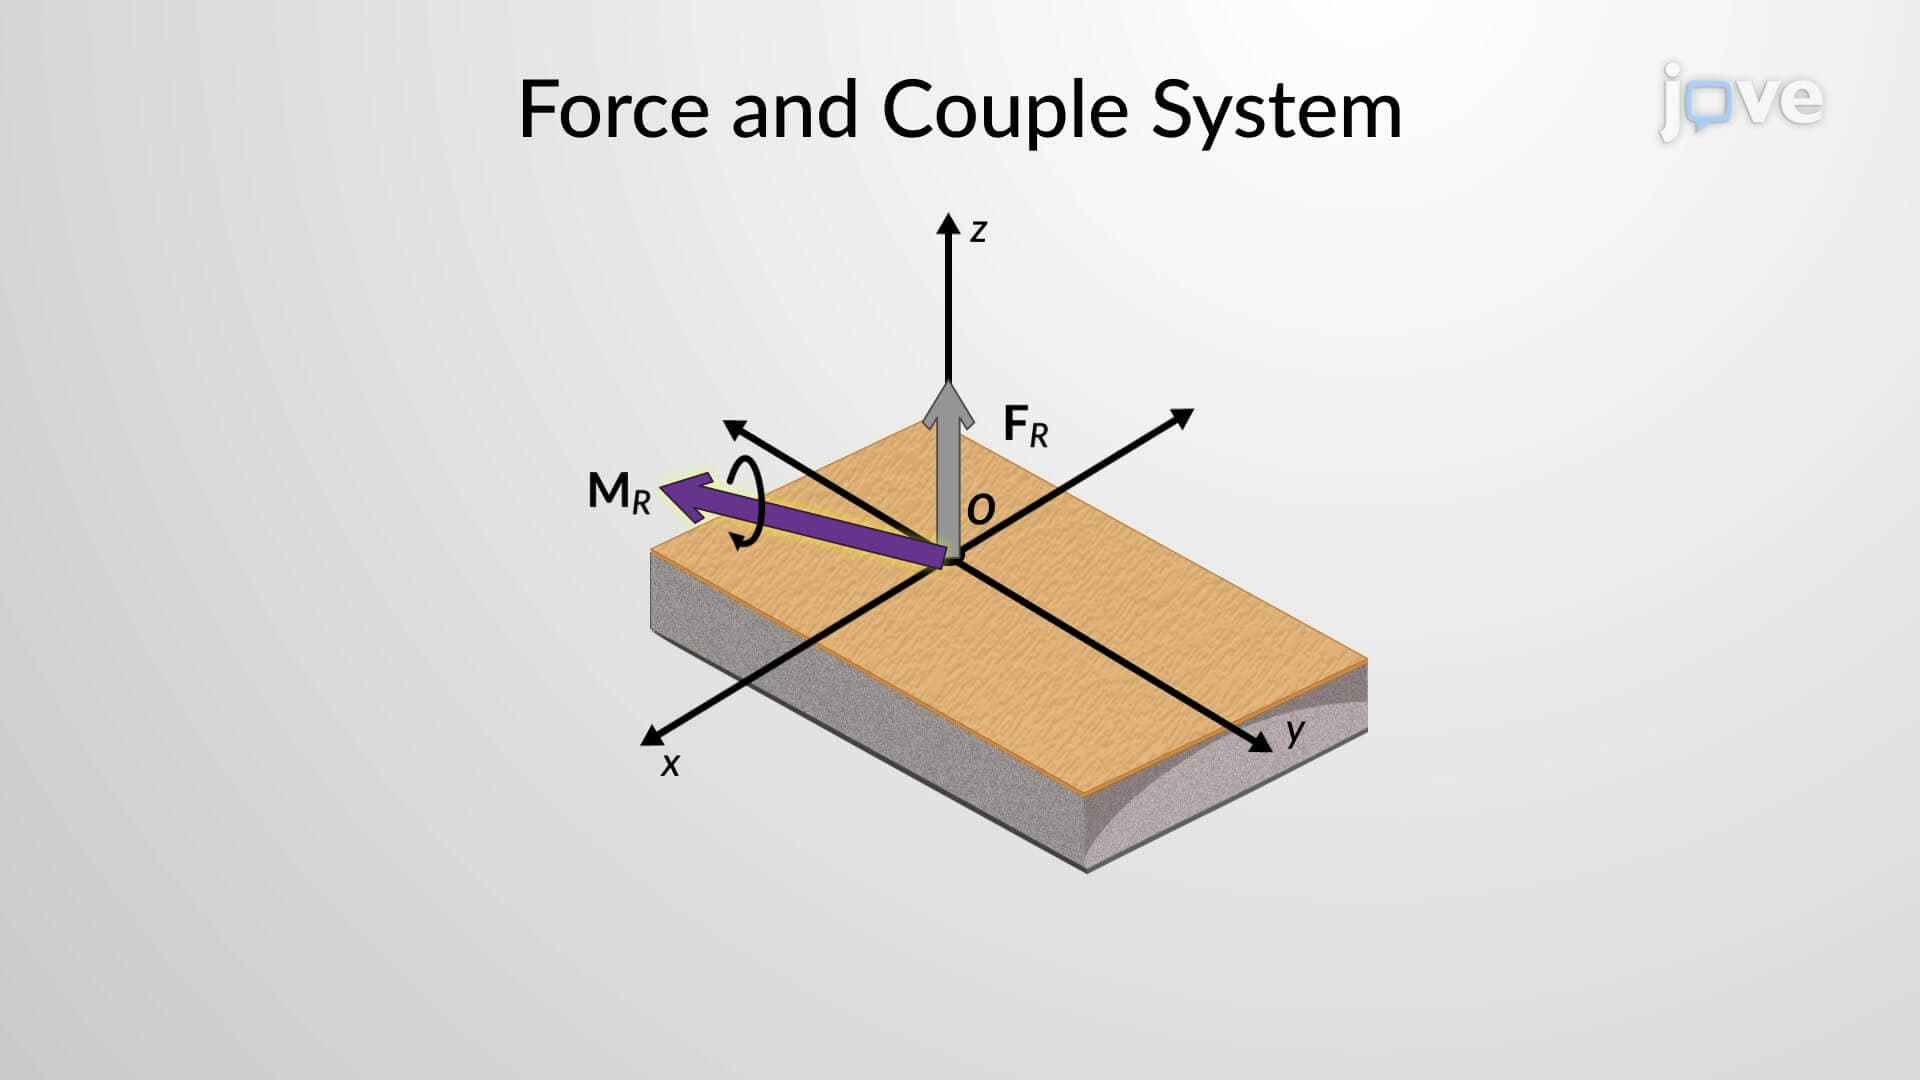
Simplification of a Force and Couple System: II