Related Experiment Video
Updated: Jun 2, 2026

Estimate the Cognitive Load Using Electrocardiographic Measure: A Human-AI Collaborative Task
Published on: December 5, 2025
Use of the RoboFlag synthetic task environment to investigate workload and stress responses in UAV operation
Svyatoslav Guznov1, Gerald Matthews, Gregory Funke
1Department of Psychology, University of Cincinnati, 5140H Edwards Hall 1, Cincinnati, OH 45221, USA. guznovs@mail.uc.edu

Abstract:
Use of unmanned aerial vehicles (UAVs) is an increasingly important element of military missions. However, controlling UAVs may impose high stress and workload on the operator. This study evaluated the use of the RoboFlag simulated environment as a means for profiling multiple dimensions of stress and workload response to a task requiring control of multiple vehicles (robots). It tested the effects of two workload manipulations, environmental uncertainty (i.e., UAV's visual view area) and maneuverability, in 64 participants. The findings confirmed that the task produced substantial workload and elevated distress. Dissociations between the stress and performance effects of the manipulations confirmed the utility of a multivariate approach to assessment. Contrary to expectations, distress and some aspects of workload were highest in the low-uncertainty condition, suggesting that overload of information may be an issue for UAV interface designers. The strengths and limitations of RoboFlag as a methodology for investigating stress and workload responses are discussed.
Related Concept Videos
 01:15
Stress: General Loading Conditions
The shearing force, possessing potential directionality within the plane of the section, is simplified into two component forces running parallel to the x and y axes.
 01:13
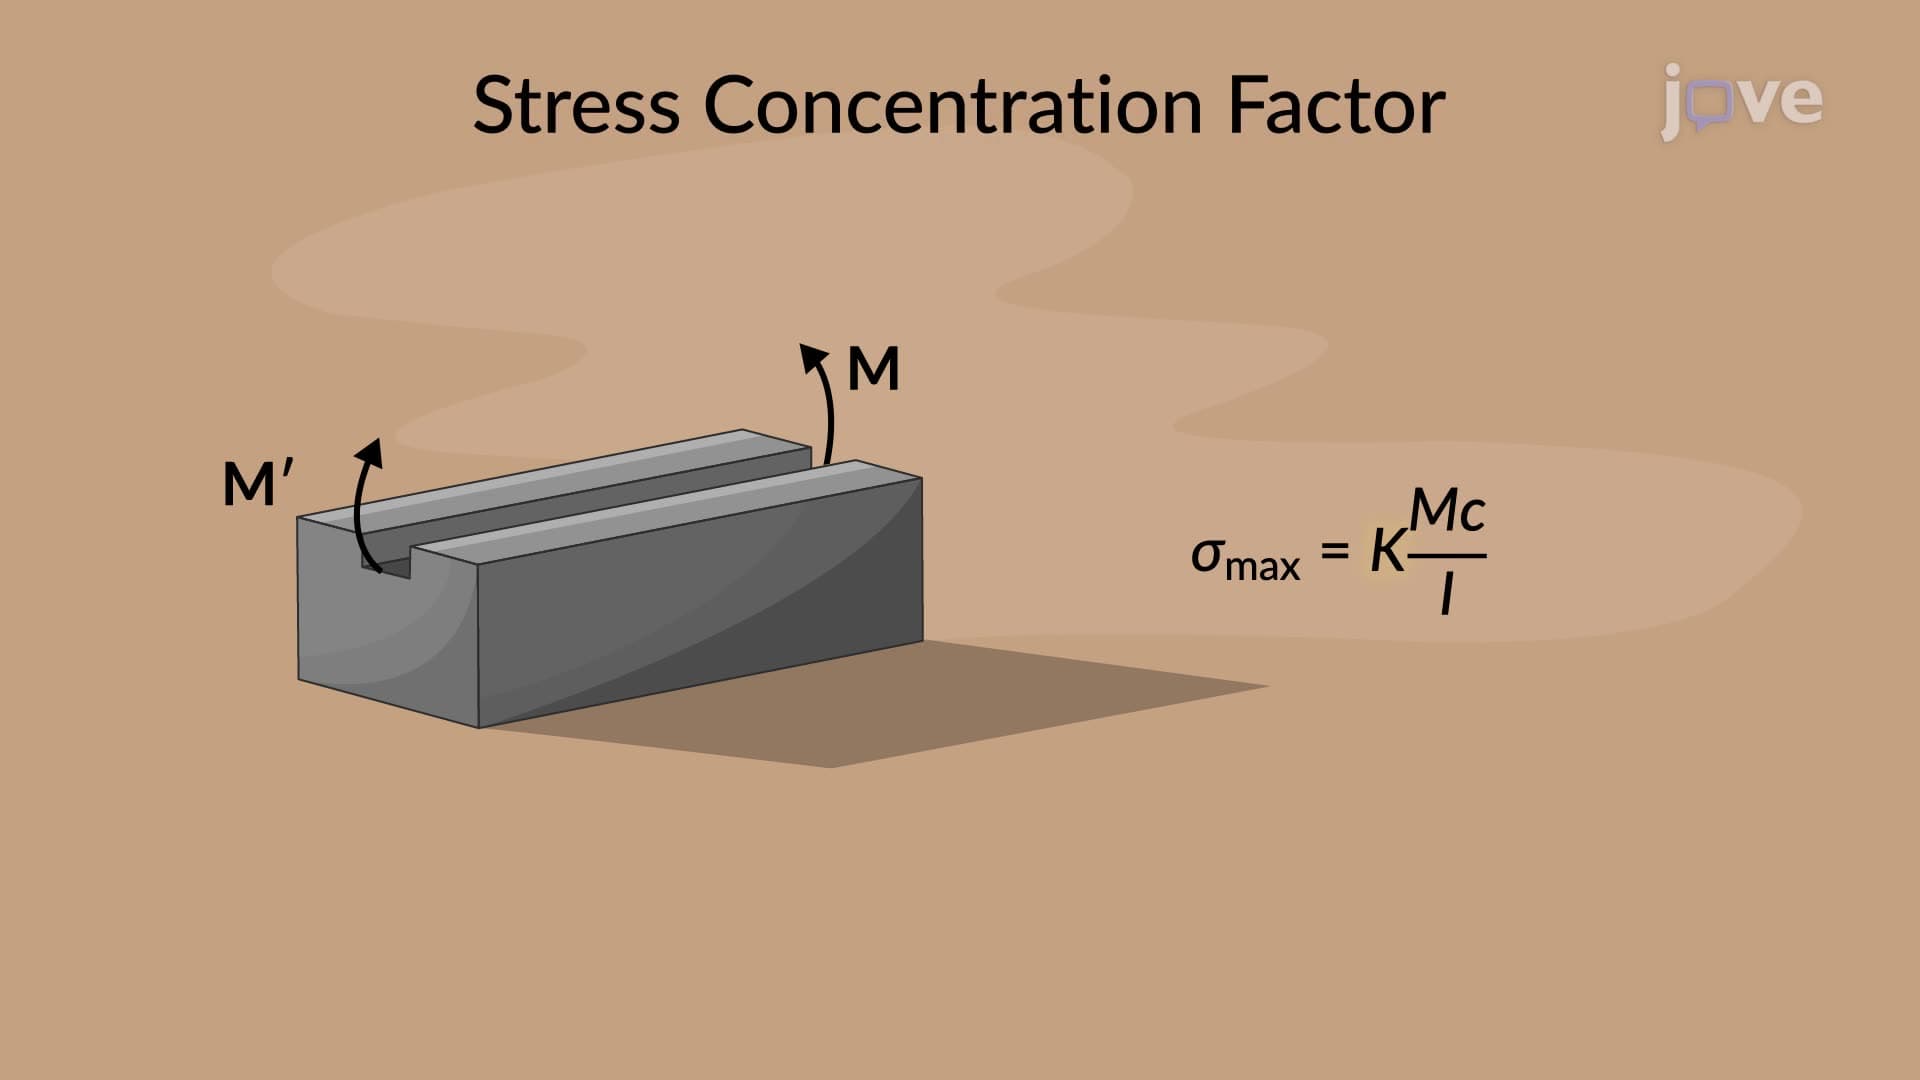
Stress Concentrations
The stress concentration...
 01:24
Stress Concentrations
 01:04
Applications of Stress
The...
 01:22
Problem Solving on Stress and Strain
 01:21
Stress Response System
Alarm stage
In the alarm stage, the body's initial...