Related Experiment Video
Updated: Jun 2, 2026
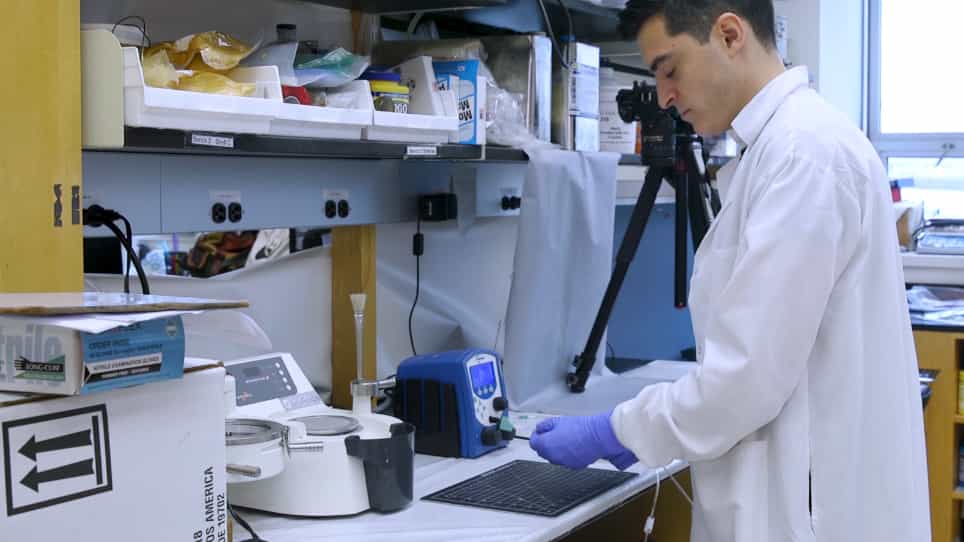
Rapid Manufacturing of Thin Soft Pneumatic Actuators and Robots
Published on: November 8, 2019
A dynamic linearization concept for piezoelectric actuators
Giovanni Biancuzzi1, Daniel Haller, Thomas Lemke
1Laboratory for Design of Microsystems at IMTEK, Department of Microsystems Engineering, University of Freiburg, Freiburg im Breisgau, Germany. Giovanni.Biancuzzi@imtek.de

Abstract:
We present a linearization circuit based on a capacitive Wheatstone bridge that is able to set a desired polarization in a piezoactuator. The system is meant to be used for dynamic actuation in a broad frequency range. A general nonlinear model for piezoactuators is presented in which two nonlinear sub-systems are cascaded: the electric-field-to-polarization (E-P) and the polarization-to-strain (P-x) blocks. The inversion of the latter sub-system in combination with the linearization bridge results in a reduction of up to 19 dB of the harmonic distortion of the actuator's mechanical displacement.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
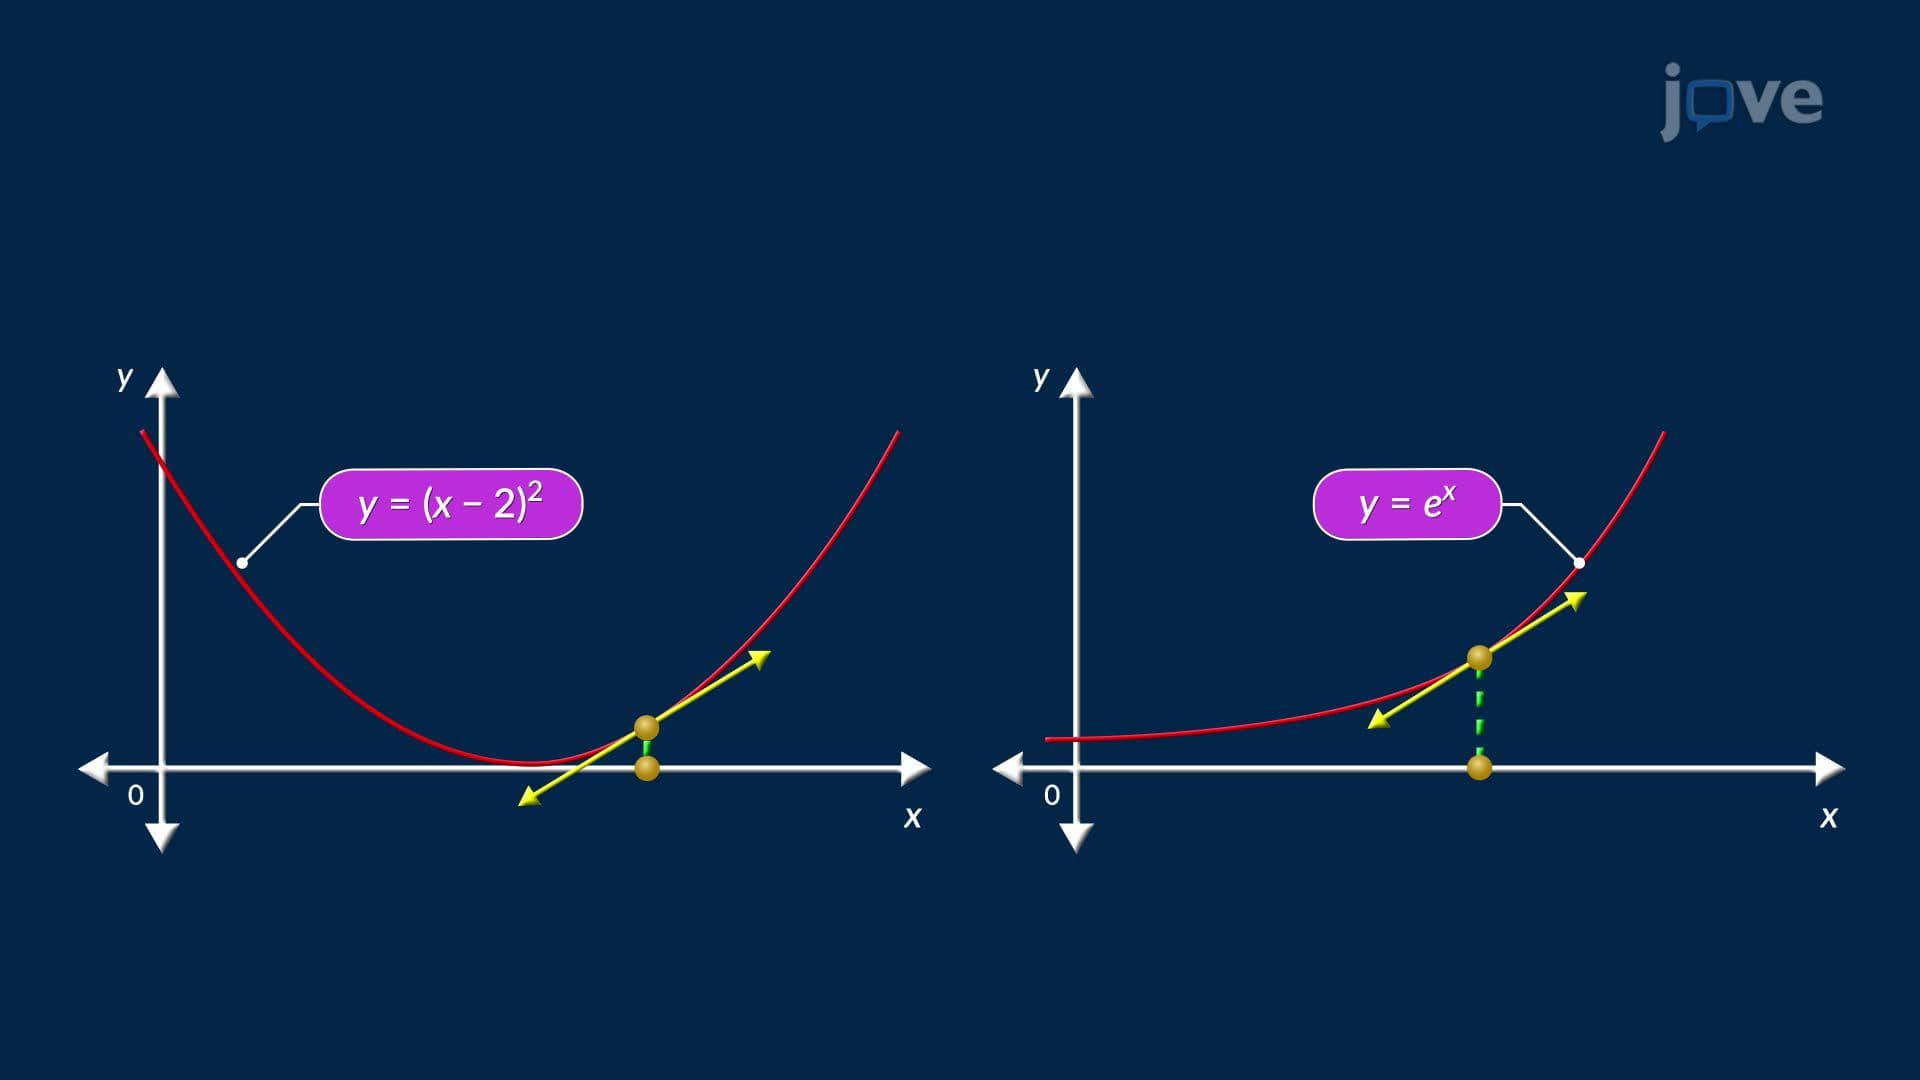
Linearization and Approximation
 01:24
PI Controller: Design
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:10
Relative Motion Analysis - Acceleration
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.