Related Experiment Video
Updated: Jun 2, 2026

An Analog Macroscopic Technique for Studying Molecular Hydrodynamic Processes in Dense Gases and Liquids
Published on: December 4, 2017
Bimodal response in periodically driven diffusive systems
Urna Basu1, Debasish Chaudhuri, P K Mohanty
1TCMP Division, Saha Institute of Nuclear Physics, 1/AF Bidhan Nagar, Kolkata 700064, India. urna.basu@saha.ac.in

Abstract:
We study the response of one-dimensional diffusive systems, consisting of particles interacting via symmetric or asymmetric exclusion, to time-periodic driving from two reservoirs coupled to the ends. The dynamical response of the system can be characterized in terms of the structure factor. We find an interesting frequency-dependent response; the current-carrying majority excitons cyclically crosses over from a short wavelength mode to a long wavelength mode with an intermediate regime of coexistence. This effect being boundary driven decays inversely with system size. Analytic calculations show that this behavior is common to diffusive systems, both in the absence and presence of correlations.
Related Concept Videos
 01:24
Transient and Steady-state Response
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state response.
 01:18
Second Order systems II
If ζ...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:20
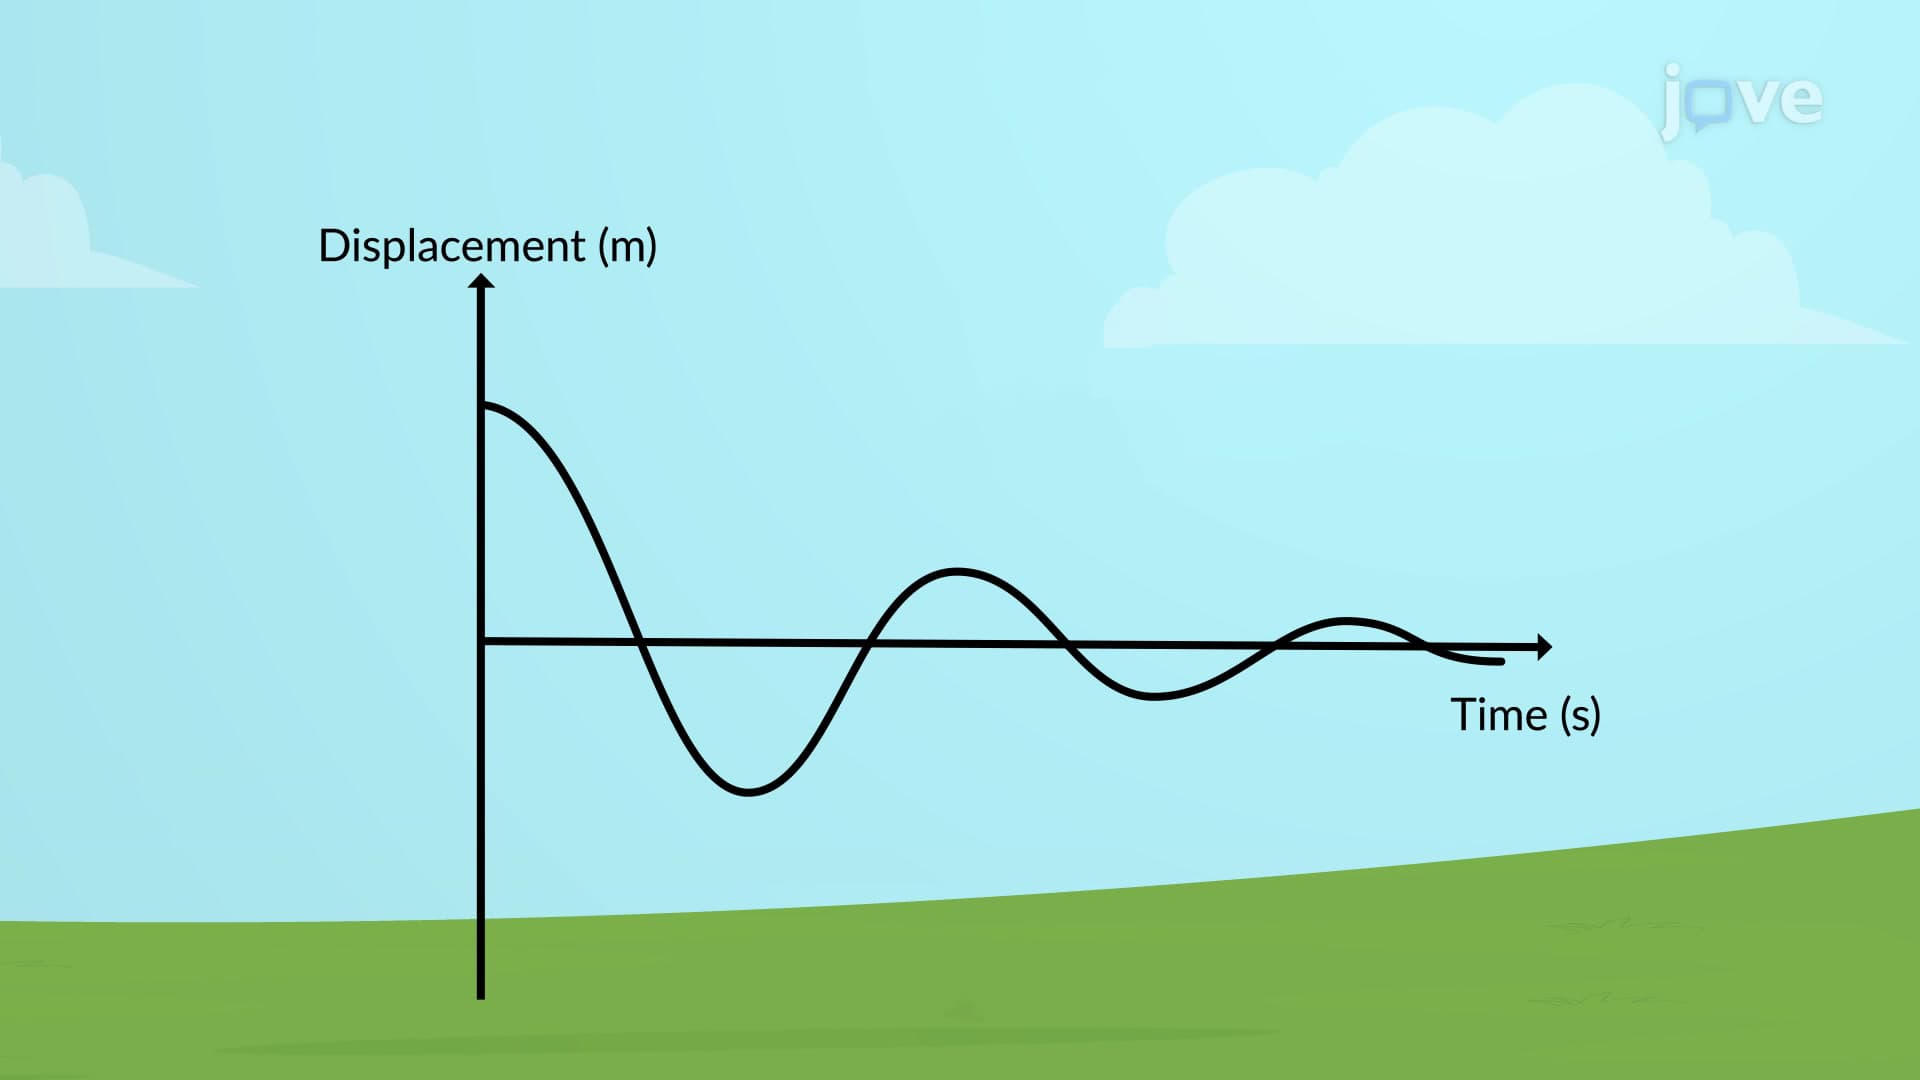
Types of Damping
 01:11
Types of Responses of Series RLC Circuits
 01:06
Forced Oscillations