Related Experiment Video
Updated: Jun 2, 2026
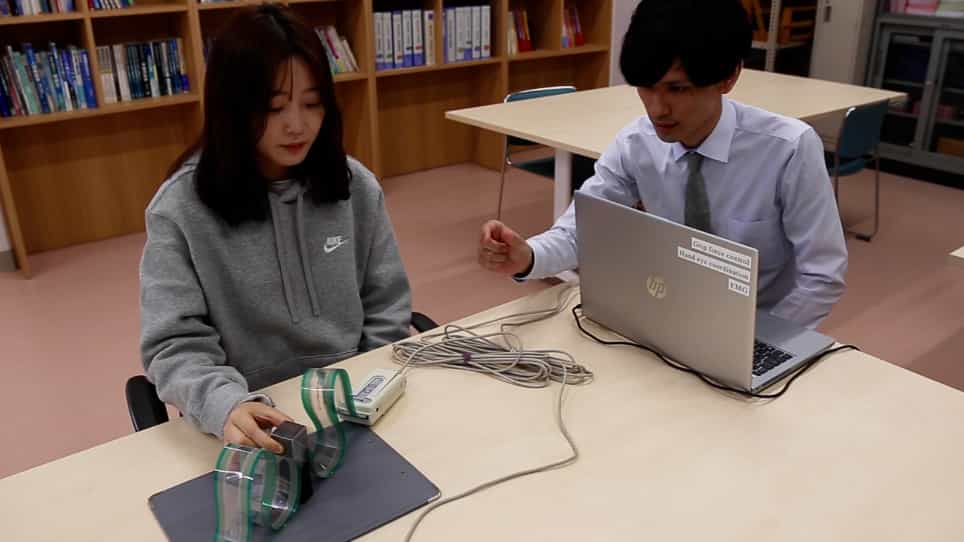

Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Coordination of contact forces during multifinger static prehension
Joel R Martin1, Mark L Latash, Vladimir M Zatsiorsky
1Department of Kinesiology, Pennsylvania State University, University Park, PA, USA.

Abstract:
This study investigated the effects of modifying contact finger forces in one direction-normal or tangential-on the entire set of the contact forces, while statically holding an object. Subjects grasped a handle instrumented with finger force-moment sensors, maintained it at rest in the air, and then slowly: (1) increased the grasping force, (2) tried to spread fingers apart, and (3) tried to squeeze fingers together. Analysis was mostly performed at the virtual finger (VF) level (the VF is an imaginable finger that generates the same force and moment as the four fingers combined). For all three tasks there were statistically significant changes in the VF normal and tangential forces. For finger spreading/squeezing the tangential force neutral point was located between the index and middle fingers. We conclude that the internal forces are regulated as a whole, including adjustments in both normal and tangential force, instead of only a subset of forces (normal or tangential). The effects of such factors as EFFORT and TORQUE were additive; their interaction was not statistically significant, thus supporting the principle of superposition in human prehension.

Related Concept Videos
 01:05
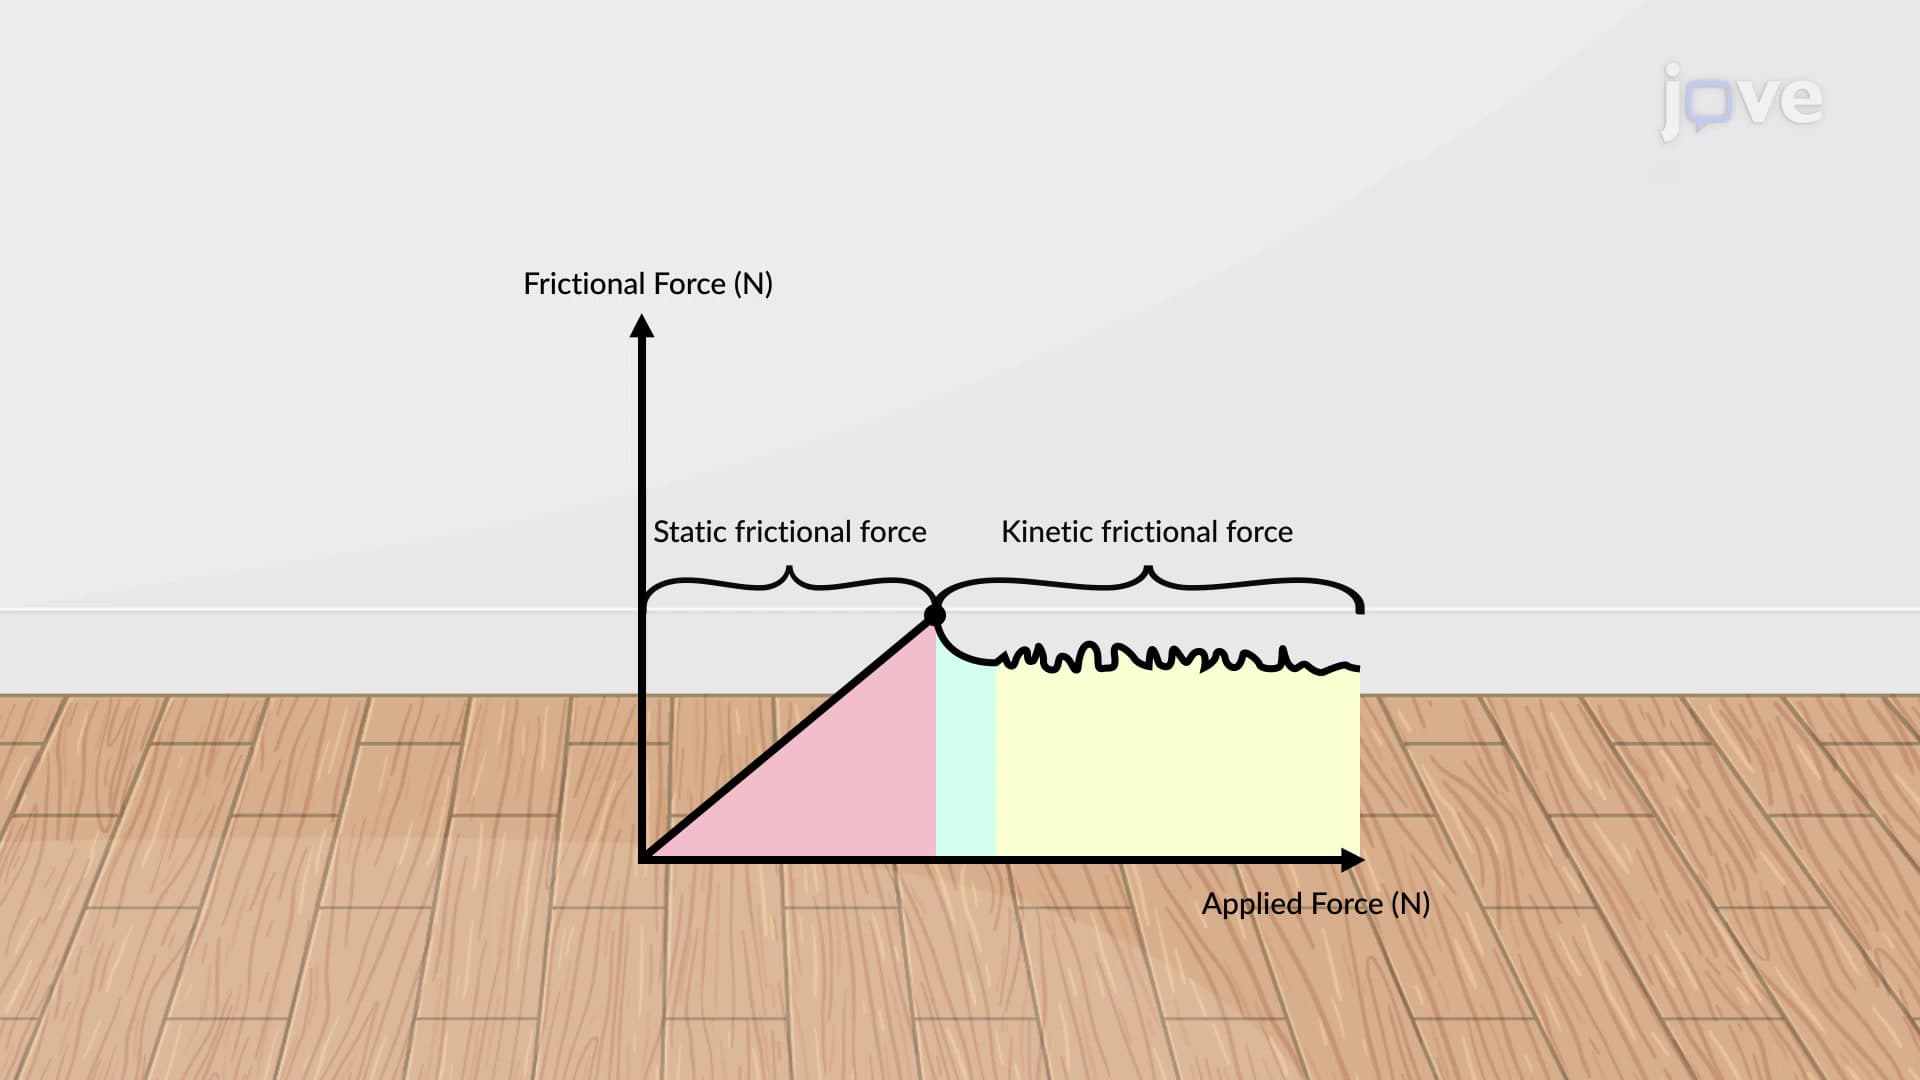
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi radialis,...
 01:30
Machines: Problem Solving II
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...