Related Experiment Video
Updated: Jun 1, 2026

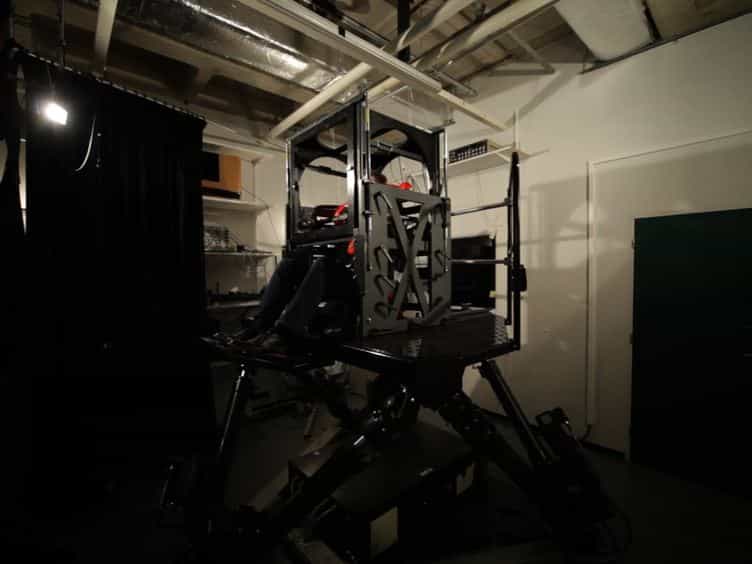
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Visuomotor coordination is different for different directions in three-dimensional space
Julian J Tramper1, C C A M Gielen
1Radboud University Nijmegen, Donders Institute for Brain, Cognition, and Behaviour, Department of Biophysics, 6525 EZ Nijmegen, The Netherlands. j.tramper@donders.ru.nl

Abstract:
In most visuomotor tasks in which subjects have to reach to visual targets or move the hand along a particular trajectory, eye movements have been shown to lead hand movements. Because the dynamics of vergence eye movements is different from that of smooth pursuit and saccades, we have investigated the lead time of gaze relative to the hand for the depth component (vergence) and in the frontal plane (smooth pursuit and saccades) in a tracking task and in a tracing task in which human subjects were instructed to move the finger along a 3D path. For tracking, gaze leads finger position on average by 28 ± 6 ms (mean ± SE) for the components in the frontal plane but lags finger position by 95 ± 39 ms for the depth dimension. For tracing, gaze leads finger position by 151 ± 36 ms for the depth dimension. For the frontal plane, the mean lead time of gaze relative to the hand is 287 ± 13 ms. However, we found that the lead time in the frontal plane was inversely related to the tangential velocity of finger. This inverse relation for movements in the frontal plane could be explained by assuming that gaze leads the finger by a constant distance of ∼ 2.6 cm (range of 1.5-3.6 cm across subjects).
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:10
Direction of Acceleration Vectors
 01:16
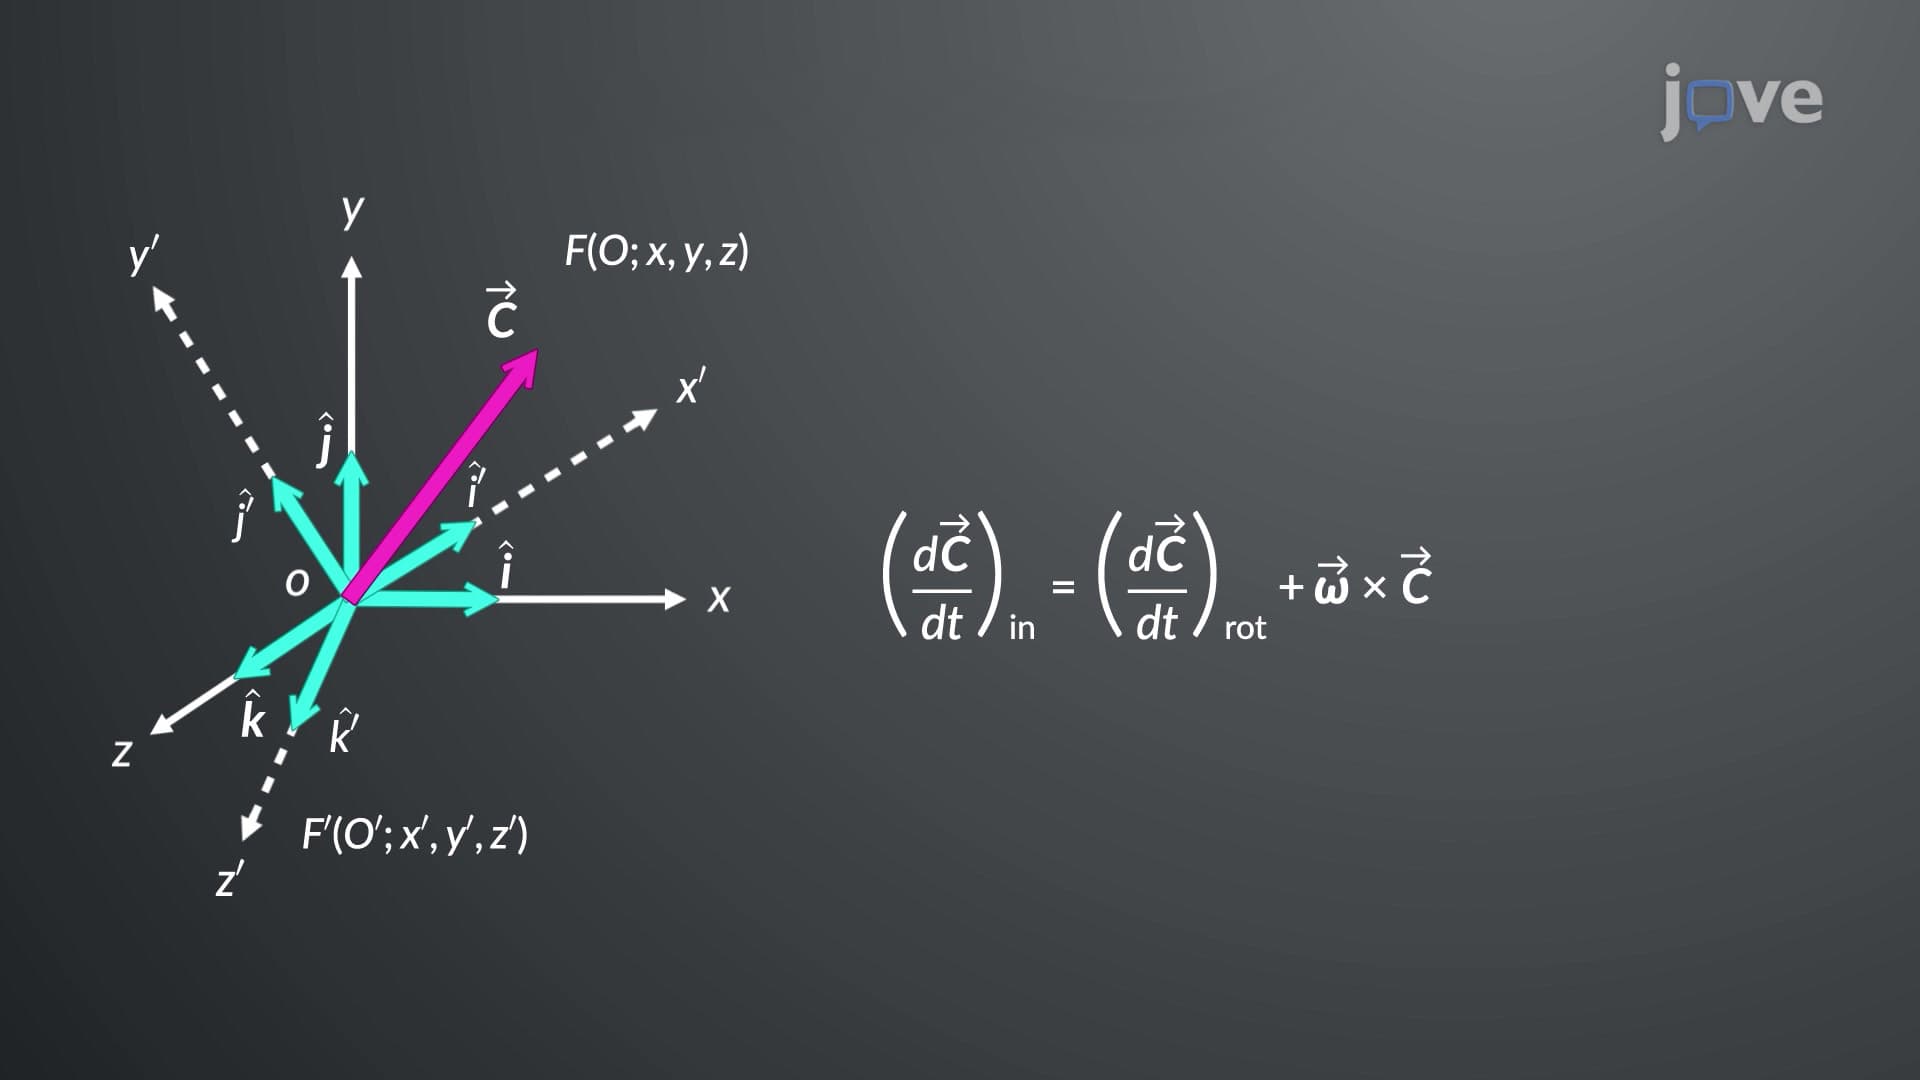
Vector Transformation in Rotating Coordinate Systems
 02:57
Coordination Number and Geometry
 01:18
Hierarchy of Motor Control
 01:11
Relative Velocity in Two Dimensions