Related Experiment Video
Updated: Jun 1, 2026


Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
In vivo dynamics of the musculoskeletal system cannot be adequately described using a stiffness-damping-inertia model
Dinant A Kistemaker1, Leonard A Rozendaal
1Department of Psychology, University of Western Ontario, London, Canada. dinant.kistemaker@gmail.com

Background:
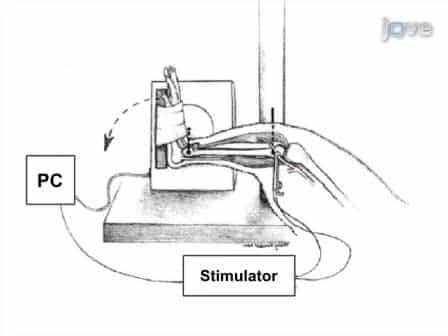
Visco-elastic properties of the (neuro-)musculoskeletal system play a fundamental role in the control of posture and movement. Often, these properties are described and identified using stiffness-damping-inertia (KBI) models. In such an approach, perturbations are applied to the (neuro-)musculoskeletal system and subsequently KBI-model parameters are optimized to obtain a best fit between simulated and experimentally observed responses. Problems with this approach may arise because a KBI-model neglects critical aspects of the real musculoskeletal system.
Methodology/Principal Findings:
The purpose of this study was to analyze the relation between the musculoskeletal properties and the stiffness and damping estimated using a KBI-model, to analyze how this relation is affected by the nature of the perturbation and to assess the sensitivity of the estimated stiffness and damping to measurement errors. Our analyses show that the estimated stiffness and damping using KBI-models do not resemble any of the dynamical parameters of the underlying system, not even when the responses are very accurately fitted by the KBI-model. Furthermore, the stiffness and damping depend non-linearly on all the dynamical parameters of the underlying system, influenced by the nature of the perturbation and the time interval over which the KBI-model is optimized. Moreover, our analyses predict a very high sensitivity of estimated parameters to measurement errors.
Conclusions/Significance:
The results of this study suggest that the usage of stiffness-damping-inertia models to investigate the dynamical properties of the musculoskeletal system under control by the CNS should be reconsidered.

Related Concept Videos
 01:07
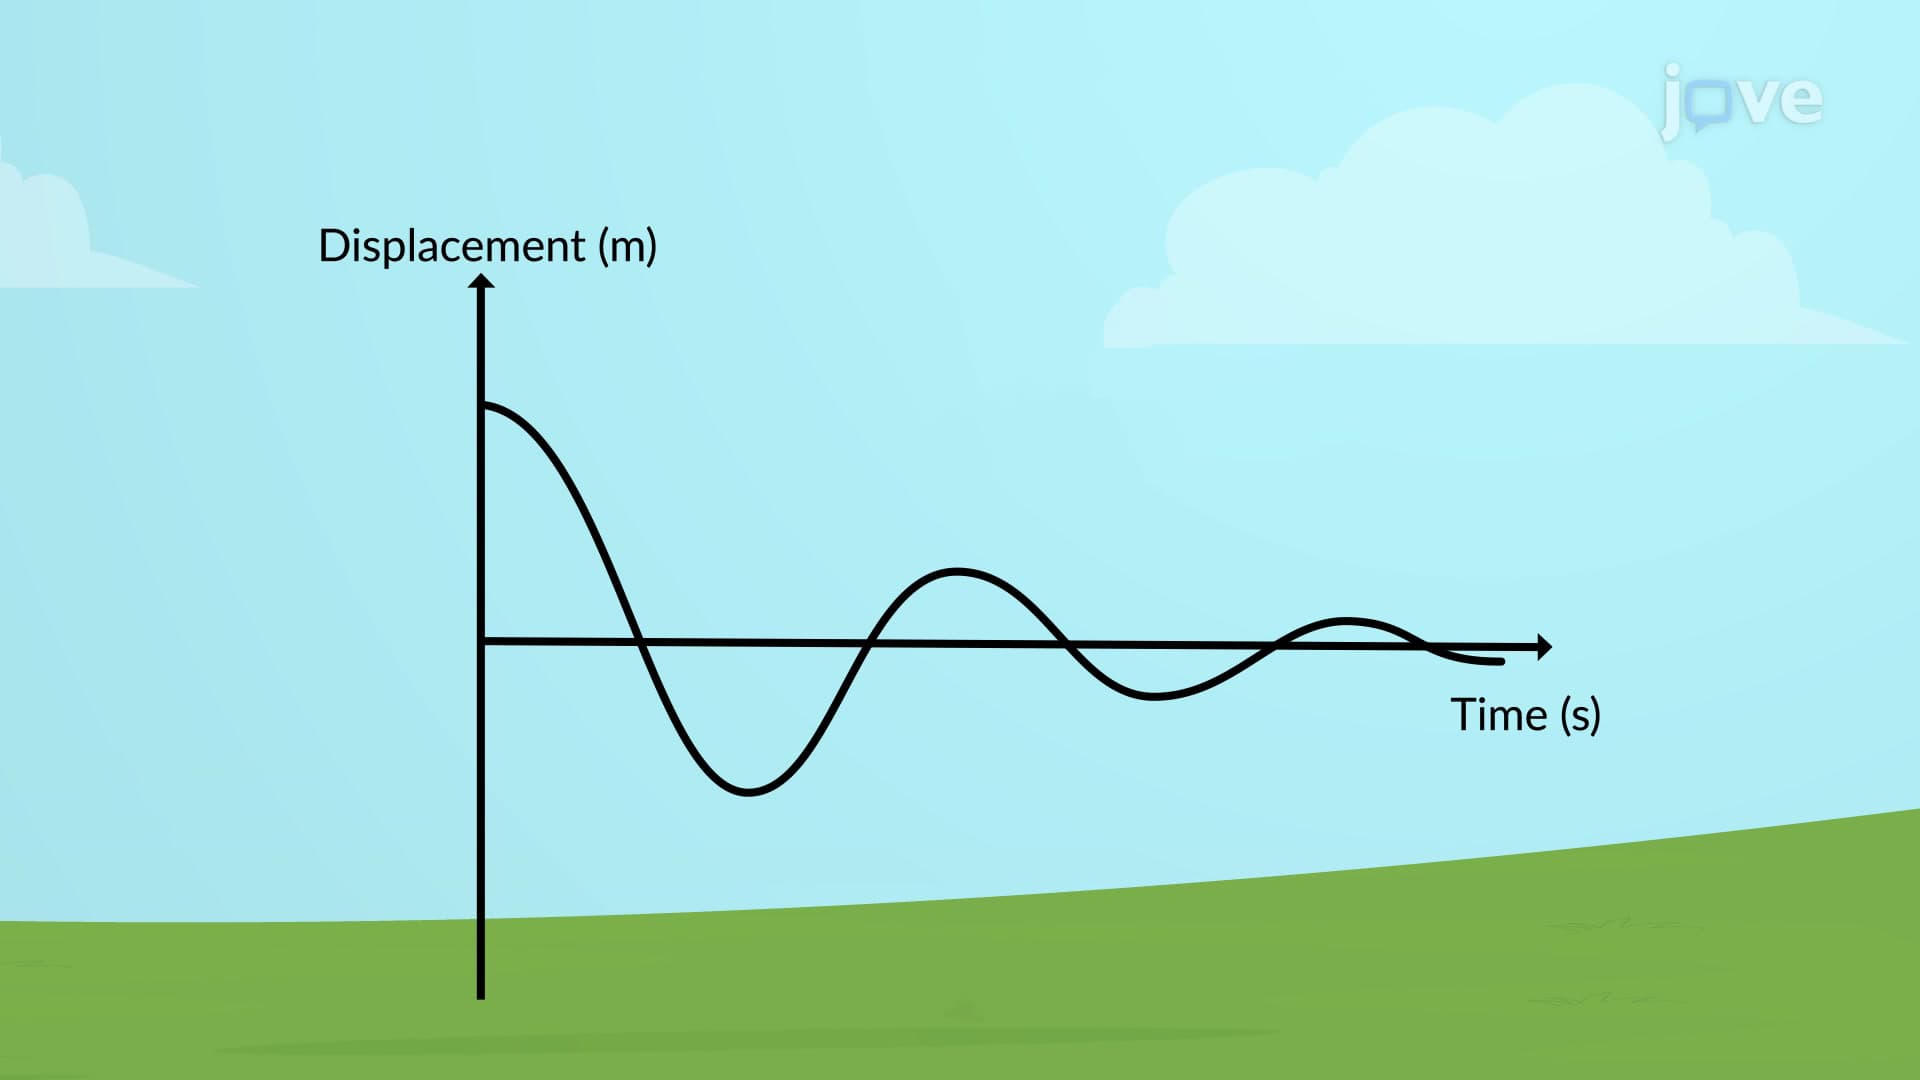
Damped Oscillations
Although friction and other non-conservative...
 01:20
Types of Damping
 01:05
Static Equilibrium - I
 01:22
Mechanical Systems
 01:18
Indeterminate Structure
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...