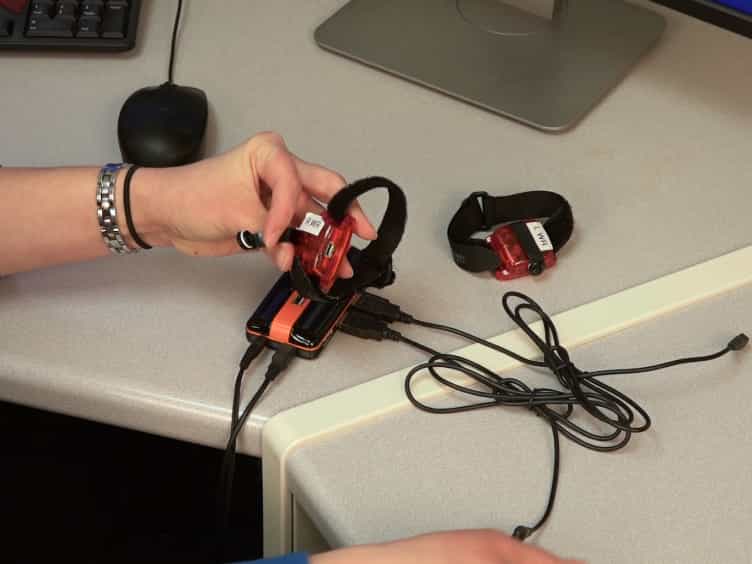
Related Experiment Video
Updated: Jun 1, 2026
Capturing Representative Hand Use at Home Using Egocentric Video in Individuals with Upper Limb Impairment
Published on: December 23, 2020
Ubiquitous human upper-limb motion estimation using wearable sensors
Zhi-Qiang Zhang1, Wai-Choong Wong, Jian-Kang Wu
1Department of Computing, Imperial College London, SW7 2AZ UK. z.zhang@imperial.ac.uk

Abstract:
Human motion capture technologies have been widely used in a wide spectrum of applications, including interactive game and learning, animation, film special effects, health care, navigation, and so on. The existing human motion capture techniques, which use structured multiple high-resolution cameras in a dedicated studio, are complicated and expensive. With the rapid development of microsensors-on-chip, human motion capture using wearable microsensors has become an active research topic. Because of the agility in movement, upper-limb motion estimation has been regarded as the most difficult problem in human motion capture. In this paper, we take the upper limb as our research subject and propose a novel ubiquitous upper-limb motion estimation algorithm, which concentrates on modeling the relationship between upper-arm movement and forearm movement. A link structure with 5 degrees of freedom (DOF) is proposed to model the human upper-limb skeleton structure. Parameters are defined according to Denavit-Hartenberg convention, forward kinematics equations are derived, and an unscented Kalman filter is deployed to estimate the defined parameters. The experimental results have shown that the proposed upper-limb motion capture and analysis algorithm outperforms other fusion methods and provides accurate results in comparison to the BTS optical motion tracker.