Related Experiment Video
Updated: May 31, 2026
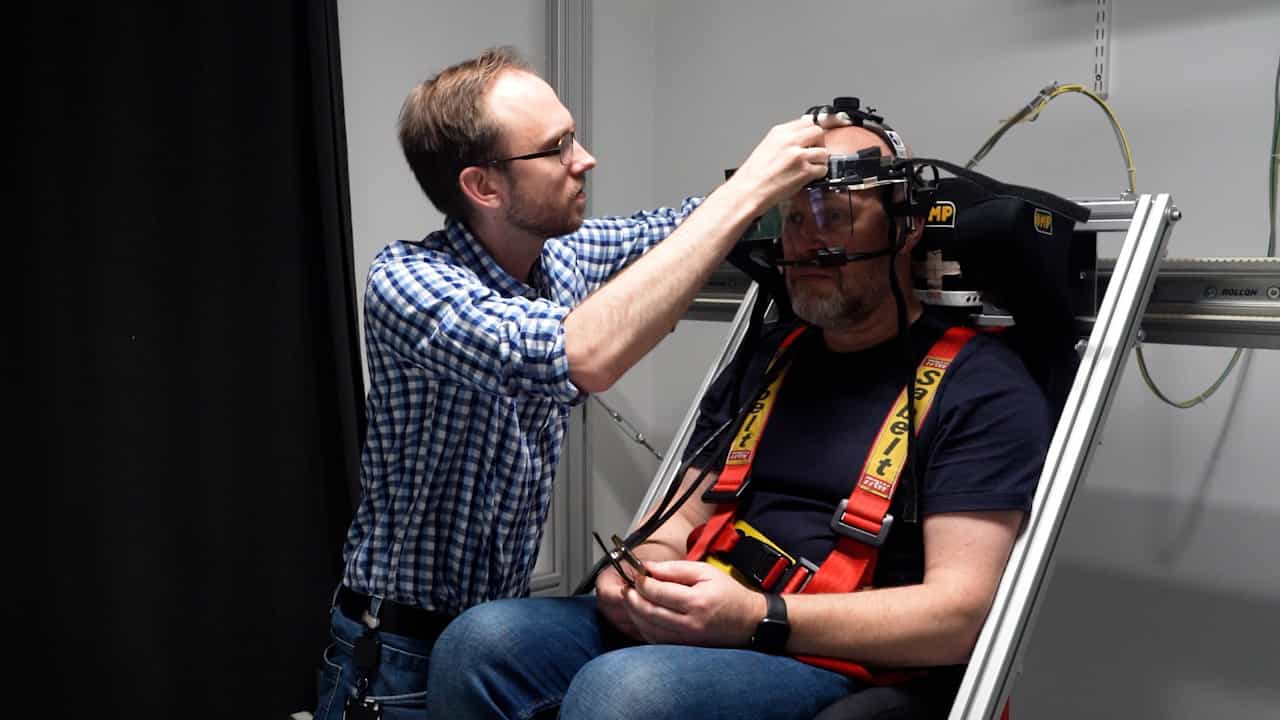
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Egomotion estimation with optic flow and air velocity sensors
Adam J Rutkowski1, Mikel M Miller, Roger D Quinn
1Air Force Research Laboratory/RW, Eglin AFB, FL 32542, USA. adam.rutkowski@eglin.af.mil

Abstract:
We develop a method that allows a flyer to estimate its own motion (egomotion), the wind velocity, ground slope, and flight height using only inputs from onboard optic flow and air velocity sensors. Our artificial algorithm demonstrates how it could be possible for flying insects to determine their absolute egomotion using their available sensors, namely their eyes and wind sensitive hairs and antennae. Although many behaviors can be performed by only knowing the direction of travel, behavioral experiments indicate that odor tracking insects are able to estimate the wind direction and control their absolute egomotion (i.e., groundspeed). The egomotion estimation method that we have developed, which we call the opto-aeronautic algorithm, is tested in a variety of wind and ground slope conditions using a video recorded flight of a moth tracking a pheromone plume. Over all test cases that we examined, the algorithm achieved a mean absolute error in height of 7% or less. Furthermore, our algorithm is suitable for the navigation of aerial vehicles in environments where signals from the Global Positioning System are unavailable.
Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:02
Gyroscope