Related Experiment Video
Updated: May 31, 2026

Integrating Visual Psychophysical Assays within a Y-Maze to Isolate the Role that Visual Features Play in Navigational Decisions
Published on: May 2, 2019
A computational model of visual anisotropy
Bart Ons1, Leopold Verstraelen, Johan Wagemans
1Laboratory of Experimental Psychology, University of Leuven, Leuven, Belgium.

Abstract:
Visual anisotropy has been demonstrated in multiple tasks where performance differs between vertical, horizontal, and oblique orientations of the stimuli. We explain some principles of visual anisotropy by anisotropic smoothing, which is based on a variation on Koenderink's approach in [1]. We tested the theory by presenting gaussian elongated luminance profiles and measuring the perceived orientations by means of an adjustment task. Our framework is based on the smoothing of the image with elliptical gaussian kernels and it correctly predicted an illusory orientation bias towards the vertical axis. We discuss the scope of the theory in the context of other anisotropies in perception.
Related Concept Videos
 01:24
Vision
 01:27
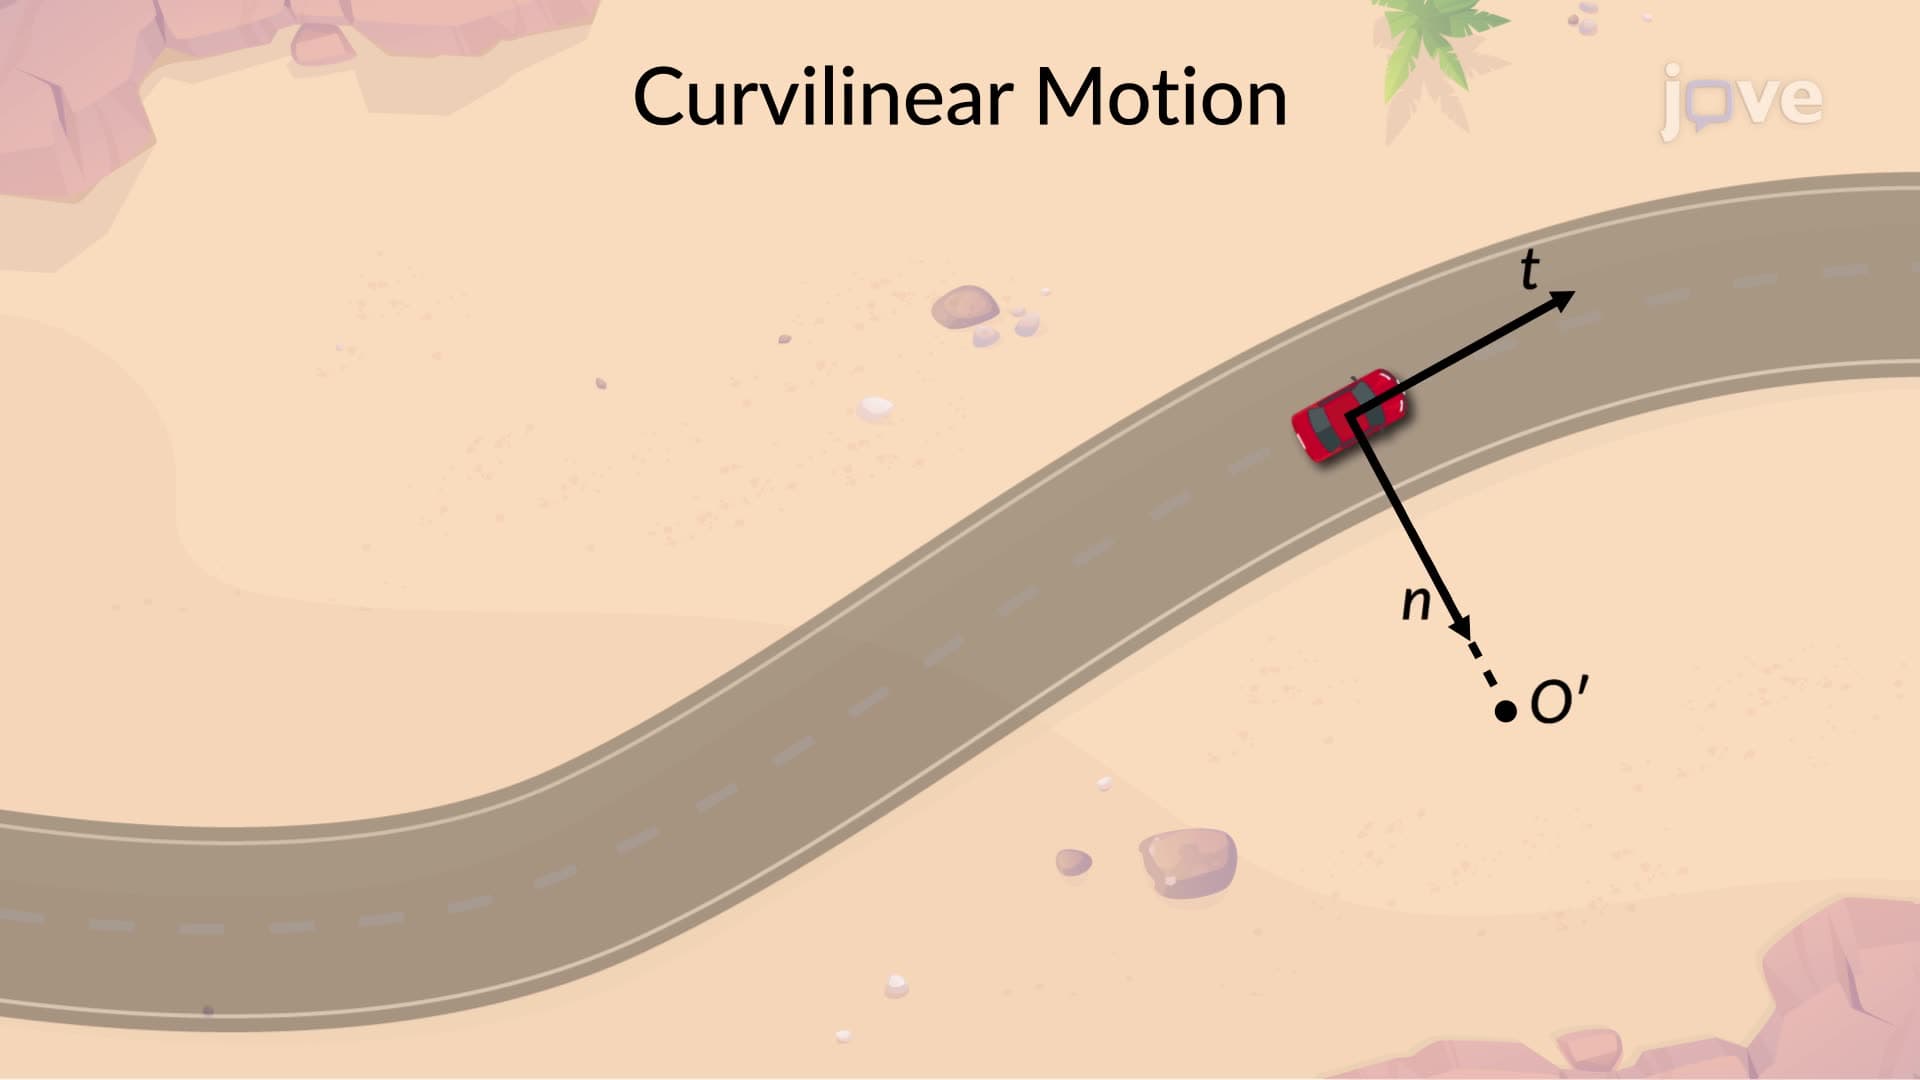
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:15
Depth Perception and Spatial Vision
 01:12
Perceptual Constancy
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...