Quad-trees, oct-trees, and k-trees: a generalized approach to recursive decomposition of euclidean space

C L Jackins1, S L Tanimoto

  • 11943 7th Avenue West, Seattle, WA 98119.

Related Concept Videos

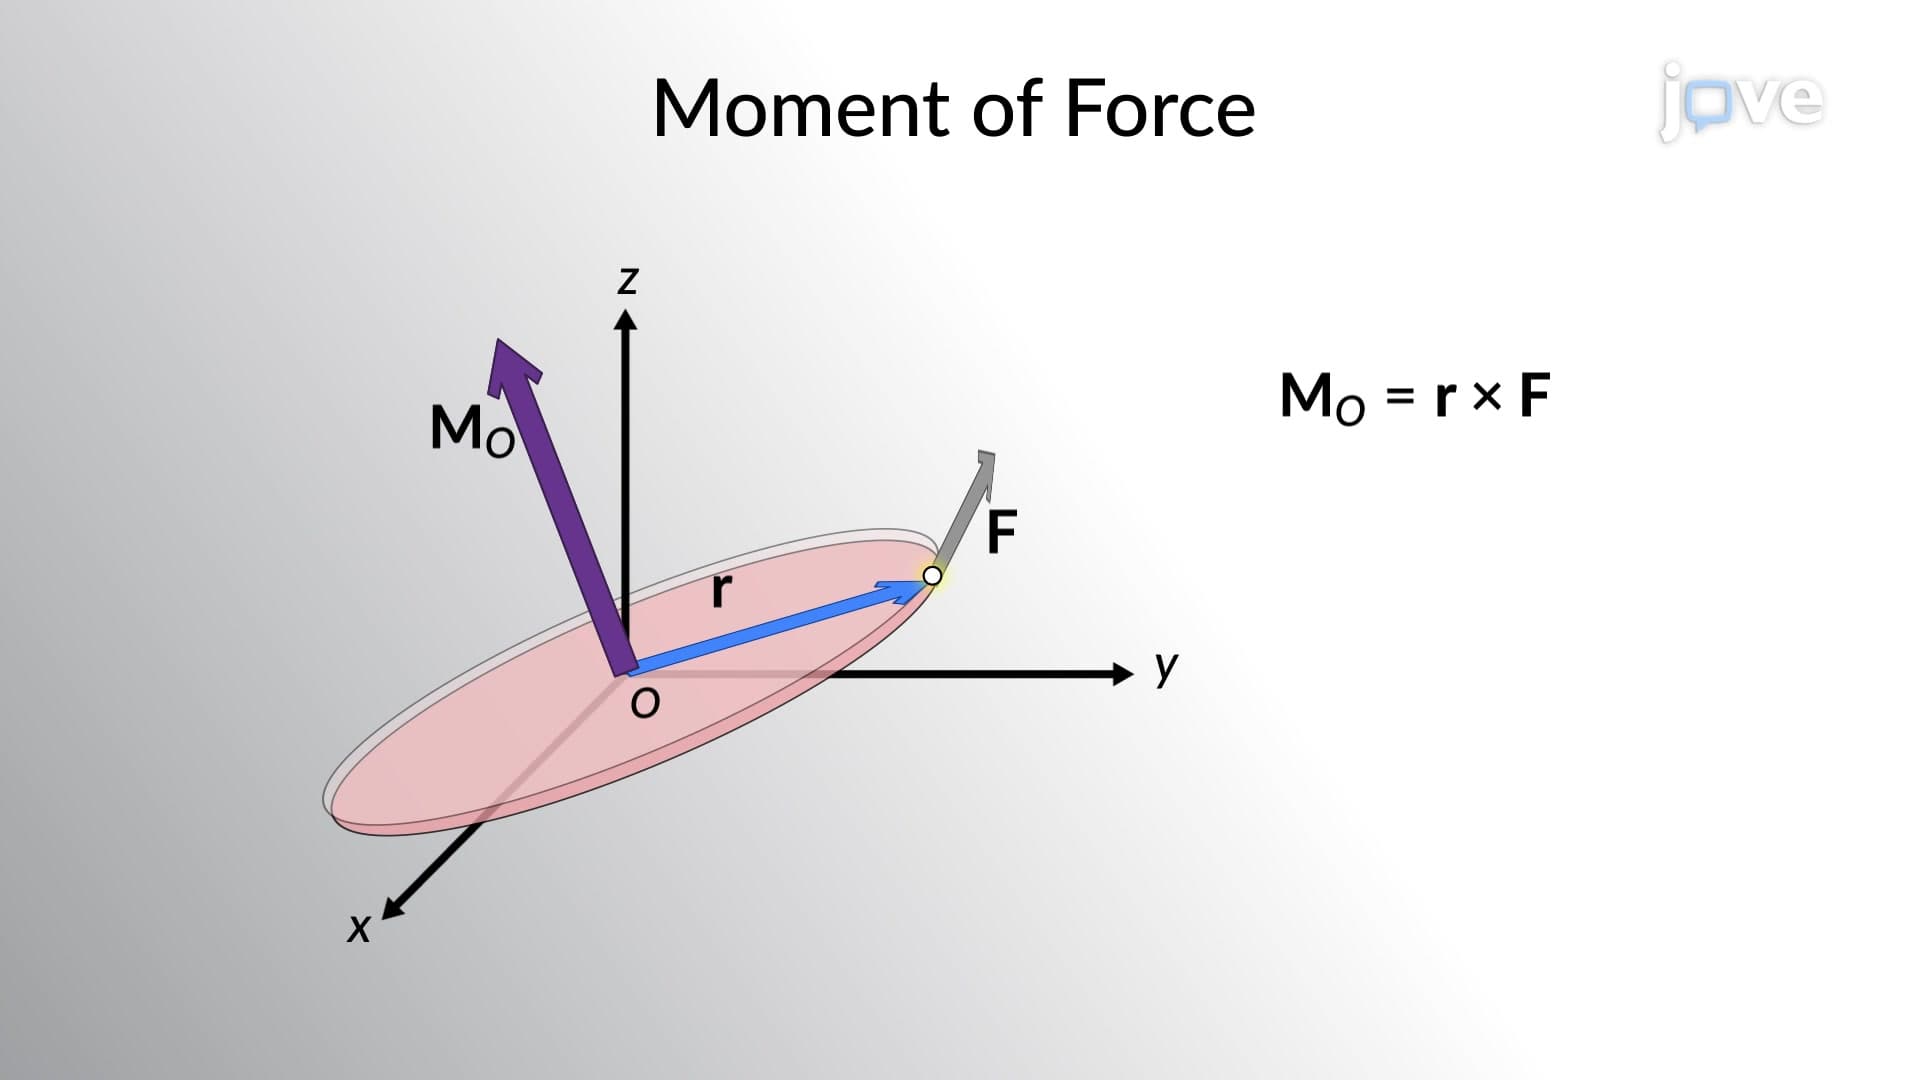
Cartesian Vector Notation01:28

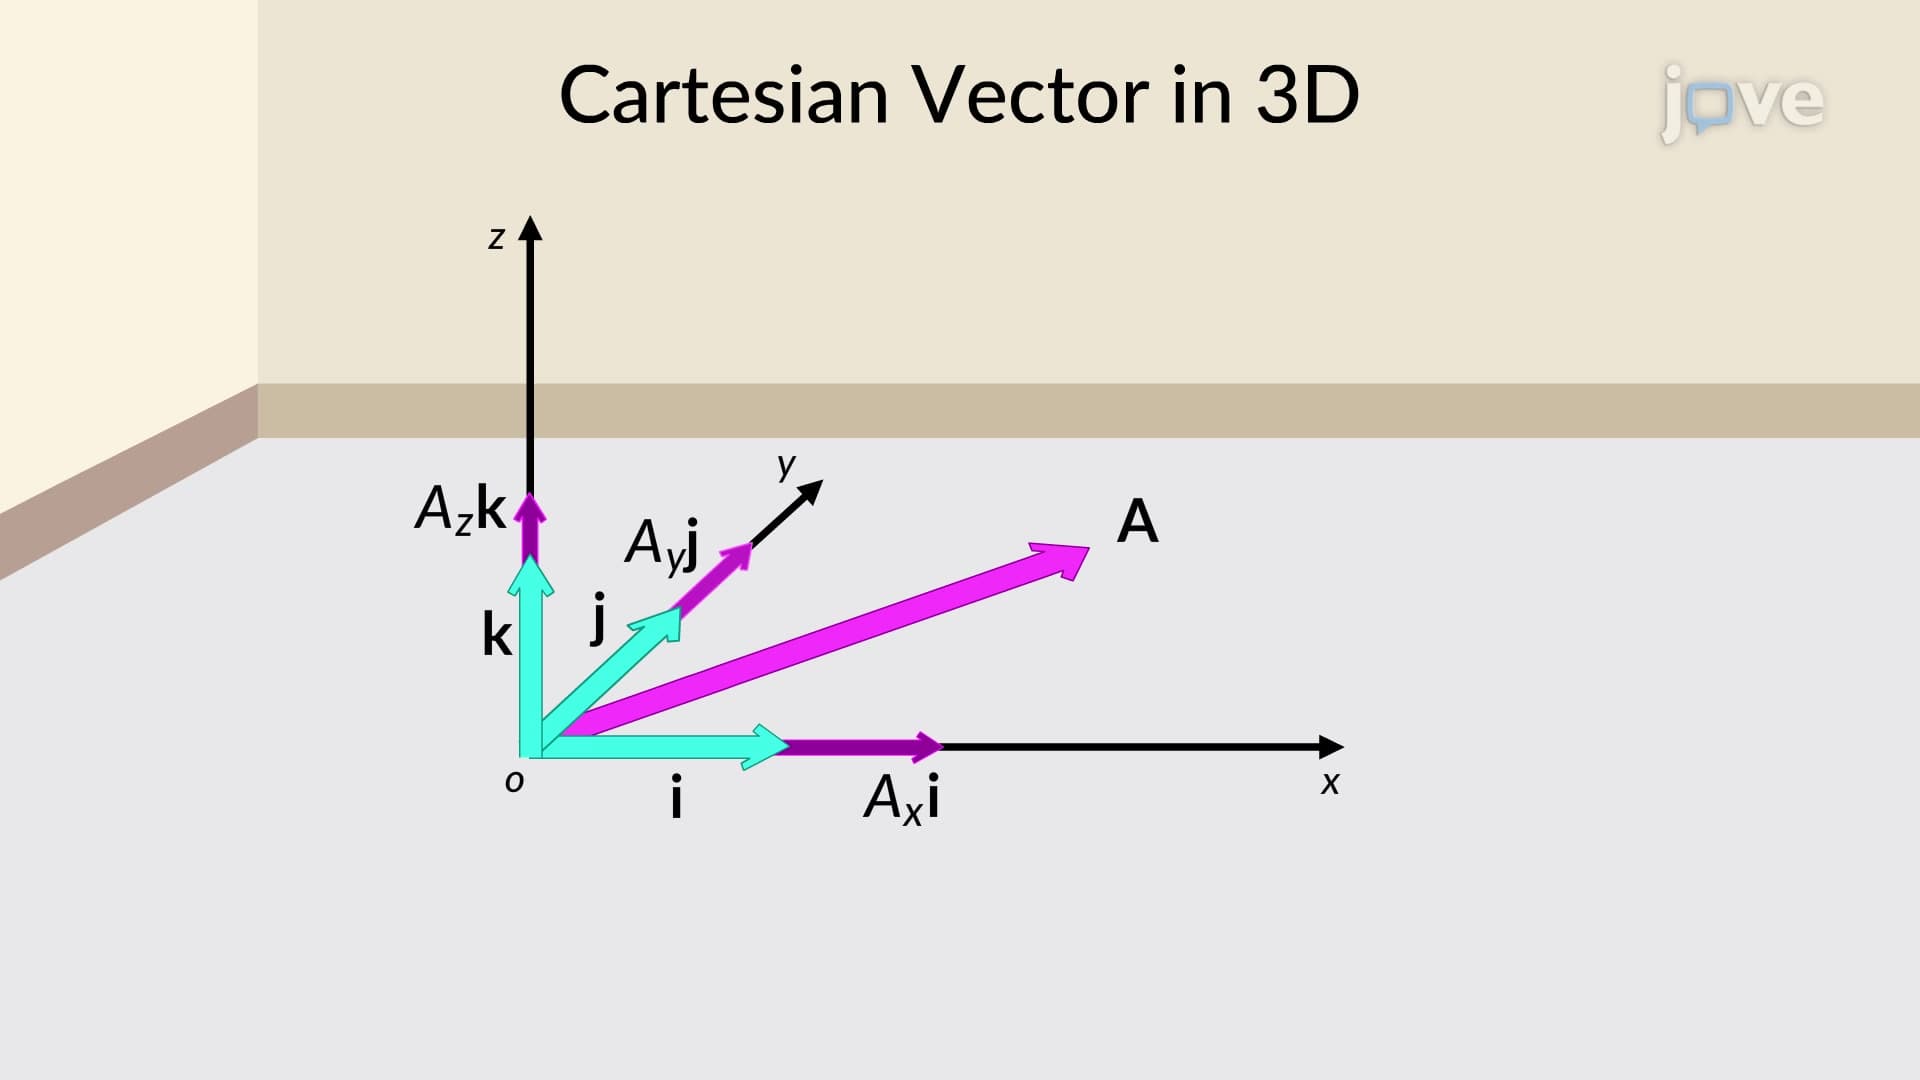
Cartesian Vector Notation

Cartesian vector notation is a valuable tool in mechanical engineering for representing vectors in three-dimensional space, performing vector operations such as determining the gradient, divergence, and curl, and expressing physical quantities such as the displacement, velocity, acceleration, and force. By using Cartesian vector notation, engineers can more easily analyze and solve problems in various areas of mechanical engineering, including dynamics, kinematics, and fluid mechanics. This...
Survival Tree01:19

Survival Tree

Survival trees are a non-parametric method used in survival analysis to model the relationship between a set of covariates and the time until an event of interest occurs, often referred to as the "time-to-event" or "survival time." This method is particularly useful when dealing with censored data, where the event has not occurred for some individuals by the end of the study period, or when the exact time of the event is unknown.
 Building a Survival Tree
Constructing a survival tree begins...
Quadratic Equations01:29

Quadratic Equations

A quadratic equation is an algebraic expression where a variable is raised to the second power and combined with its first power and a constant; all equated to zero. These equations are frequently used to model relationships involving area, motion, and optimization. The general representation of a quadratic equation iswhere a, b, and c are real values, and a is nonzero to ensure the presence of the squared term.One method for solving a quadratic equation involves rewriting it as a product of...
Parallel-axis Theorem01:06

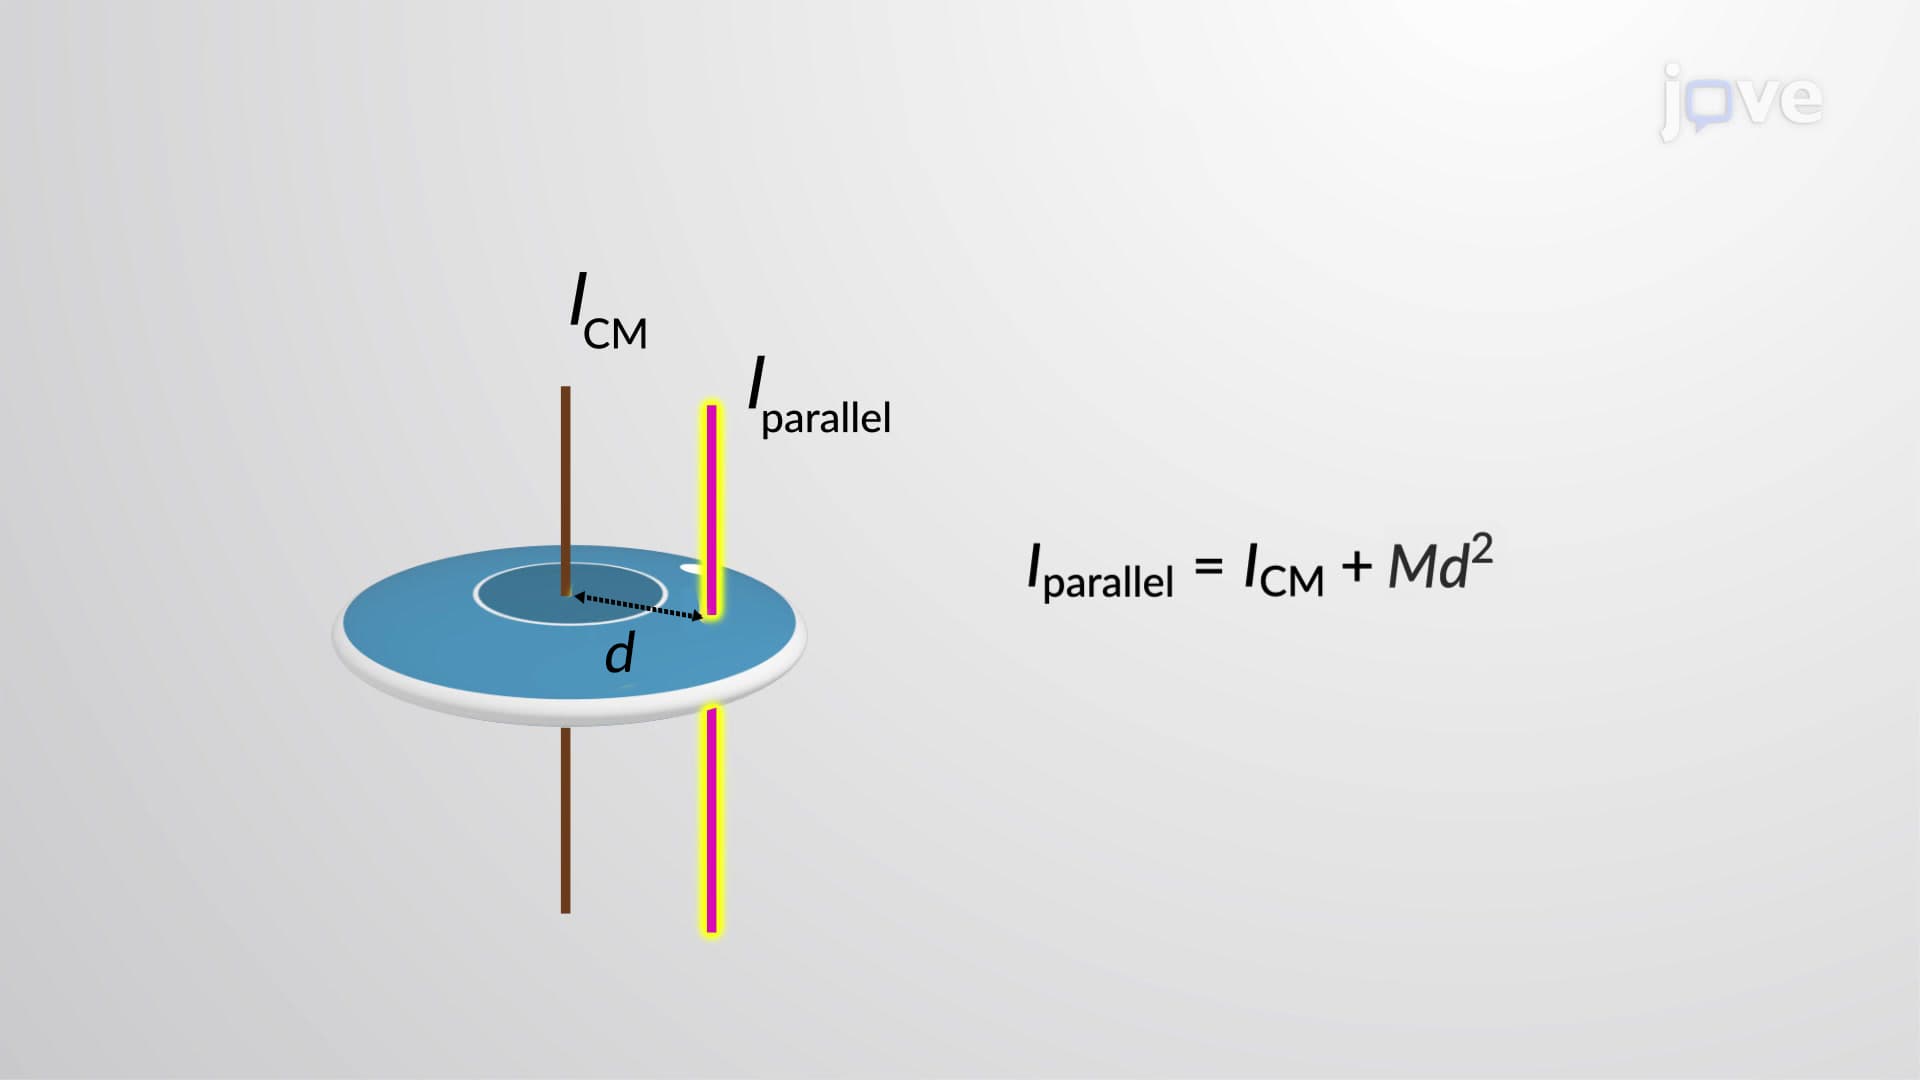
Parallel-axis Theorem

The parallel-axis theorem provides a convenient and quick method of finding the moment of inertia of an object about an axis parallel to the axis passing through its center of mass. Consider a thin rod as an example. There is a striking similarity between the process of finding the moment of inertia of a thin rod about an axis through its middle, where the center of mass lies, and about an axis through its end using the conventional method. In the conventional method, the concept of linear mass...
Cartesian Form for Vector Formulation01:26

Cartesian Form for Vector Formulation
The Cartesian form for vector formulation is a process to calculate  the moment of force using the position and force vectors. The moment of force is defined as the cross-product of these vectors, making it a vector quantity. The Cartesian form of the position and force vectors involves unit vectors, which can be used to express the cross-product in determinant form.
Quadratic Models01:23

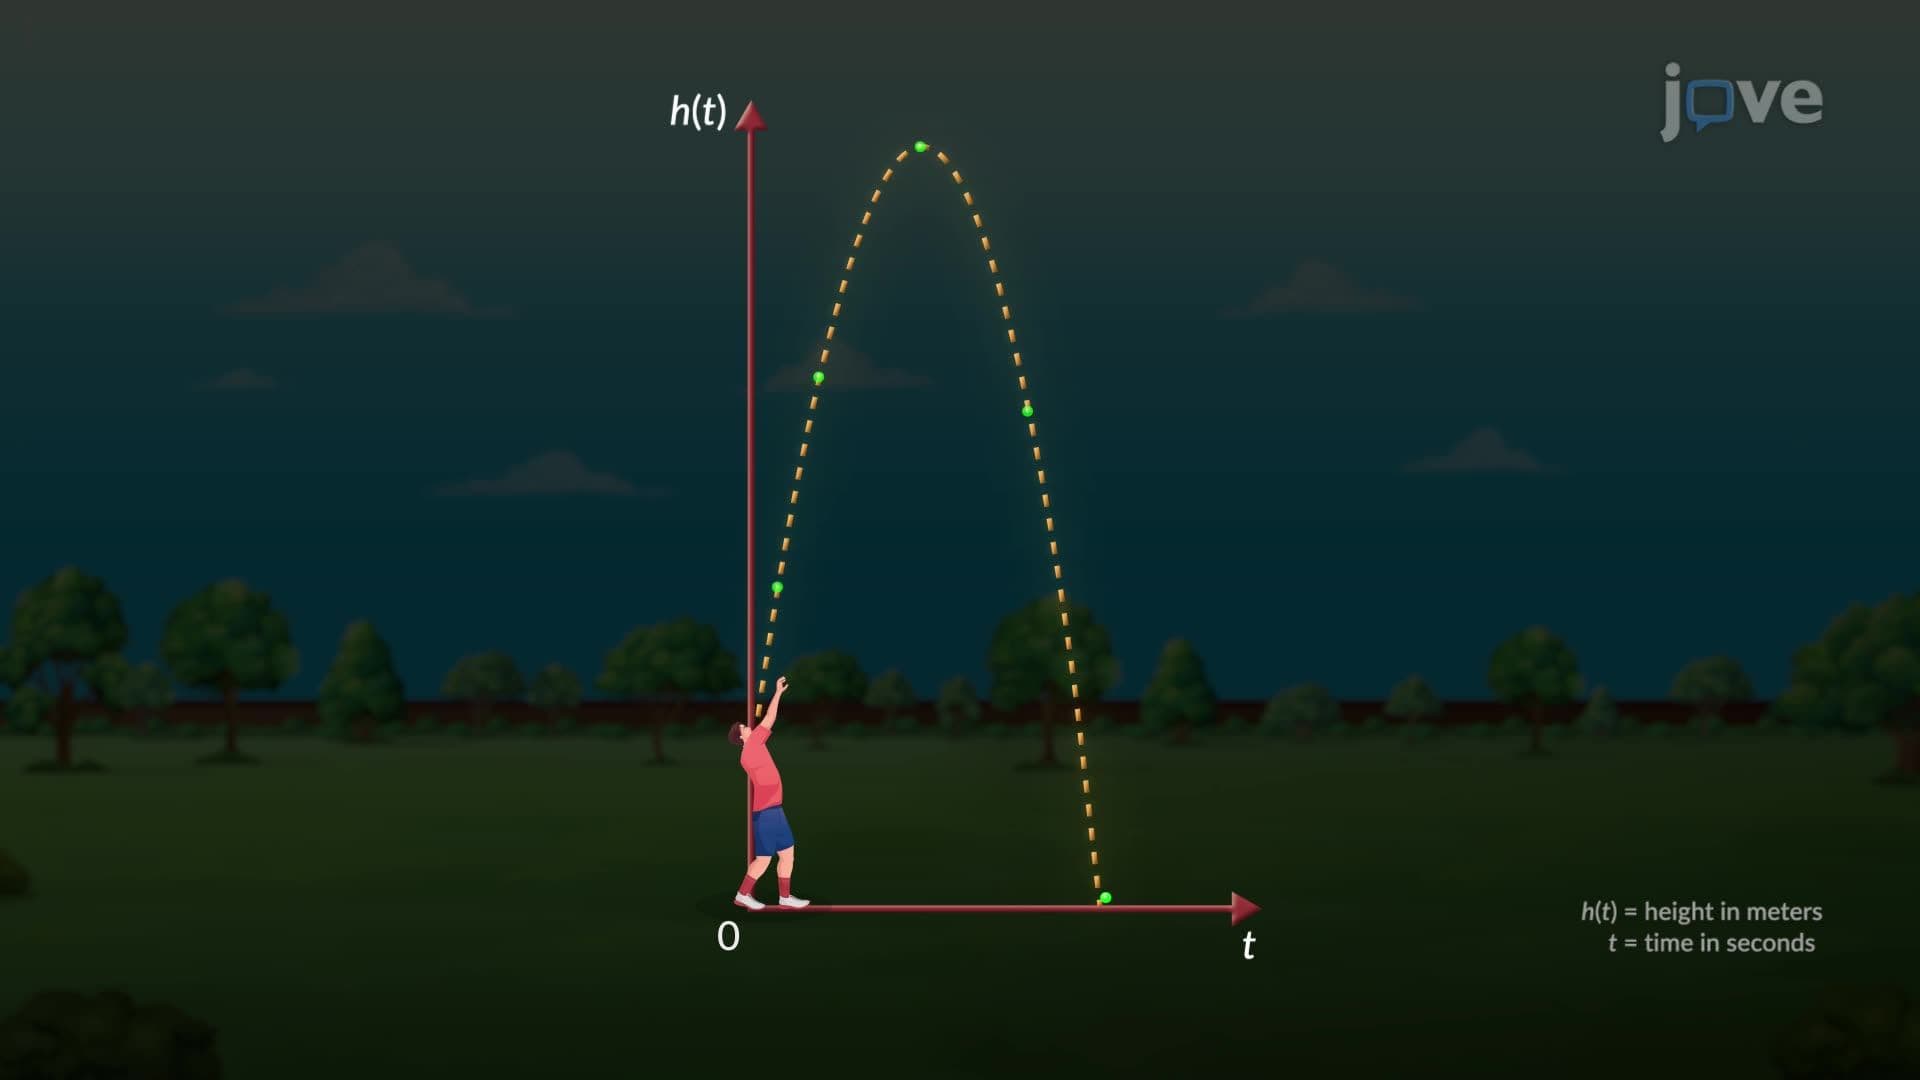
Quadratic Models

Quadratic models are mathematical representations used to describe relationships in which the rate of change changes at a constant rate. These models appear in a wide variety of natural and engineered systems, especially those involving motion, forces, and optimization. One common application is analyzing the vertical motion of objects influenced by gravity, such as a ball thrown into the air.In such scenarios, the object's height changes over time in a curved pattern, rising to a maximum point...