Shape information from rotated scans
Related Experiment Video
Updated: May 29, 2026
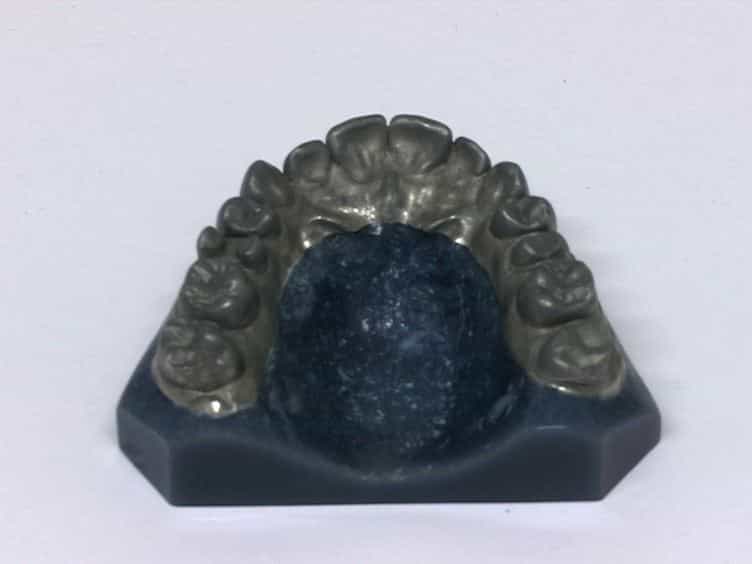
Accuracy in Dental Medicine, A New Way to Measure Trueness and Precision
Published on: April 29, 2014
1AT&TBell Laboratories, Murray Hill, NJ 07974.

Abstract:
In many proposed applications, robots are required to recognize a relatively small number of object types, each well defined by shape. In such cases, relatively simple pattern recognition methods may be adequate. This paper presents a number of exceptionally simple shape discrimination algorithms which exploit the particularly covenient data provided by the combination of a rotating camera and analog edge finder proposed by Miller and Boie.

Related Concept Videos
 01:11
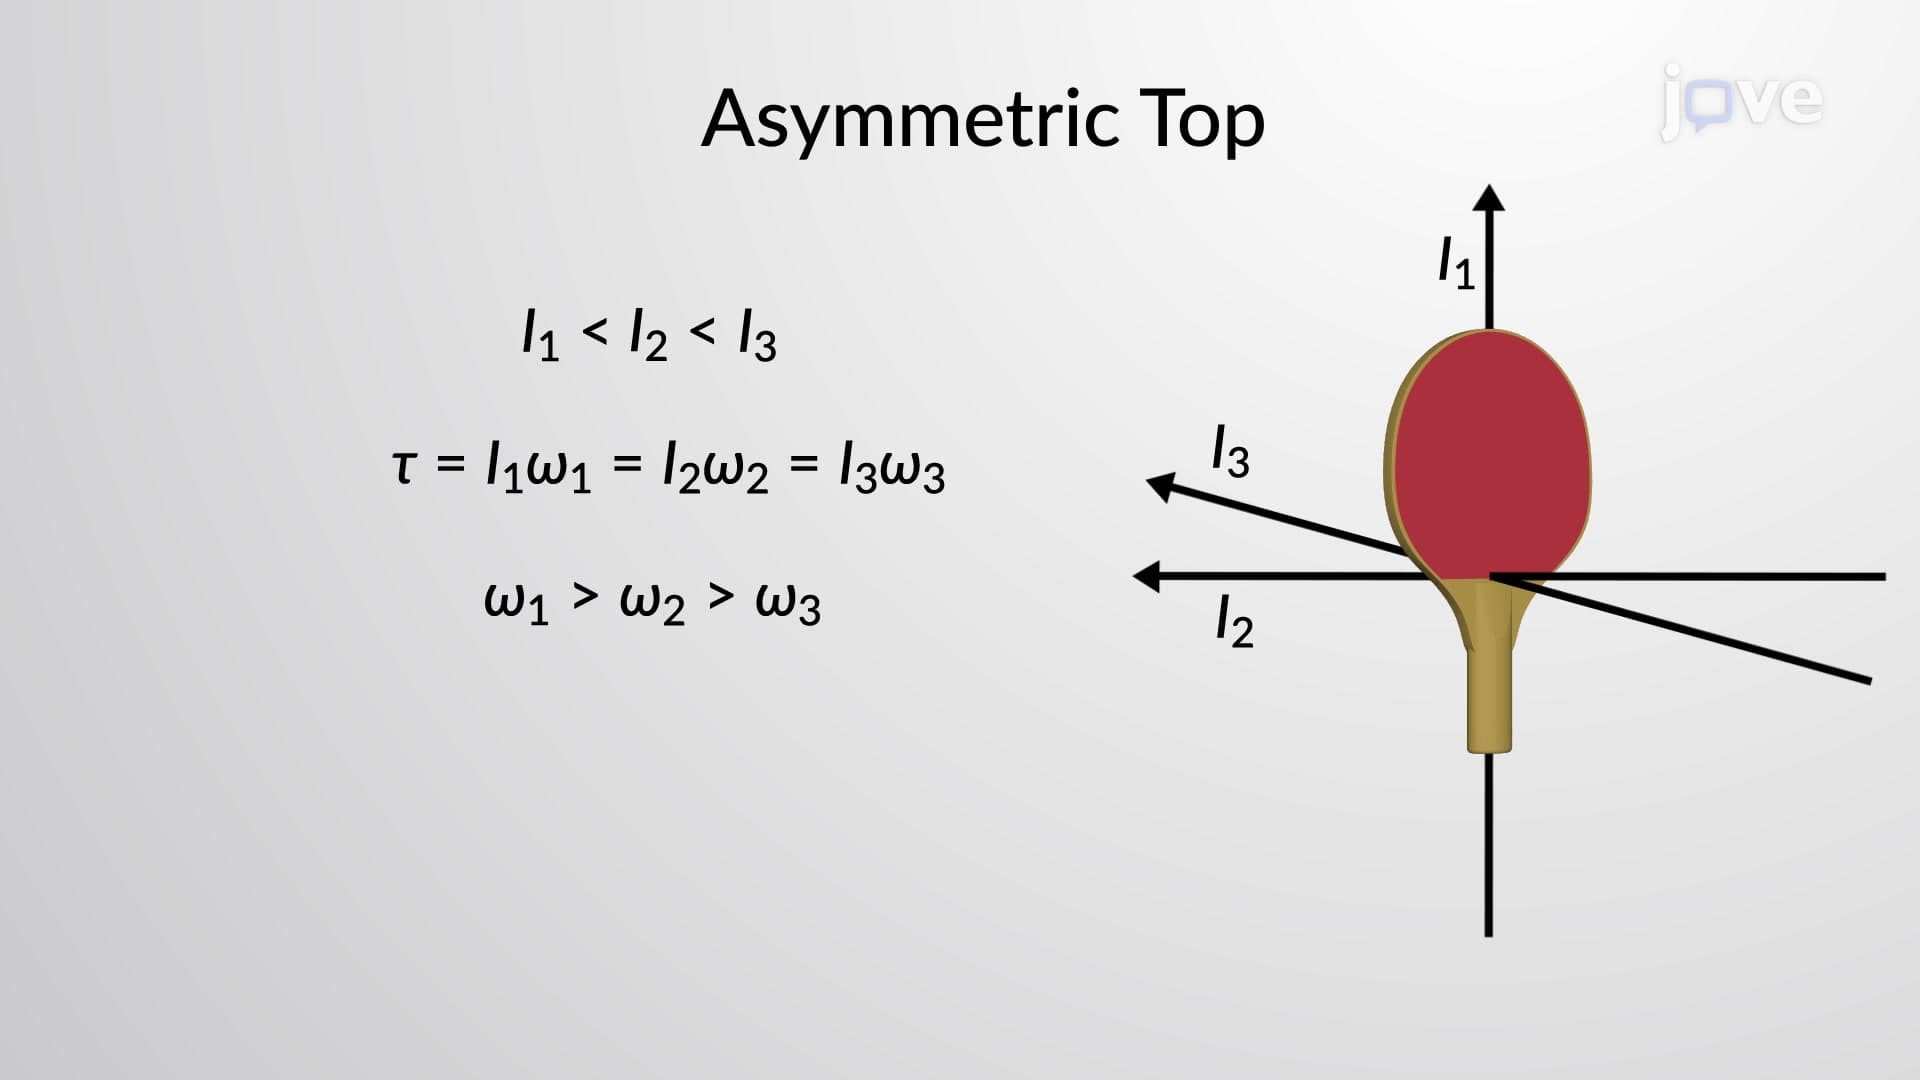
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:12
Transformation of Plane Strain
Under plane strain conditions, typical for members where one dimension significantly exceeds the others, deformations and resultant strains are...
 01:18
Transformation of Plane Stress
 01:16
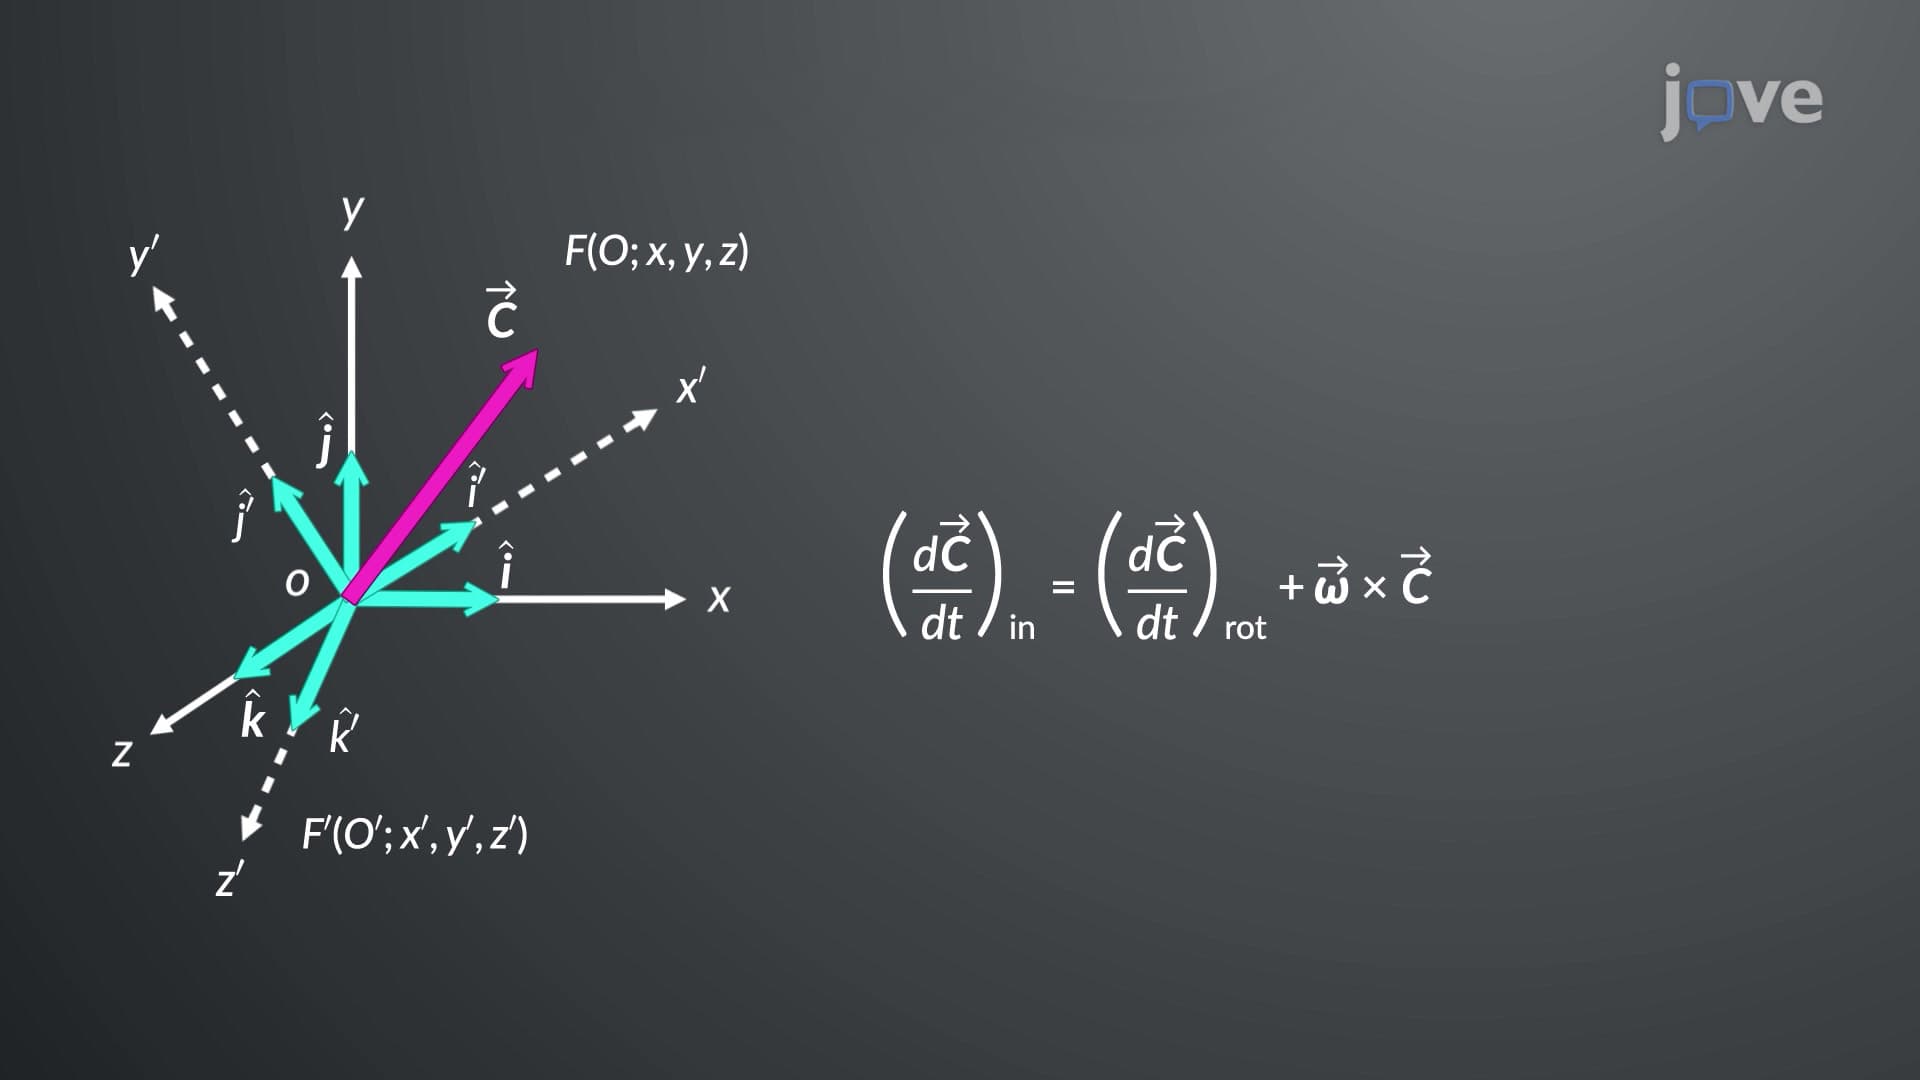
Vector Transformation in Rotating Coordinate Systems
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...