Related Experiment Video
Updated: May 29, 2026
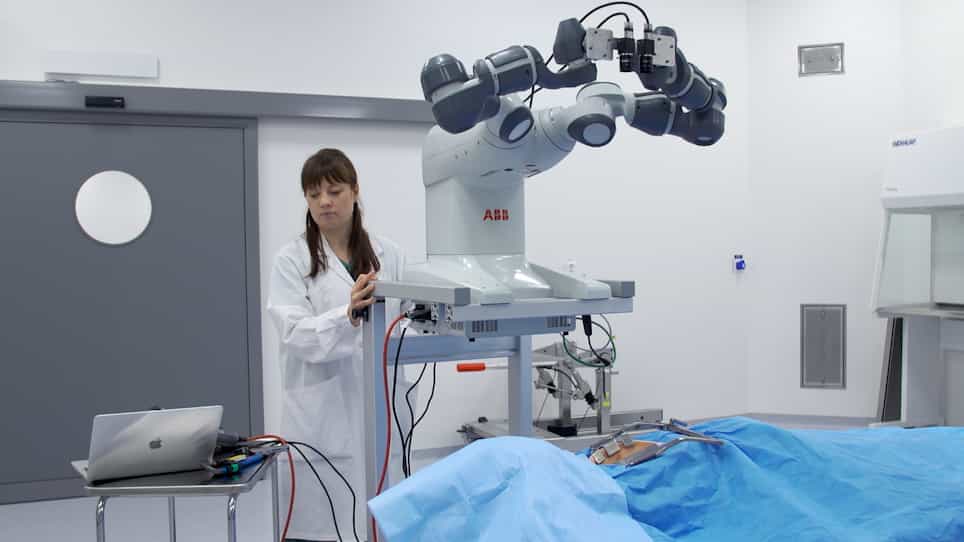
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Error analysis in stereo determination of 3-d point positions
1Coordinated Science Laboratory, University of Illinois at Urbana-Champaign, Urbana, IL 61801.

Abstract:
The relationship between the geometry of a stereo camera setup and the accuracy in obtaining three-dimensional position information is of great practical importance in many imaging applications. Assuming a point in a scene has been correctly identified in each image, its three-dimensional position can be recovered via a simple geometrical method known as triangulation. The probability that position estimates from triangulation are within some specified error tolerance is derived. An ideal pinhole camera model is used and the error is modeled as known spatial image plane quantization. A point's measured position maps to a small volume in 3-D determined by the finite resolution of the stereo setup. With the assumption that the point's actual position is uniformly distributed inside this volume, closed form expressions for the probability distribution of error in position along each coordinate direction (horizontal, vertical, and range) are derived. Following this, the probability that range error dominates over errors in the point's horizontal or vertical position is determined. It is hoped that the results presented will have an impact upon both sensor design and error modeling of position measuring systems for computer vision and related applications.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Three-Dimensional Analysis of Strain
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...