Related Experiment Video
Updated: May 28, 2026
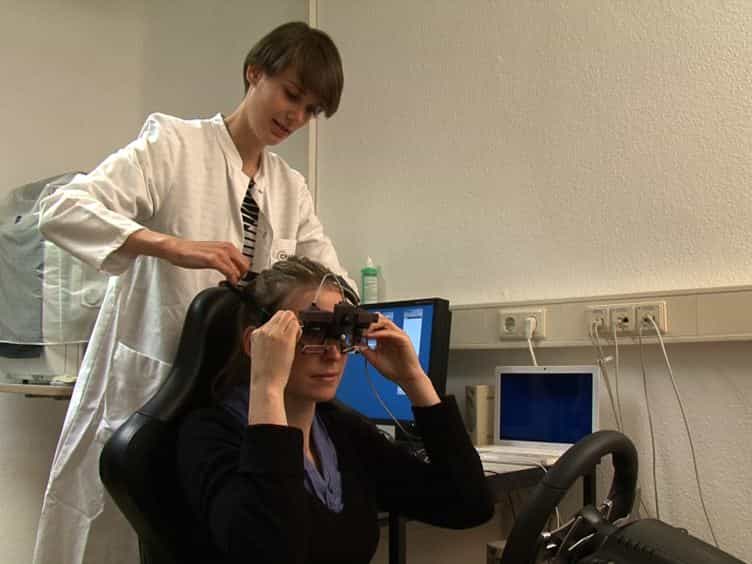

Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Heading but not path or the tau-equalization strategy is used in the visual control of steering toward a goal
1Department of Psychology, The University of Hong Kong, Hong Kong SAR. lili@hku.hk

Abstract:
The visual strategies for the control of steering toward a goal include aligning one's instantaneous direction of travel (i.e., heading; J. J. Gibson, 1950) or the future path (J. P. Wann & D. K. Swapp, 2000) specified by optic flow with the target, equating the time to closure of the target-heading angle with the time to passage of the target (tau equalization, B. Fajen, 2001), or using the target egocentric direction and steering to center the target in the straight ahead or cancel the target optical drift (S. K. Rushton, J. M. Harris, M. Lloyd, & J. P. Wann, 1998). Supporting evidences for the use of these strategies in guiding steering or walking toward a goal were reported, but no consensus has been reached. In this study, by presenting participants with displays in which target egocentric direction was fixed and thus unavailable for steering to force participants to rely on information from optic flow for the control of self-motion, we systematically examined the use of the optic flow-based strategies in the visual control of steering toward a goal. We found that participants steered to align their heading with the target, supporting the use of the heading strategy. We found no evidence to support the use of the path or the tau-equalization strategy in the visual control of steering toward a goal.
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:18
Hierarchy of Motor Control
 01:19
Root-Locus Method
This system can be represented by a block diagram,...
 01:25
The Anchoring-and-Adjustment Heuristic
 01:17
Dynamics Of Circular Motion: Applications