Related Experiment Video
Updated: May 26, 2026

Design and Characterization Methodology for Efficient Wide Range Tunable MEMS Filters
Published on: February 4, 2018
QMRPF-UKF master-slave filtering for the attitude determination of micro-nano satellites using gyro and magnetometer
1School of Instrumentation Science and Optoelectronics Engineering, Beijing University of Aeronautics and Astronautics, Beijing 100191, China. peilingcui@buaa.edu.cn

Abstract:
In this paper, the problem of estimating the attitude of a micro-nano satellite, obtaining geomagnetic field measurements via a three-axis magnetometer and obtaining angle rate via gyro, is considered. For this application, a QMRPF-UKF master-slave filtering method is proposed, which uses the QMRPF and UKF algorithms to estimate the rotation quaternion and the gyro bias parameters, respectively. The computational complexicity related to the particle filtering technique is eliminated by introducing a multiresolution approach that permits a significant reduction in the number of particles. This renders QMRPF-UKF master-slave filter computationally efficient and enables its implementation with a remarkably small number of particles. Simulation results by using QMRPF-UKF are given, which demonstrate the validity of the QMRPF-UKF nonlinear filter.
More Related Videos

Related Concept Videos
 01:02
Gyroscope
 01:24
Gyroscope: Precession
 01:24
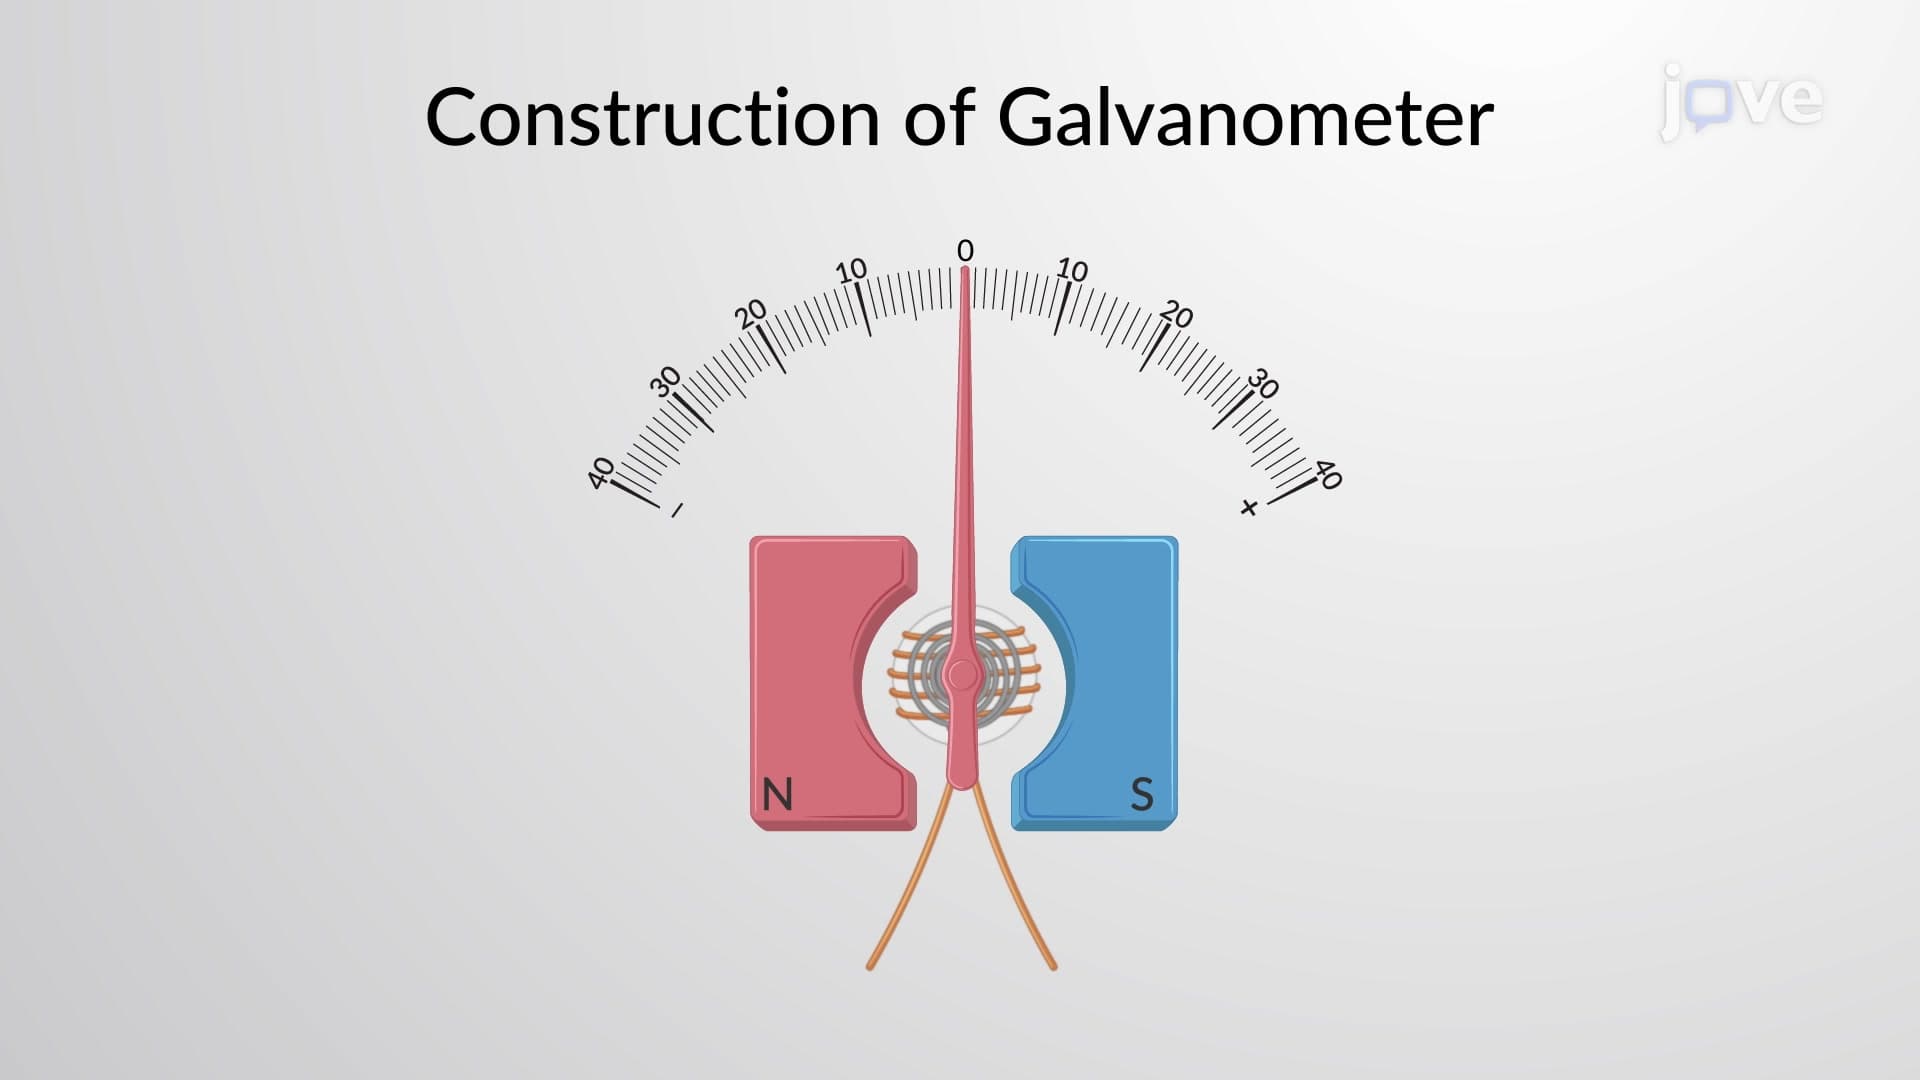
Galvanometer
The galvanometer consists of two concave-shaped permanent magnets, providing a uniform radial magnetic field in the annular region. In the center, a pivoted coil of fine copper wire is placed in the uniform magnetic...
 01:19
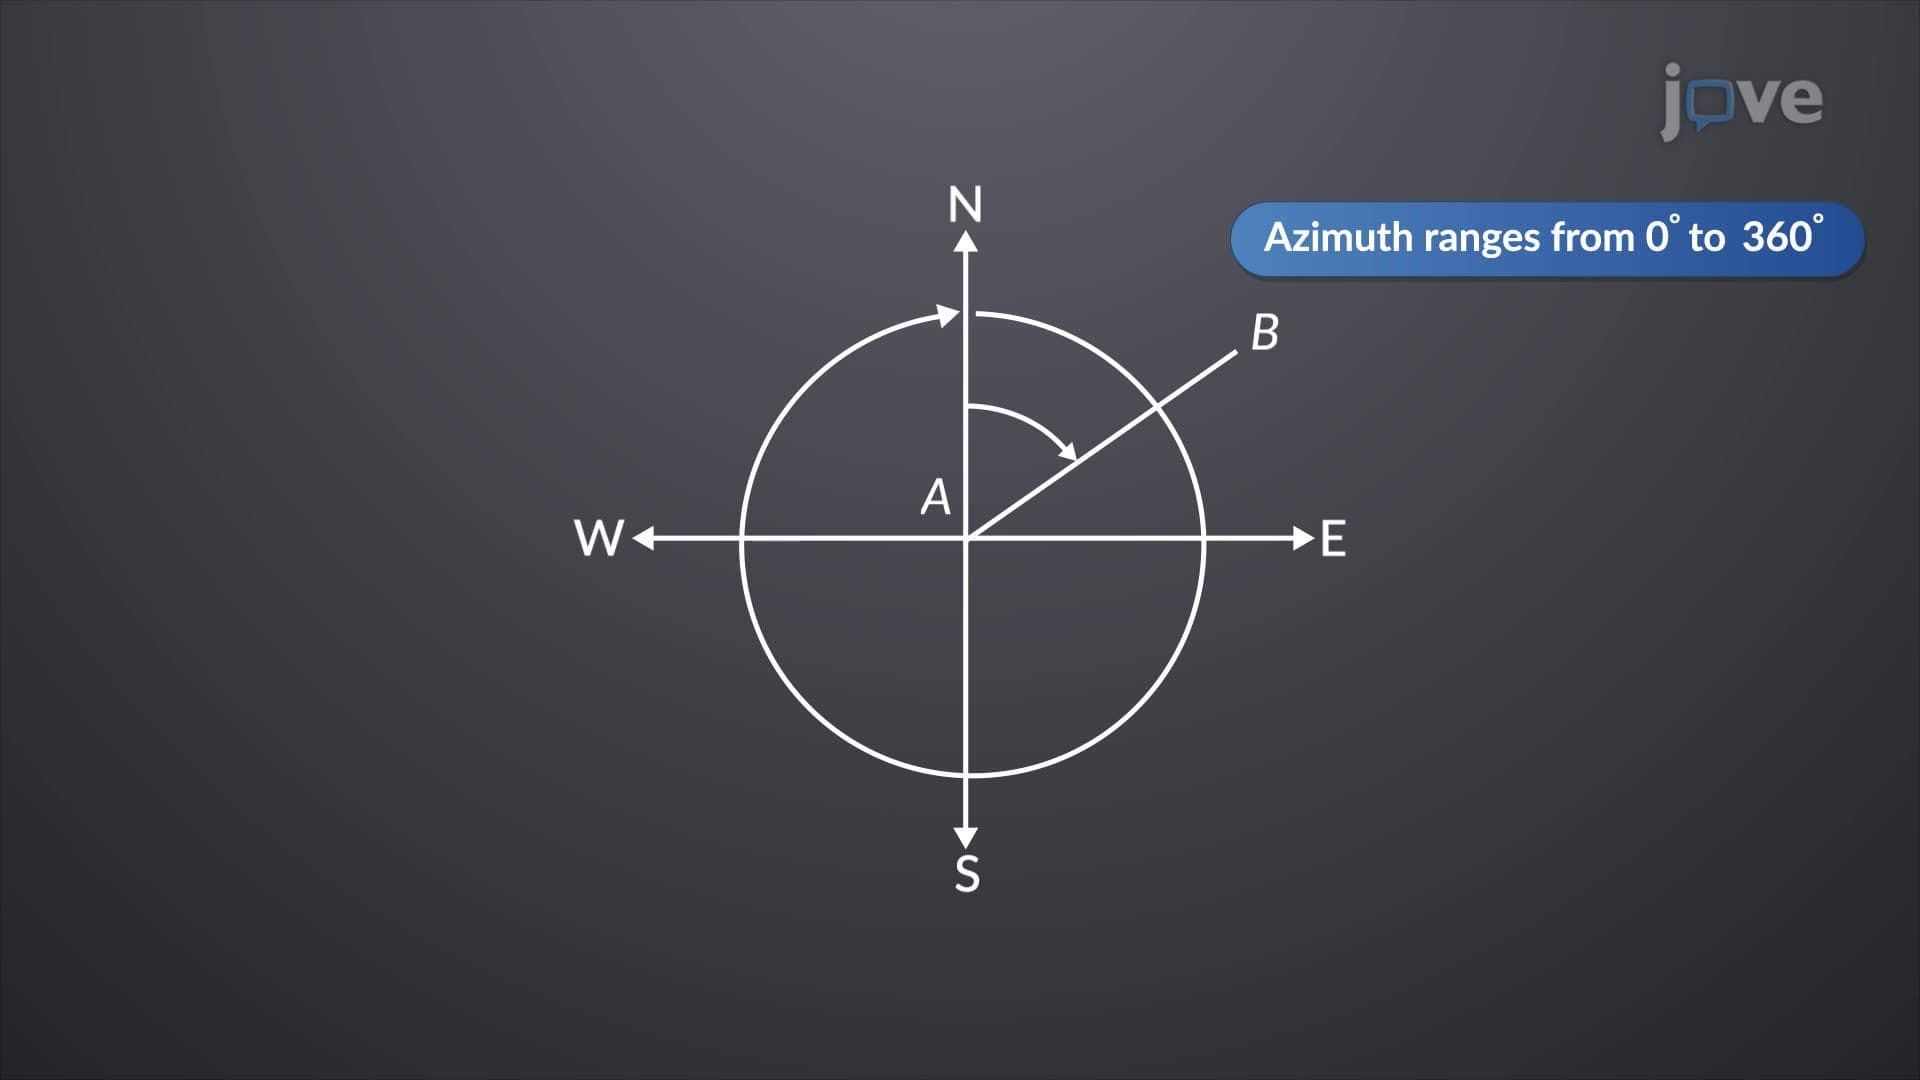
Azimuths and Bearings
 01:26
Errors in Global Positioning System
 01:30
Types of Global Positioning System Surveys