Related Experiment Video
Updated: May 26, 2026
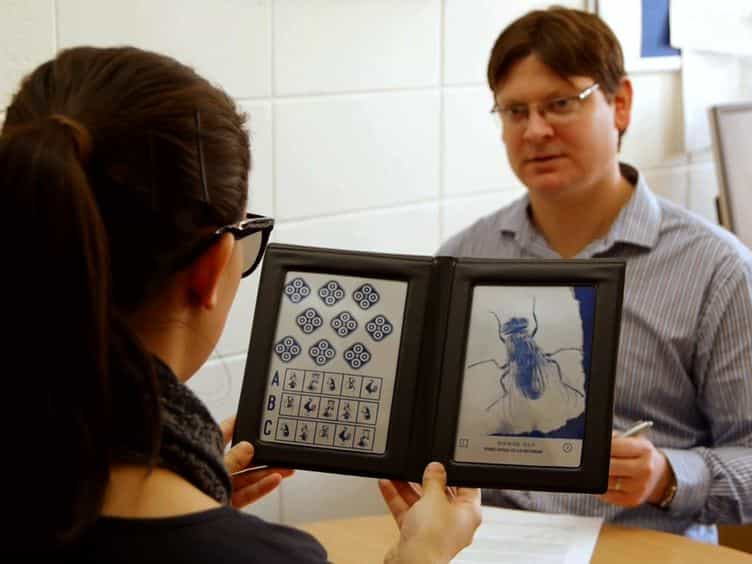

Measuring Sensitivity to Viewpoint Change with and without Stereoscopic Cues
Published on: December 4, 2013
Representation of 3-D surface orientation by velocity and disparity gradient cues in area MT
Takahisa M Sanada1, Jerry D Nguyenkim, Gregory C Deangelis
1Dept. of Brain and Cognitive Sciences, Center for Visual Science, Univ. of Rochester, Rochester, NY 14627, USA.

Abstract:
Neural coding of the three-dimensional (3-D) orientation of planar surface patches may be an important intermediate step in constructing representations of complex 3-D surface structure. Spatial gradients of binocular disparity, image velocity, and texture provide potent cues to the 3-D orientation (tilt and slant) of planar surfaces. Previous studies have described neurons in both dorsal and ventral stream areas that are selective for surface tilt based on one or more of these gradient cues. However, relatively little is known about whether single neurons provide consistent information about surface orientation from multiple gradient cues. Moreover, it is unclear how neural responses to combinations of surface orientation cues are related to responses to the individual cues. We measured responses of middle temporal (MT) neurons to random dot stimuli that simulated planar surfaces at a variety of tilts and slants. Four cue conditions were tested: disparity, velocity, and texture gradients alone, as well as all three gradient cues combined. Many neurons showed robust tuning for surface tilt based on disparity and velocity gradients, with relatively little selectivity for texture gradients. Some neurons showed consistent tilt preferences for disparity and velocity cues, whereas others showed large discrepancies. Responses to the combined stimulus were generally well described as a weighted linear sum of responses to the individual cues, even when disparity and velocity preferences were discrepant. These findings suggest that area MT contains a rudimentary representation of 3-D surface orientation based on multiple cues, with single neurons implementing a simple cue integration rule.
More Related Videos

Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:25
Methods of Obtaining Topography
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:34
Velocity and Position by Graphical Method
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...