Related Experiment Videos
A blur-robust descriptor with applications to face recognition
Raghuraman Gopalan1, Sima Taheri, Pavan Turaga
1Video and Multimedia Department, AT&T Labs-Research, Middletown, NJ 07748, USA. raghuram@research.att.com

Abstract:
Understanding the effect of blur is an important problem in unconstrained visual analysis. We address this problem in the context of image-based recognition by a fusion of image-formation models and differential geometric tools. First, we discuss the space spanned by blurred versions of an image and then, under certain assumptions, provide a differential geometric analysis of that space. More specifically, we create a subspace resulting from convolution of an image with a complete set of orthonormal basis functions of a prespecified maximum size (that can represent an arbitrary blur kernel within that size), and show that the corresponding subspaces created from a clean image and its blurred versions are equal under the ideal case of zero noise and some assumptions on the properties of blur kernels. We then study the practical utility of this subspace representation for the problem of direct recognition of blurred faces by viewing the subspaces as points on the Grassmann manifold and present methods to perform recognition for cases where the blur is both homogenous and spatially varying. We empirically analyze the effect of noise, as well as the presence of other facial variations between the gallery and probe images, and provide comparisons with existing approaches on standard data sets.
Related Concept Videos
 01:21
Association Areas of the Cortex
Prefrontal Association Area: This area is located in the frontal lobe and is involved in planning, decision-making, and moderating social behavior. It connects with primary motor areas,...
 01:03
IR Frequency Region: Fingerprint Region
The...
 01:20
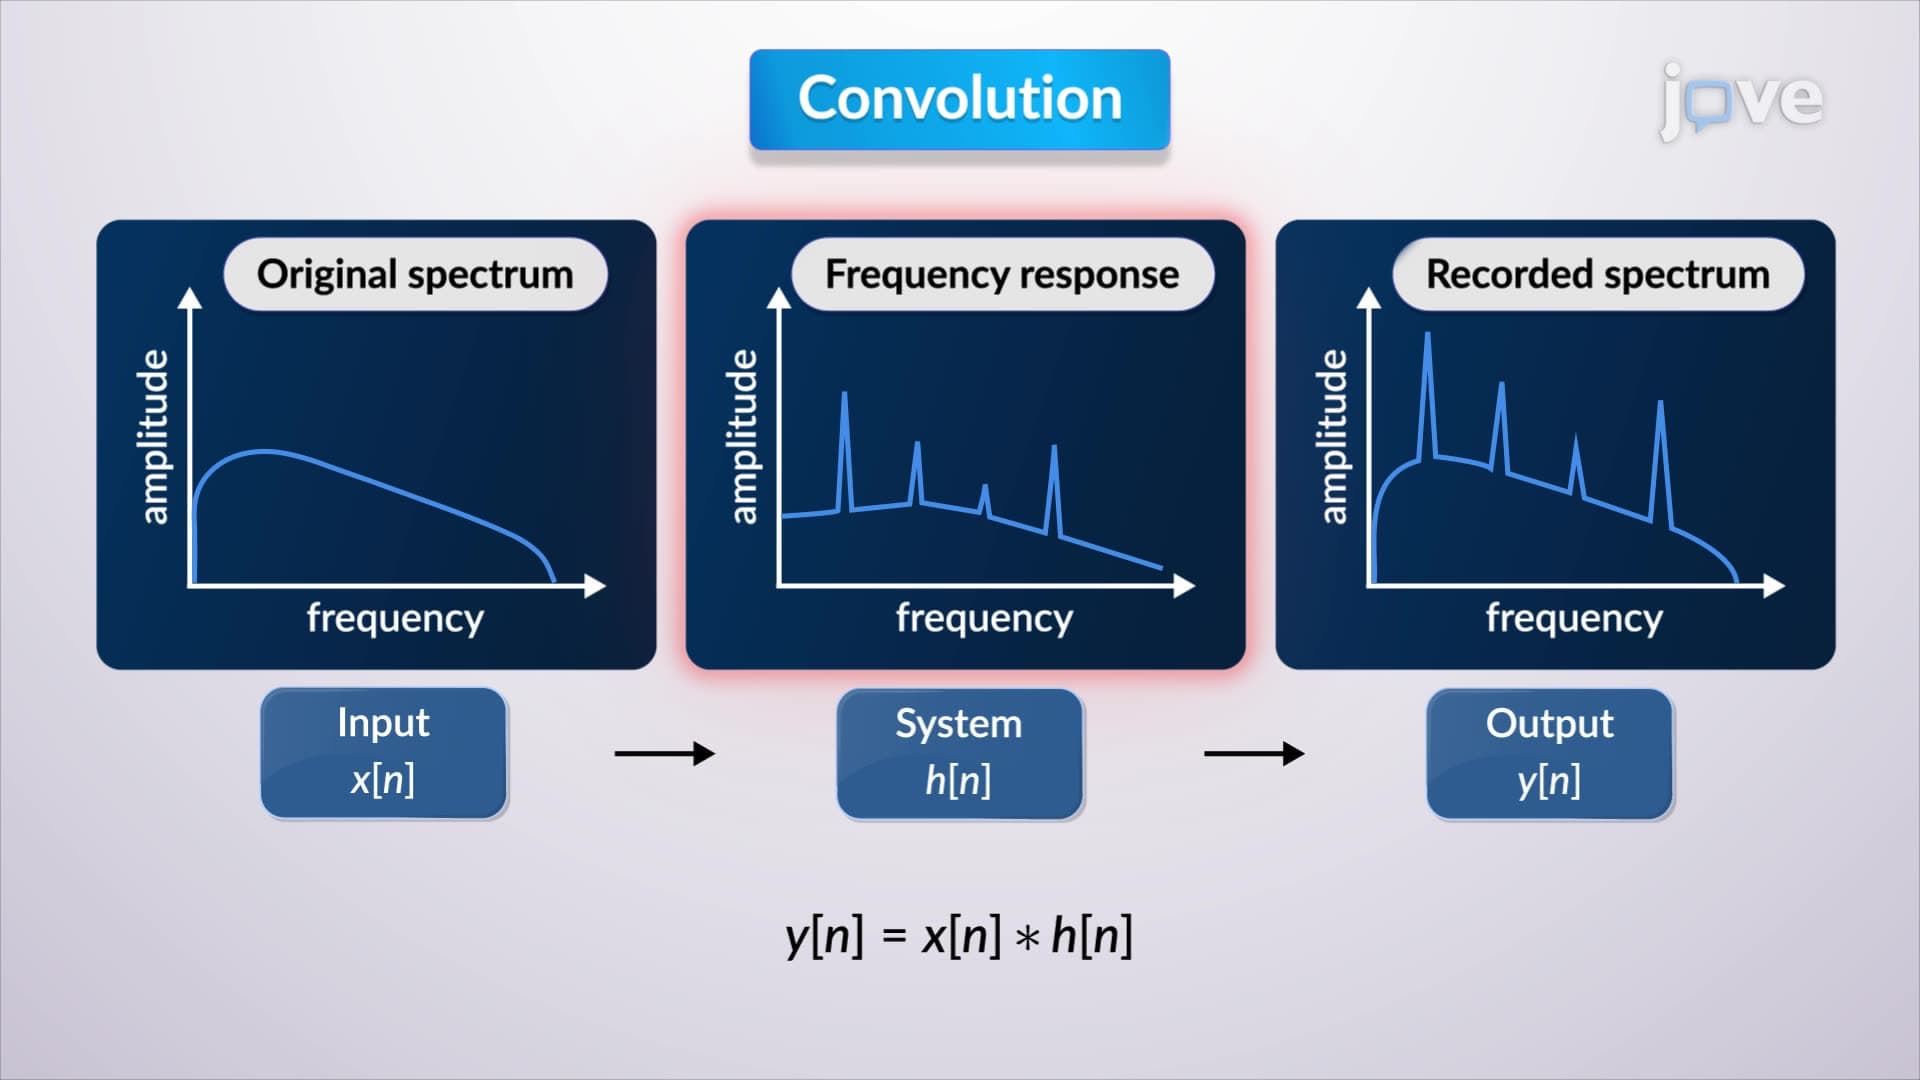
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:29
Application of Linearization and Approximation