A unified strategy for landing and docking using spherical flow divergence
Related Experiment Video
Updated: May 25, 2026
Impacts of Free-falling Spheres on a Deep Liquid Pool with Altered Fluid and Impactor Surface Conditions
Published on: February 17, 2019
1NICTA Canberra Research Laboratory and College of Engineering and Computer Science, Australian National University, Tower A, 7 London Circuit, Canberra, ACT 2601, Australia. chris.mccarthy@nicta.com.au

Abstract:
We present a new visual control input from optical flow divergence enabling the design of novel, unified control laws for docking and landing. While divergence-based time-to-contact estimation is well understood, the use of divergence in visual control currently assumes knowledge of surface orientation, and/or egomotion. There exists no directly observable visual cue capable of supporting approaches to surfaces of arbitrary orientation under general motion. Central to our measure is the use of the maximum flow field divergence on the view sphere (max-div). We prove kinematic properties governing the location of max-div, and show that max-div provides a temporal measure of proximity. From this, we contribute novel control laws for regulating both approach velocity and angle of approach toward planar surfaces of arbitrary orientation, without structure-from-motion recovery. The strategy is tested in simulation, over real image sequences and in closed-loop control of docking/landing maneuvers on a mobile platform.
Related Concept Videos
 01:11
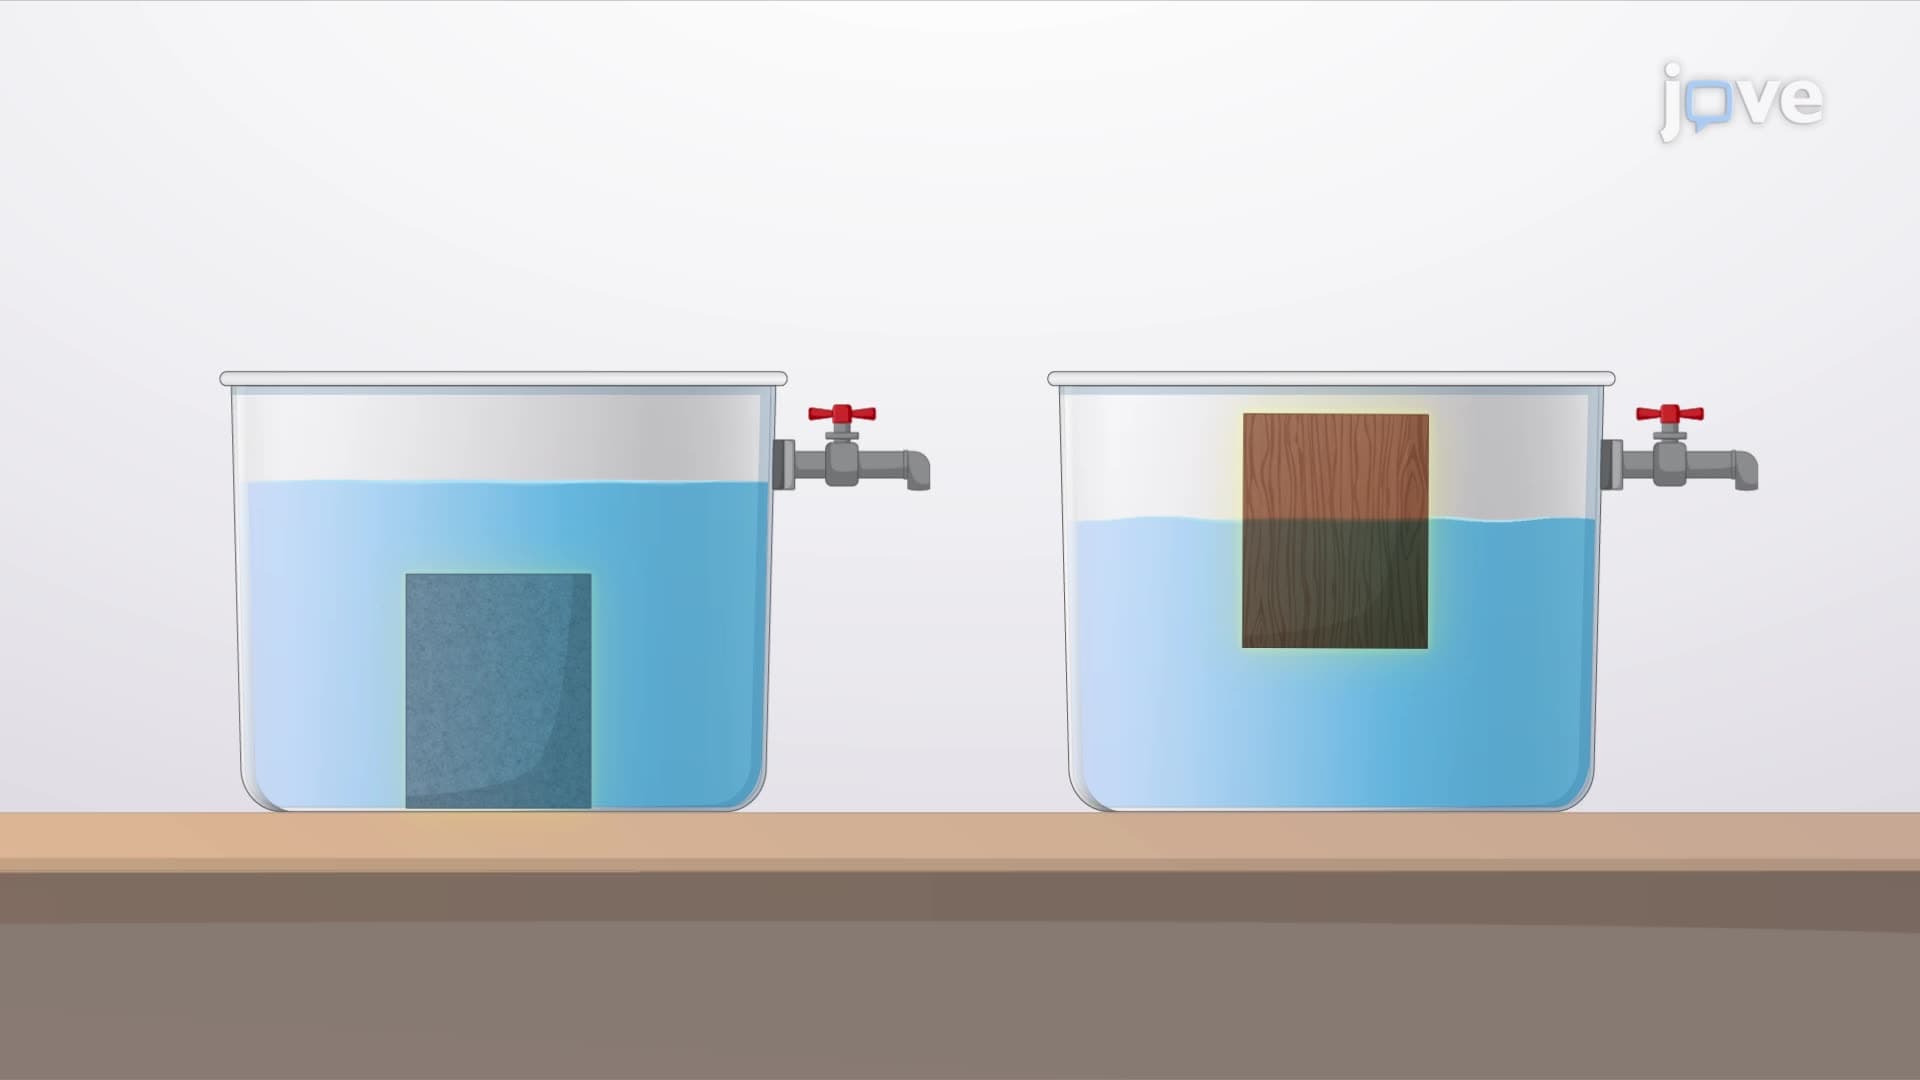
Buoyancy and Stability for Submerged and Floating Bodies
 01:22
Eulerian and Lagrangian Flow Descriptions
The Eulerian method focuses on fixed points in space where fluid properties, such as velocity, pressure, and temperature, are observed as the fluid moves between these...
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:18
Newtonian Fluid: Problem Solving
A velocity gradient forms within the fluid when a Newtonian fluid is placed between two parallel plates, with...
 01:24
Laminar Flow: Problem Solving
 01:23
Steady, Laminar Flow in Circular Tubes