Controlling a virtual forehand prosthesis using an adaptive and affective Human-Machine Interface
Related Experiment Video
Updated: May 25, 2026
Characterization of the Sense of Agency over the Actions of Neural-machine Interface-operated Prostheses
Published on: January 7, 2019
I Mohammad Rezazadeh1, S M P Firoozabadi, S M R Hashemi Golpayegani
1School of Biomedical Eng, Science and Research Branch, Islamic Azad University, Tehran, Iran. i.rezazadeh@srbiau.ac.ir

Abstract:
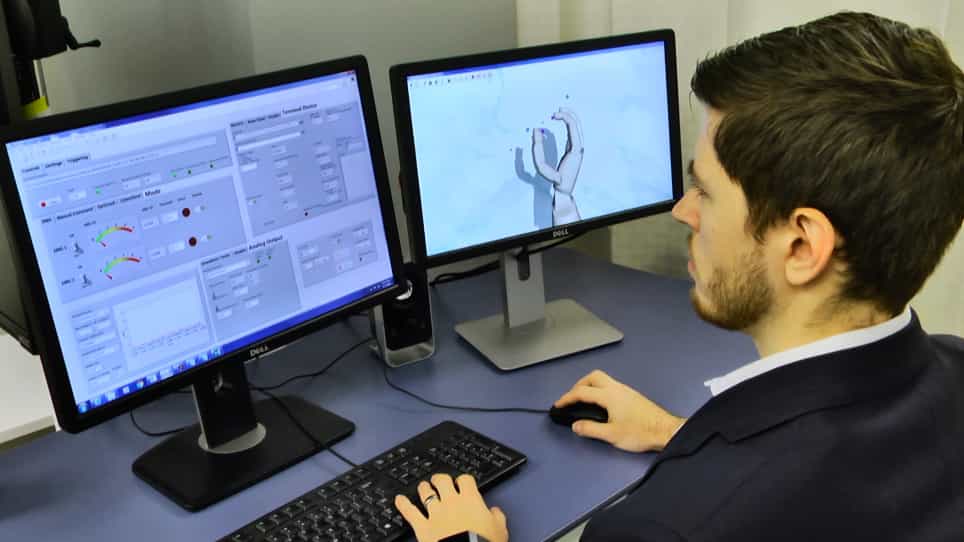
This paper presents the design of an adaptable Human-Machine Interface (HMI) for controlling virtual forearm prosthesis. Direct physical performance measures (obtained score and completion time) for the requested tasks were calculated. Furthermore, bioelectric signals from the forehead were recorded using one pair of electrodes placed on the frontal region of the subject head to extract the mental (affective) measures while performing the tasks. By employing the proposed algorithm and above measures, the proposed HMI can adapt itself to the subject's mental states, thus improving the usability of the interface. The quantitative results from 15 subjects show that the proposed HMI achieved better physical performance measures in comparison to a conventional non-adaptive myoelectric controller (p < 0.001).