Subspace learning from image gradient orientations
Related Experiment Video
Updated: May 25, 2026

Image Recognition and Parameter Analysis of Concrete Vibration State Based on Support Vector Machine
Published on: January 5, 2024
Georgios Tzimiropoulos1, Stefanos Zafeiriou, Maja Pantic
1School of Computer Science, University of Lincoln, Brayford Pool, Lincoln LN6 7TS, United Kingdom, and also with the Department of Computing, Imperial College Longdon, London SW7 2AZ, United Kingdom. gtzimiropoulos@lincoln.ac.uk

Abstract:
We introduce the notion of subspace learning from image gradient orientations for appearance-based object recognition. As image data are typically noisy and noise is substantially different from Gaussian, traditional subspace learning from pixel intensities very often fails to estimate reliably the low-dimensional subspace of a given data population. We show that replacing pixel intensities with gradient orientations and the ℓ₂ norm with a cosine-based distance measure offers, to some extend, a remedy to this problem. Within this framework, which we coin Image Gradient Orientations (IGO) subspace learning, we first formulate and study the properties of Principal Component Analysis of image gradient orientations (IGO-PCA). We then show its connection to previously proposed robust PCA techniques both theoretically and experimentally. Finally, we derive a number of other popular subspace learning techniques, namely, Linear Discriminant Analysis (LDA), Locally Linear Embedding (LLE), and Laplacian Eigenmaps (LE). Experimental results show that our algorithms significantly outperform popular methods such as Gabor features and Local Binary Patterns and achieve state-of-the-art performance for difficult problems such as illumination and occlusion-robust face recognition. In addition to this, the proposed IGO-methods require the eigendecomposition of simple covariance matrices and are as computationally efficient as their corresponding ℓ₂ norm intensity-based counterparts. Matlab code for the methods presented in this paper can be found at http://ibug.doc.ic.ac.uk/resources.

Related Concept Videos
 01:14
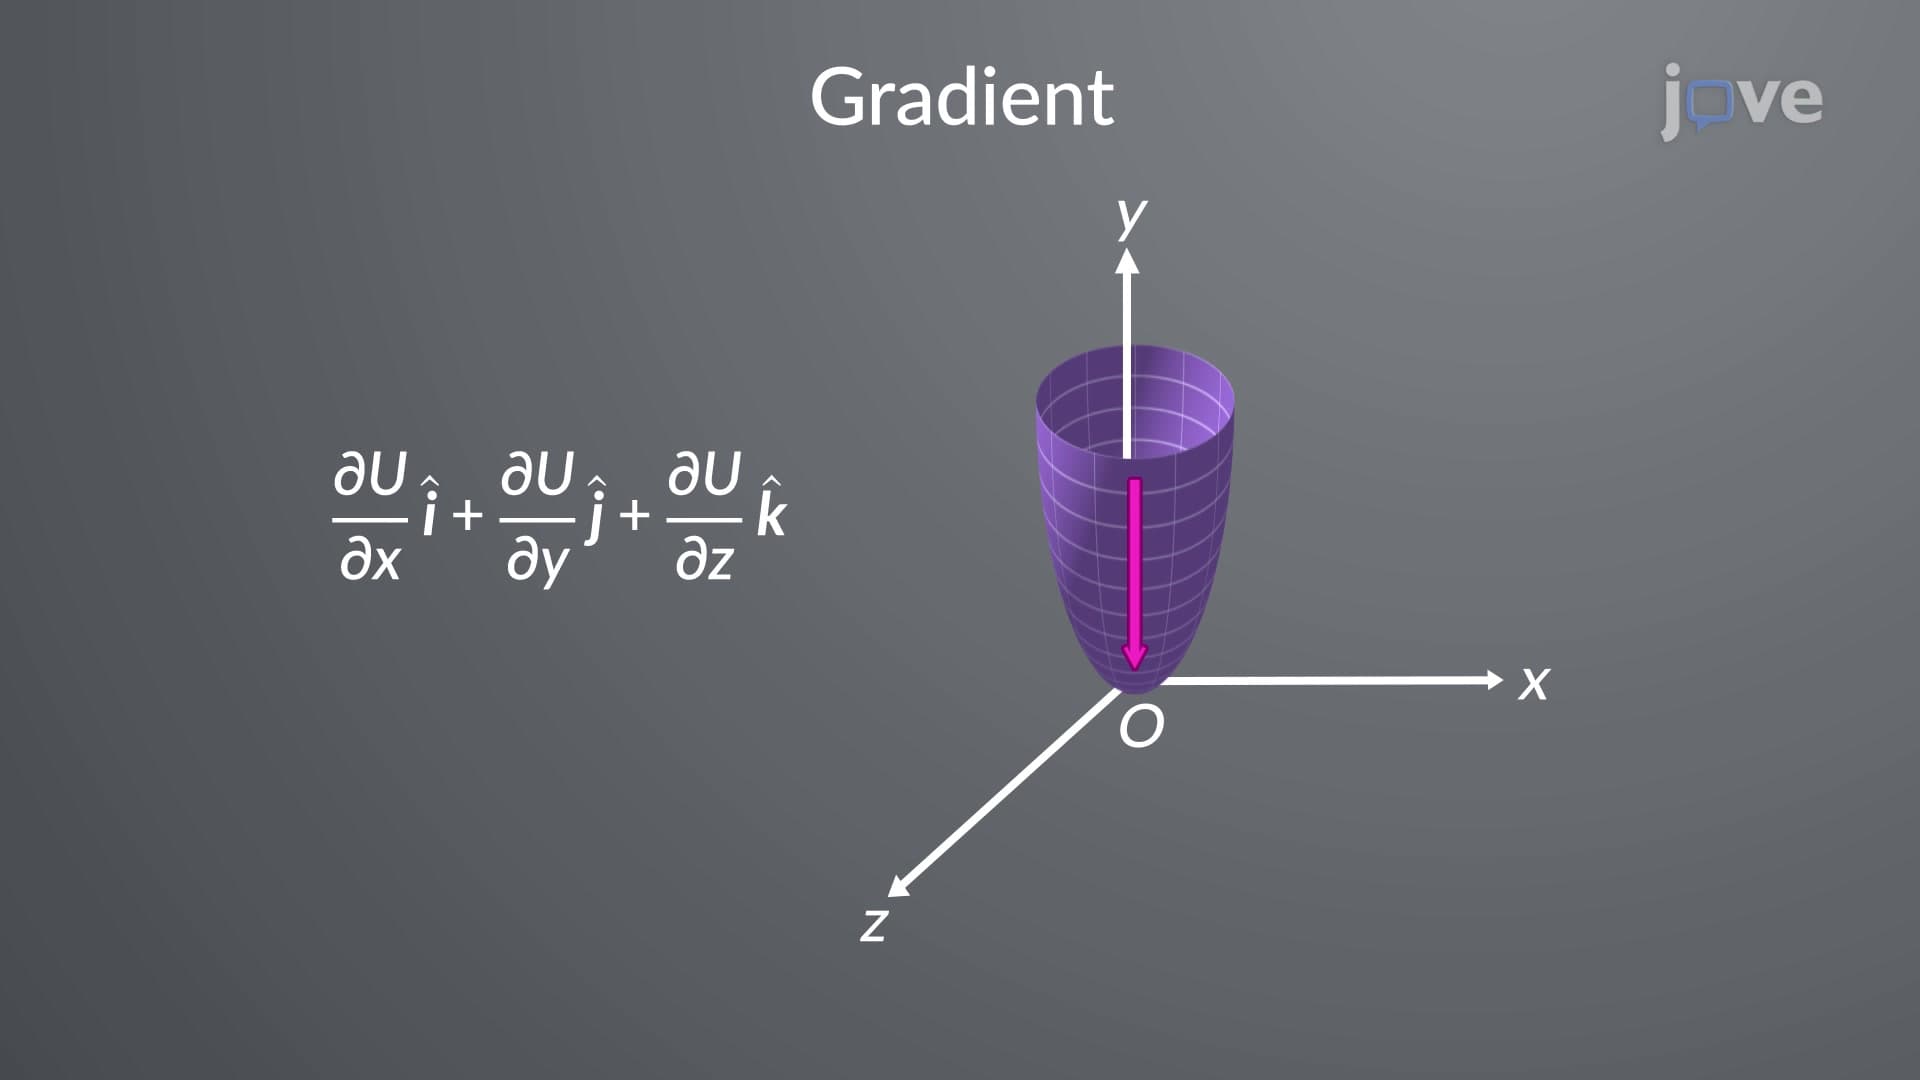
Gradient and Del Operator
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:15
Depth Perception and Spatial Vision
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:00
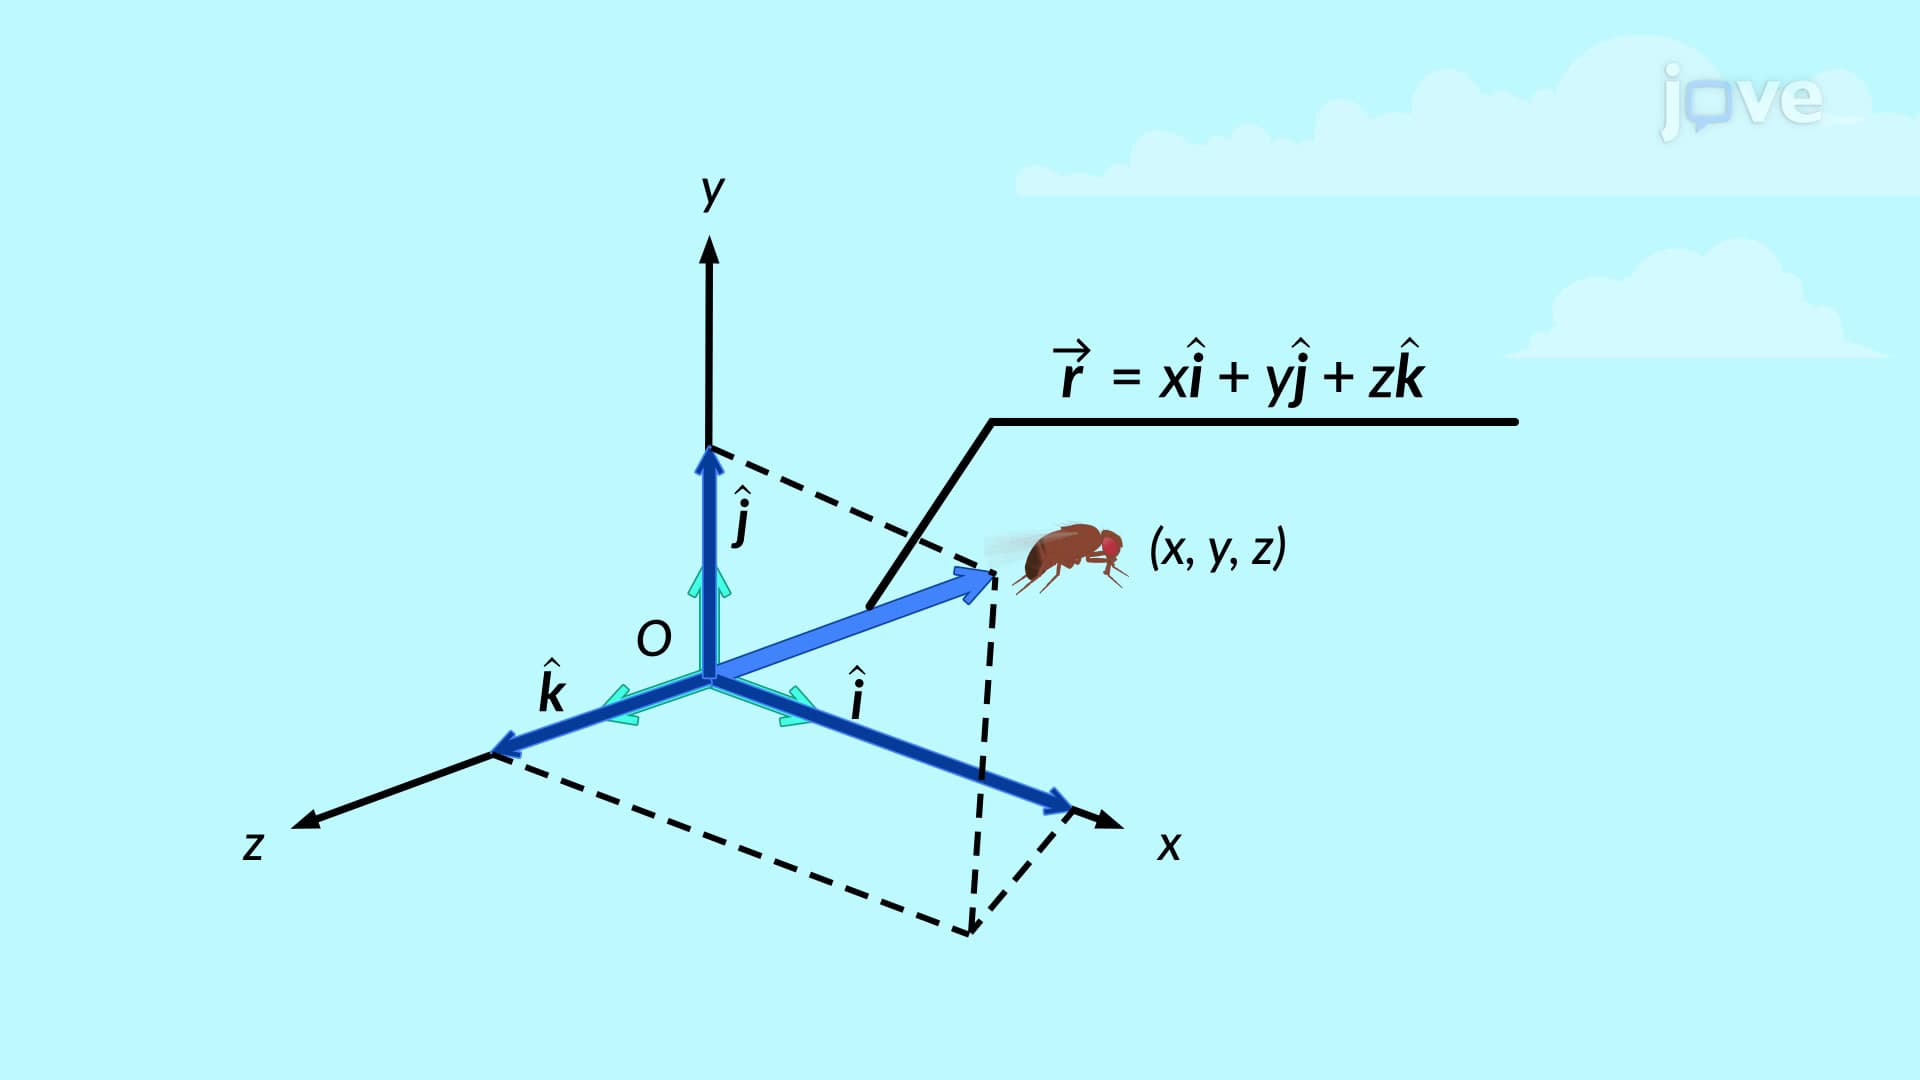
Position and Displacement Vectors
Further, several important kinds of...