Related Experiment Video
Updated: May 25, 2026
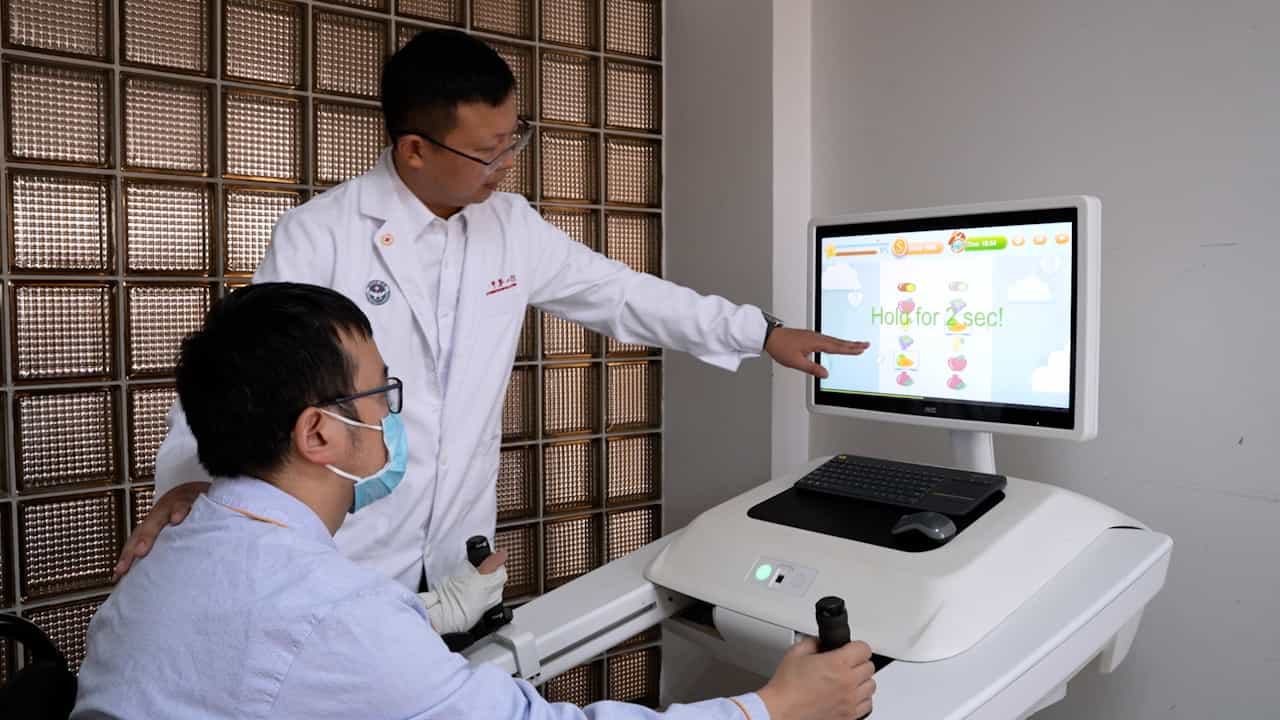
Enhancing Upper Limb Function and Motor Skills Post-Stroke Through an Upper Limb Rehabilitation Robot
Published on: September 6, 2024
A decision-theoretic approach in the design of an adaptive upper-limb stroke rehabilitation robot
Rajibul Huq1, Patricia Kan, Robby Goetschalckx
1Institute of Biomaterials and Biomedical Engineering, University of Toronto, Toronto, Canada. rajibul.huq@utoronto.ca

Abstract:
This paper presents an automated system for a rehabilitation robotic device that guides stroke patients through an upper-limb reaching task. The system uses a partially observable Markov decision process (POMDP) as its primary engine for decision-making. The POMDP allows the system to automatically modify exercise parameters to account for the specific needs and abilities of different individuals, and to use these parameters to take appropriate decisions about stroke rehabilitation exercises. The performance of the system was evaluated through various simulations and by comparing the decisions made by the system with those of a human therapist for a single patient. In general, the simulations showed promising results and the therapist thought the system decisions were believable.