Related Experiment Video
Updated: May 25, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Design of a robotic device for assessment and rehabilitation of hand sensory function
Olivier Lambercy1, Alejandro Juárez Robles, Yeongmi Kim
1Rehabilitation Engineering Lab, ETH Zurich, Switzerland. olambercy@ethz.ch

Abstract:
This paper presents the design and implementation of the Robotic Sensory Trainer, a robotic interface for assessment and therapy of hand sensory function. The device can provide three types of well controlled stimuli: (i) angular displacement at the metacarpophalangeal (MCP) joint using a remote-center-of-motion double-parallelogram structure, (ii) vibration stimuli at the fingertip, proximal phalange and palm, and (iii) pressure at the fingertip, while recording position, interaction force and feedback from the user over a touch screen. These stimuli offer a novel platform to investigate sensory perception in healthy subjects and patients with sensory impairments, with the potential to assess deficits and actively train detection of specific sensory cues in a standardized manner. A preliminary study with eight healthy subjects demonstrates the feasibility of using the Robotic Sensory Trainer to assess the sensory perception threshold in MCP angular position. An average just noticeable difference (JND) in the MCP joint angle of 2.46° (14.47%) was found, which is in agreement with previous perception studies.
More Related Videos
 07:34
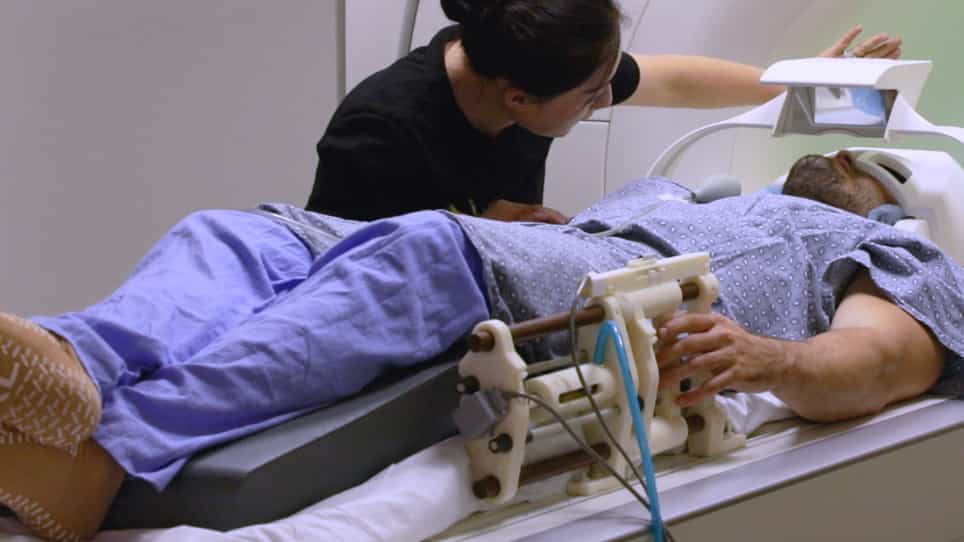
Functional MRI in Conjunction with a Novel MRI-compatible Hand-induced Robotic Device to Evaluate Rehabilitation of Individuals Recovering from Hand Grip Deficits
Published on: November 23, 2019
 13:44
Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011