Related Experiment Video
Updated: May 25, 2026
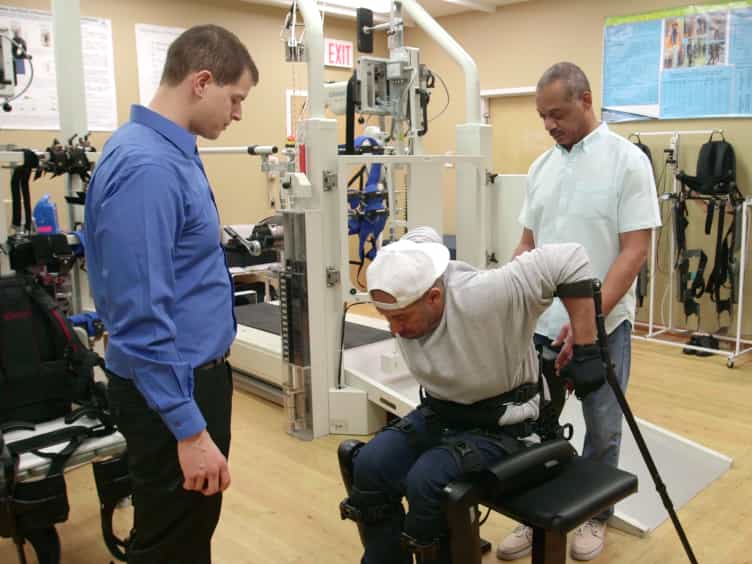

Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Control and implementation of a powered lower limb orthosis to aid walking in paraplegic individuals
Hugo A Quintero1, Ryan J Farris, Michael Goldfarb
1Vanderbilt University, Nashville, TN 37235, USA. hugo.a.quintero@vanderbilt.edu

Abstract:
This paper describes a powered lower-limb orthosis that is intended to provide gait assistance to spinal cord injured (SCI) individuals by providing assistive torques at both hip and knee joints, along with a user interface and control structure that enables control of the powered orthosis via upper-body influence. The orthosis and control structure was experimentally implemented on a paraplegic subject (T10 complete) in order to provide a preliminary characterization of its capability to provide basic walking. Data and video is presented from these initial trials, which indicates that the orthosis and controller are able to effectively provide walking within parallel bars at an average speed of 0.8 km/hr.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 05:25
An Experiment Using Functional Near-Infrared Spectroscopy and Robot-Assisted Multi-Joint Pointing Movements of the Lower Limb
Published on: June 7, 2024