Related Experiment Video
Updated: May 25, 2026
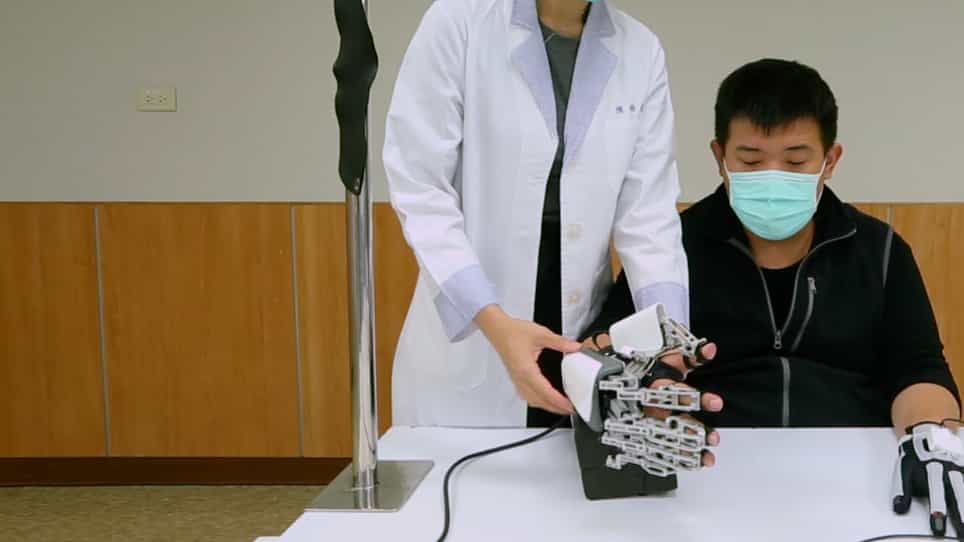
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Shoulder mechanism design of an exoskeleton robot for stroke patient rehabilitation
Donghan Koo1, Pyung Hun Chang, Min Kyun Sohn
1Department of Mechanical Engineering, KAIST, Daejeon, Korea. mechsin@kaist.ac.kr

Abstract:
Shoulder girdle movement is critical for stabilizing and orientating the arm during daily activities. During robotic arm rehabilitation with stroke patients, the robot must assist movements of the shoulder girdle. Shoulder girdle movement is characterized by a highly nonlinear function of the humeral orientation, which is different for each person. Hence it is improper to use pre-calculated shoulder girdle movement. If an exoskeleton robot cannot mimic the patient's shoulder girdle movement well, the robot axes will not coincide with the patient's, which brings reduced range of motion (ROM) and discomfort to the patients. A number of exoskeleton robots have been developed to assist shoulder girdle movement. The shoulder mechanism of these robots, along with the advantages and disadvantages, are introduced. In this paper, a novel shoulder mechanism design of exoskeleton robot is proposed, which can fully mimic the patient's shoulder girdle movement in real time.

