Related Experiment Video
Updated: May 25, 2026
Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
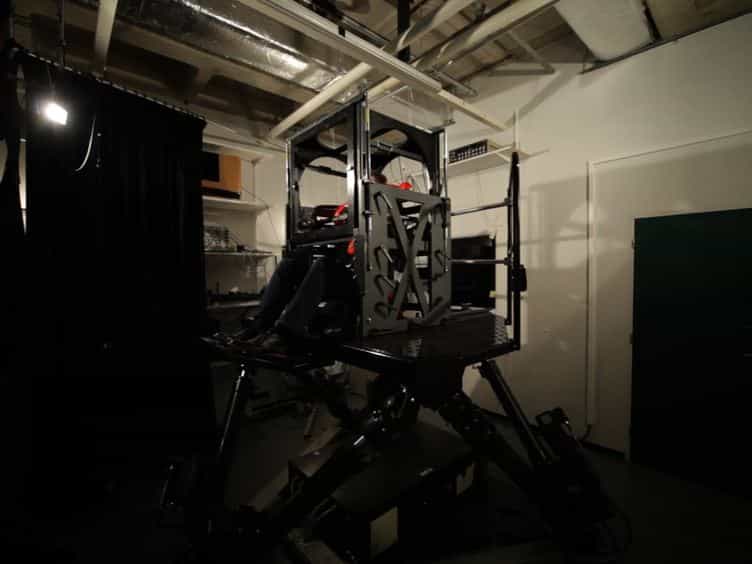
Development of a low-cost attitude and heading reference system using a three-axis rotating platform
Ying-Chih Lai1, Shau-Shiun Jan, Fei-Bin Hsiao
1Institute of Aeronautics and Astronautics, National Cheng Kung University, Tainan, 701, Taiwan. p4893126@ccmail.ncku.edu.tw

Abstract:
A development procedure for a low-cost attitude and heading reference system (AHRS) with a self-developed three-axis rotating platform has been proposed. The AHRS consists of one 3-axis accelerometer, three single-axis gyroscopes, and one 3-axis digital compass. Both the accelerometer and gyroscope triads are based on micro electro-mechanical system (MEMS) technology, and the digital compass is based on anisotropic-magnetoresistive (AMR) technology. The calibrations for each sensor triad are readily accomplished by using the scalar calibration and the least squares methods. The platform is suitable for the calibration and validation of the low-cost AHRS and it is affordable for most laboratories. With the calibrated parameters and data fusion algorithm for the orientation estimation, the self-developed AHRS demonstrates the capabilities of compensating for the sensor errors and outputting the estimated orientation in real-time. The validation results show that the estimated orientations of the developed AHRS are within the acceptable region. This verifies the practicability of the proposed development procedure.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:26
Rotational Motion about a Fixed Axis
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
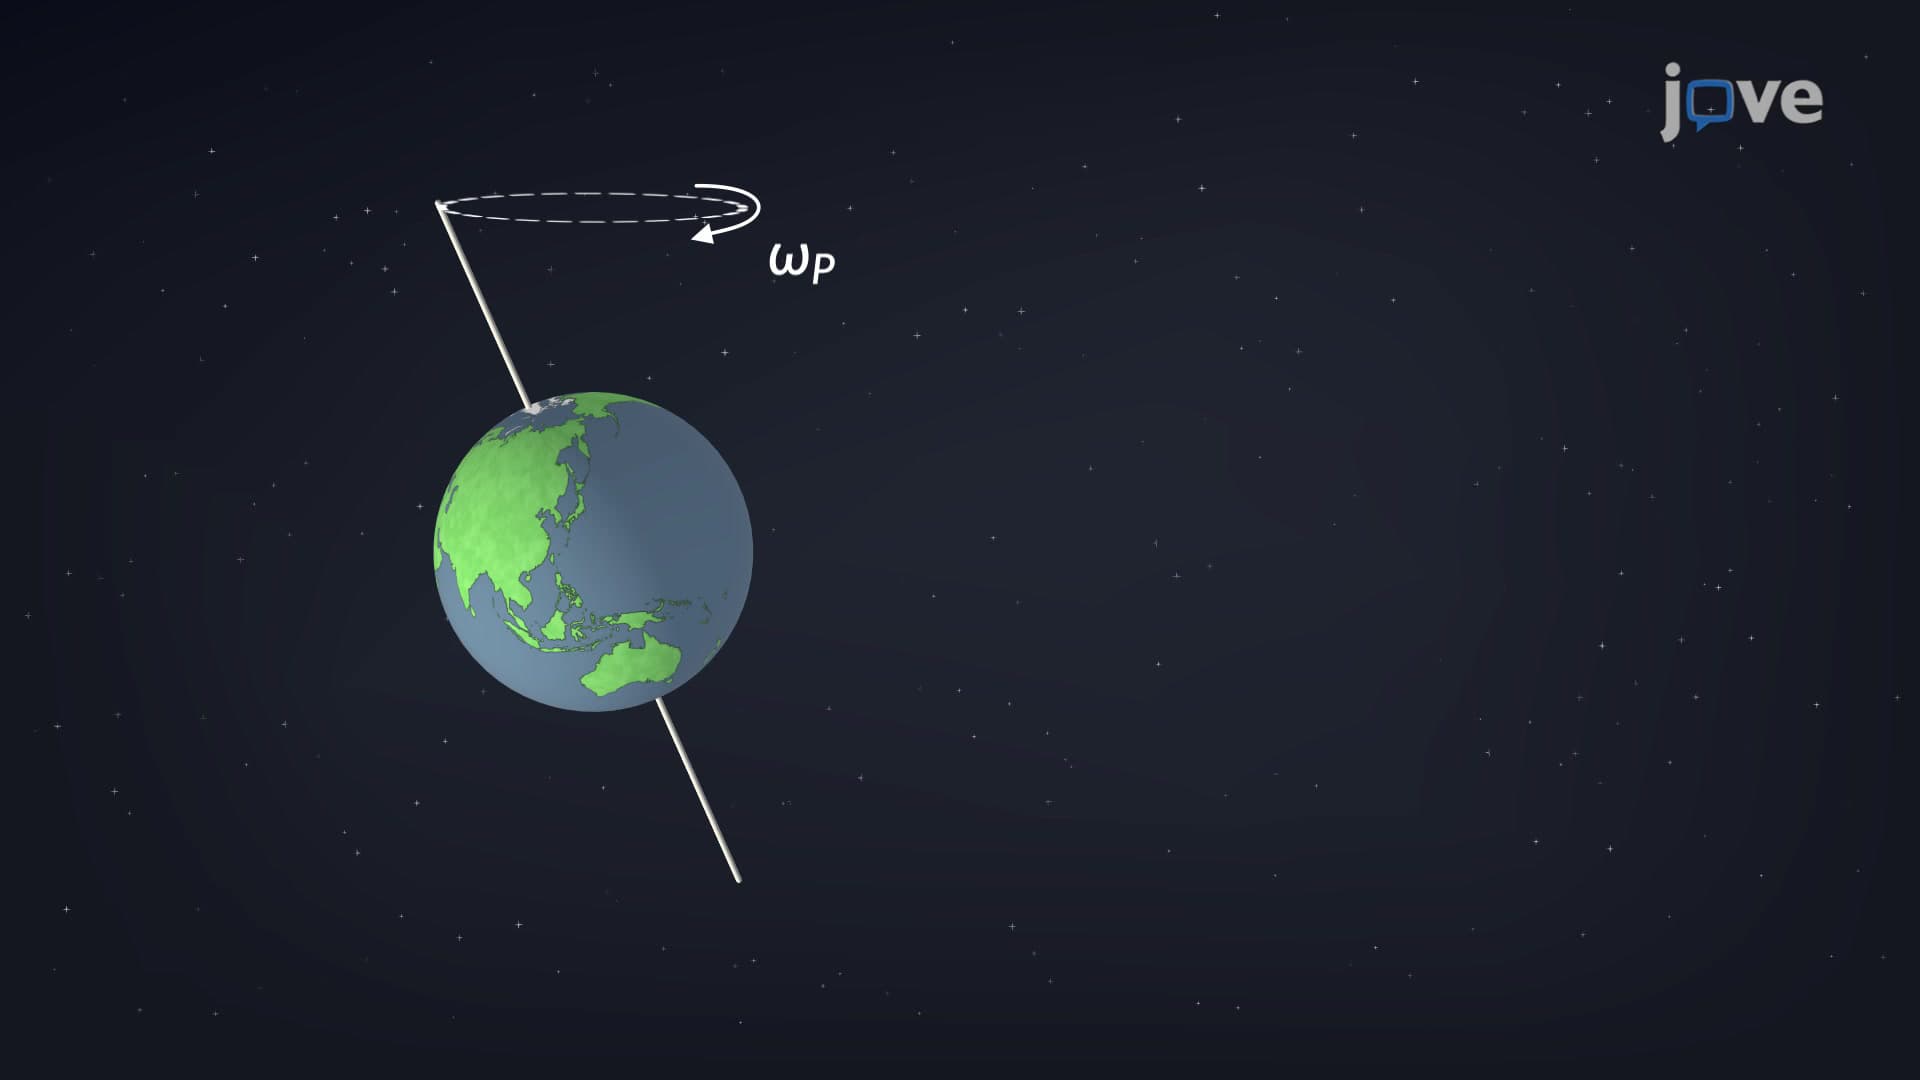
Gyroscope: Precession
 01:02
Gyroscope