Related Experiment Video
Updated: May 24, 2026


Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Energy management that generates terrain following versus apex-preserving hopping in man and machine
Karl Theodor Kalveram1, Daniel F B Haeufle, André Seyfarth
1Cybernetical Psychology, University of Düsseldorf, Universitätsstr. 1, 40225 Düsseldorf, Germany. kalveram@uni-duesseldorf.de

Abstract:
While hopping, 12 subjects experienced a sudden step down of 5 or 10 cm. Results revealed that the hopping style was "terrain following". It means that the subjects pursued to keep the distance between maximum hopping height (apex) and ground profile constant. The spring-loaded inverse pendulum (SLIP) model, however, which is currently considered as template for stable legged locomotion would predict apex-preserving hopping, by which the absolute maximal hopping height is kept constant regardless of changes of the ground level. To get more insight into the physics of hopping, we outlined two concepts of energy management: "constant energy supply", by which in each bounce--regardless of perturbations--the same amount of mechanical energy is injected, and "lost energy supply", by which the mechanical energy that is going to be dissipated in the current cycle is assessed and replenished. When tested by simulations and on a robot testbed capable of hopping, constant energy supply generated stable and robust terrain following hopping, whereas lost energy supply led to something like apex-preserving hopping, which, however, lacks stability as well as robustness. Comparing simulated and machine hopping with human hopping suggests that constant energy supply has a good chance to be used by humans to generate hopping.
Related Concept Videos
 01:14
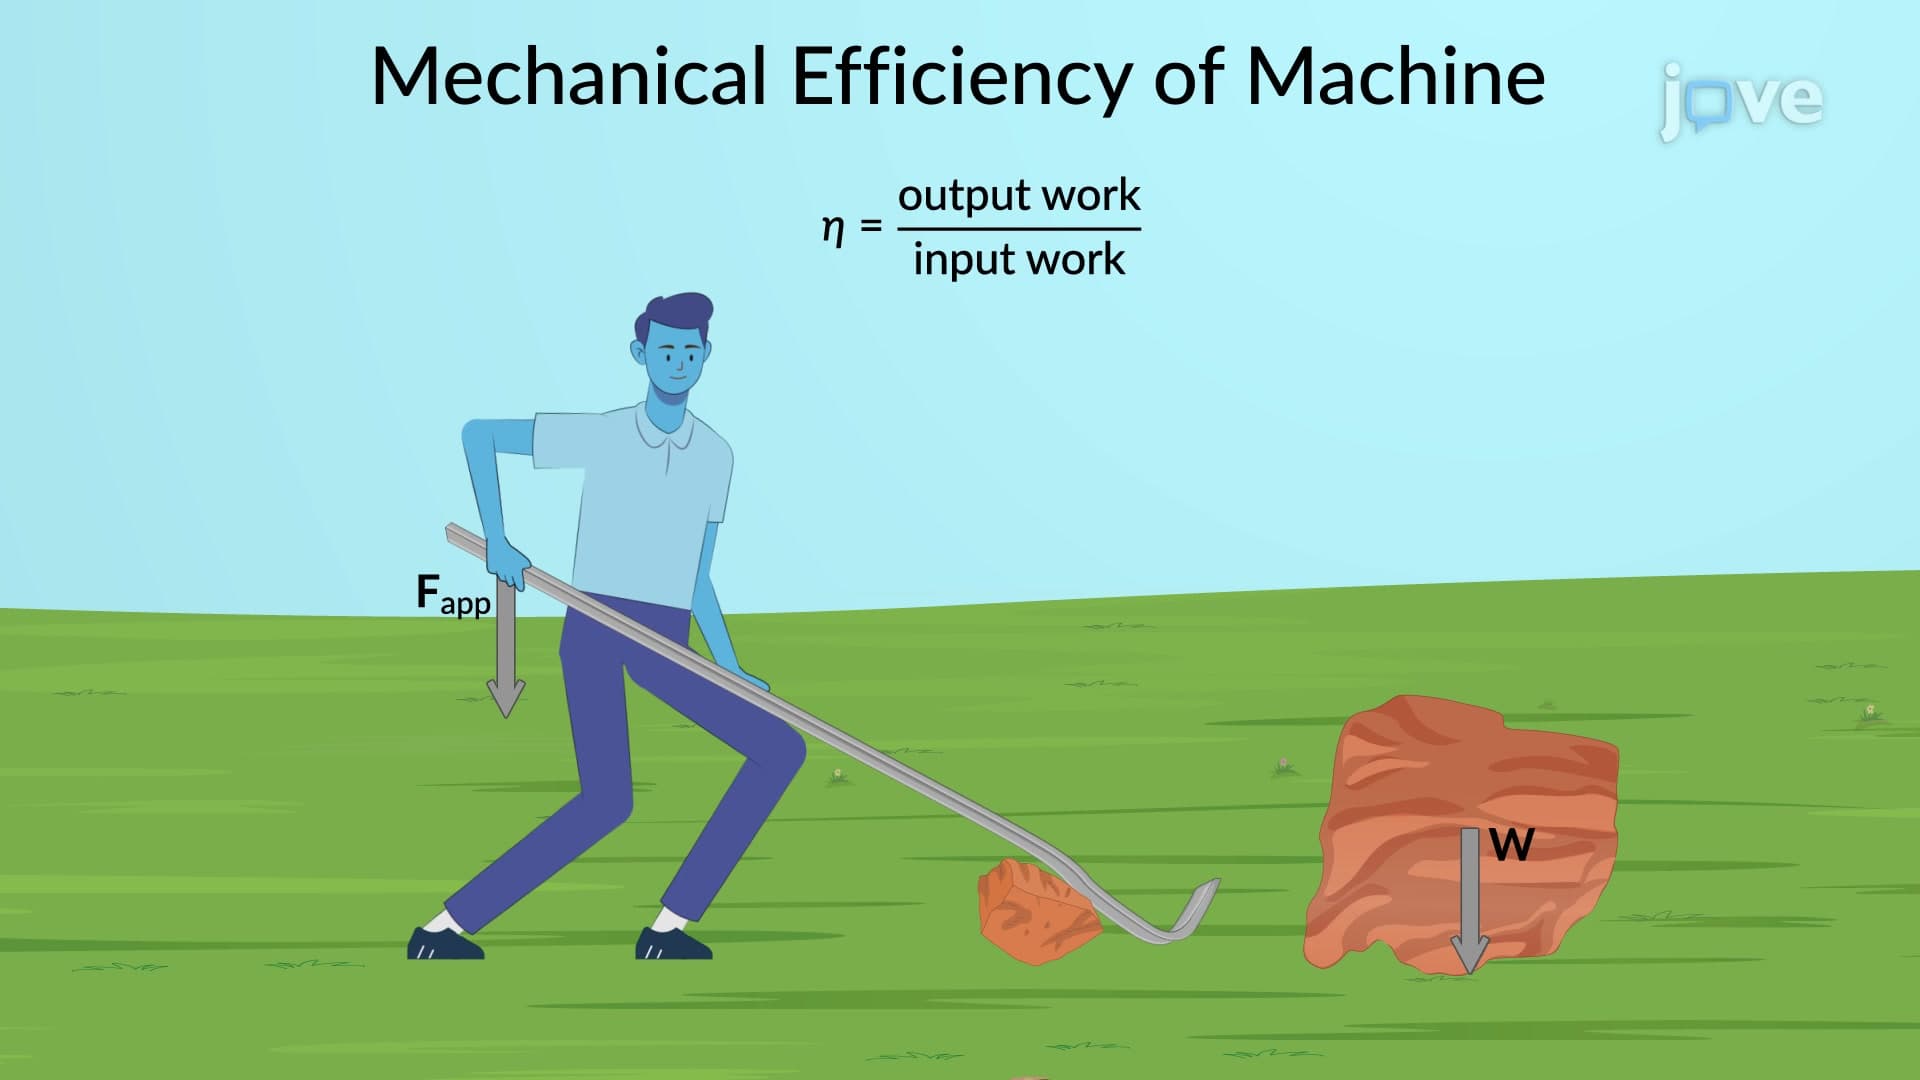
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:27
Energy Line and Hydraulic Gradient Line
 01:29
Application of Linearization and Approximation
 01:16
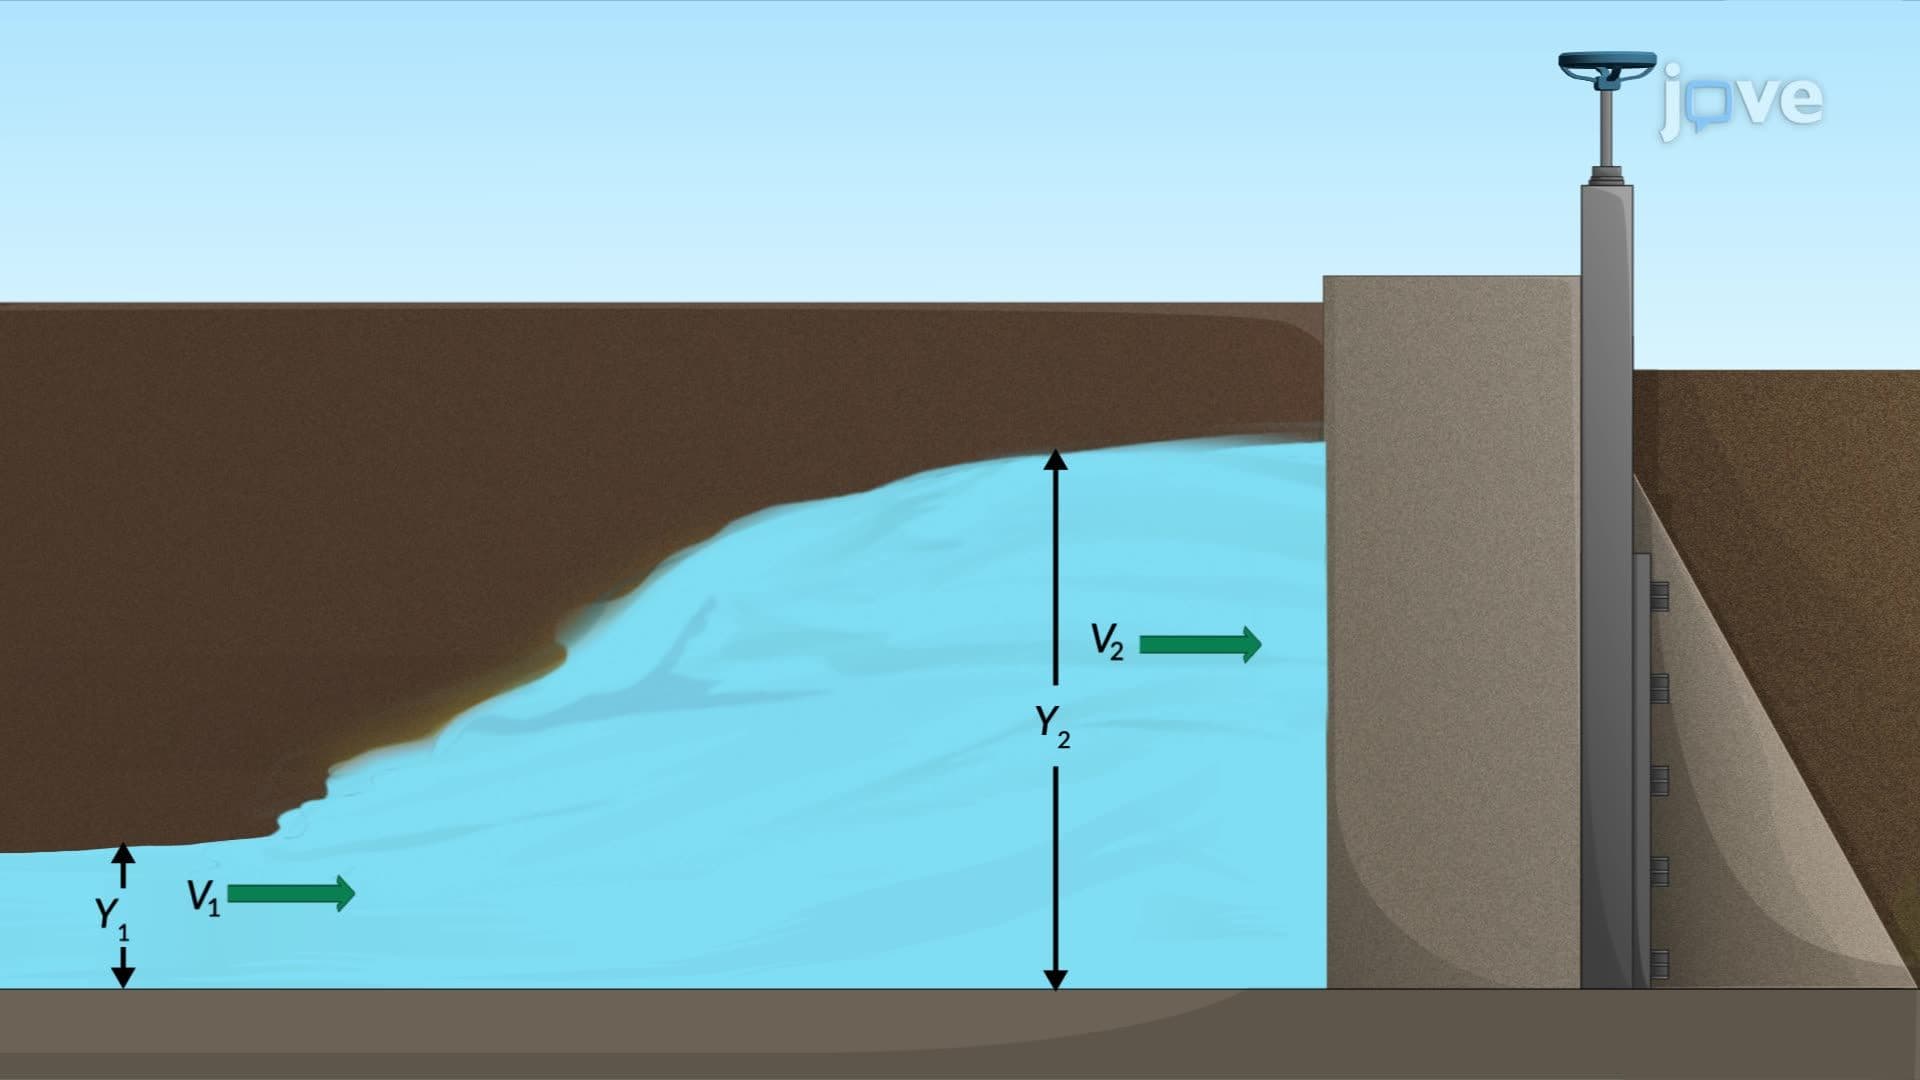
Hydraulic Jump: Problem Solving
 01:12
Taping Over Different Ground Profiles
 01:10
Energy Diagrams - II
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The slope...