Related Experiment Video
Updated: May 24, 2026
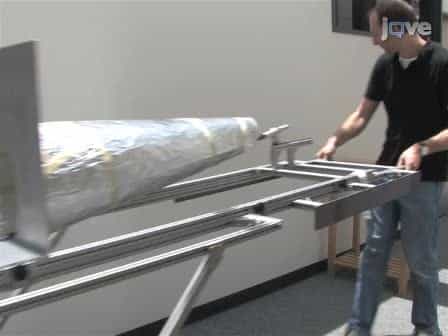
Adaptation of a Haptic Robot in a 3T fMRI
Published on: October 4, 2011
Thoughts turned into high-level commands: Proof-of-concept study of a vision-guided robot arm driven by functional
Ludovico Minati1, Anna Nigri, Cristina Rosazza
1Scientific Department, Fondazione IRCCS Istituto Neurologico Carlo Besta, Milan, Italy. lminati@ieee.org

Abstract:
Previous studies have demonstrated the possibility of using functional MRI to control a robot arm through a brain-machine interface by directly coupling haemodynamic activity in the sensory-motor cortex to the position of two axes. Here, we extend this work by implementing interaction at a more abstract level, whereby imagined actions deliver structured commands to a robot arm guided by a machine vision system. Rather than extracting signals from a small number of pre-selected regions, the proposed system adaptively determines at individual level how to map representative brain areas to the input nodes of a classifier network. In this initial study, a median action recognition accuracy of 90% was attained on five volunteers performing a game consisting of collecting randomly positioned coloured pawns and placing them into cups. The "pawn" and "cup" instructions were imparted through four mental imaginery tasks, linked to robot arm actions by a state machine. With the current implementation in MatLab language the median action recognition time was 24.3s and the robot execution time was 17.7s. We demonstrate the notion of combining haemodynamic brain-machine interfacing with computer vision to implement interaction at the level of high-level commands rather than individual movements, which may find application in future fMRI approaches relevant to brain-lesioned patients, and provide source code supporting further work on larger command sets and real-time processing.
More Related Videos
 07:34
Functional MRI in Conjunction with a Novel MRI-compatible Hand-induced Robotic Device to Evaluate Rehabilitation of Individuals Recovering from Hand Grip Deficits
Published on: November 23, 2019
 05:25
An Experiment Using Functional Near-Infrared Spectroscopy and Robot-Assisted Multi-Joint Pointing Movements of the Lower Limb
Published on: June 7, 2024