Related Experiment Video
Updated: May 23, 2026
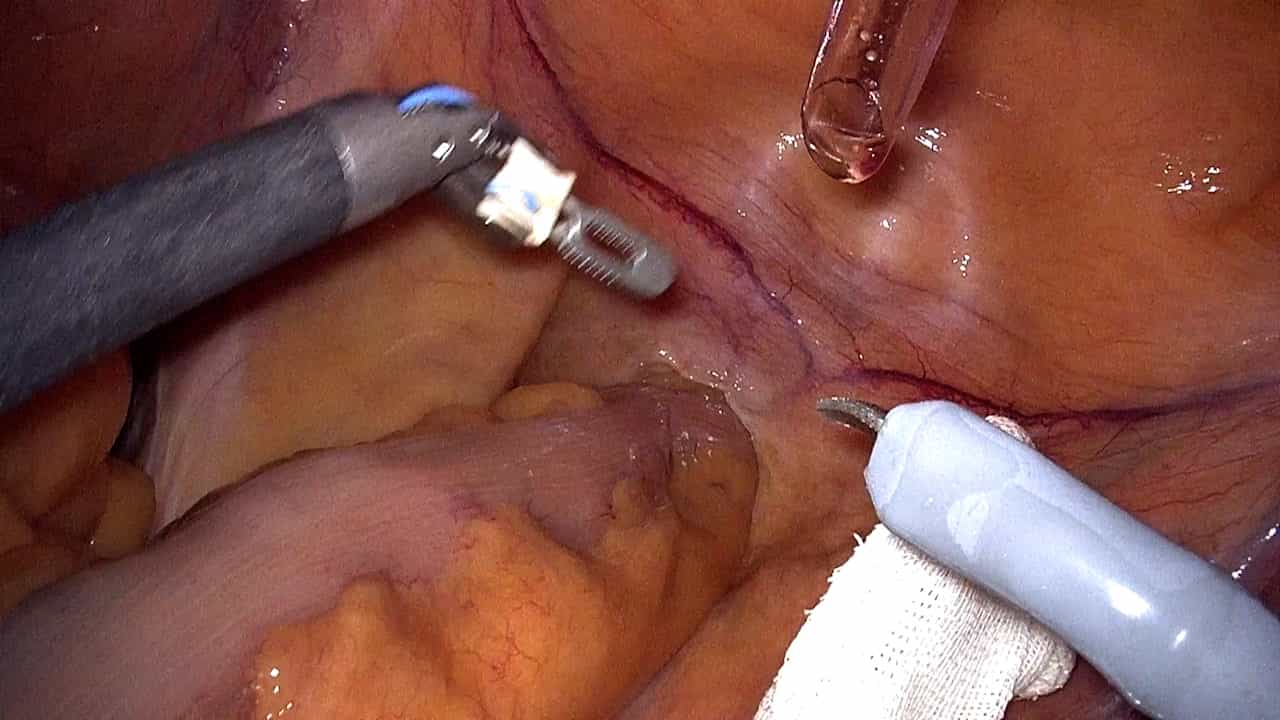

Surgical Robot-Assisted Transanal Specimen Extraction Radical Sigmoidectomy Without an Auxiliary Abdominal Incision
Published on: June 13, 2025
Mental workload and stress perceived by novice operators in the laparoscopic and robotic minimally invasive surgical
Martina I Klein1, Joel S Warm, Michael A Riley
1Department of Psychology, Texas Tech University, Lubbock, Texas 79409, USA. martina.i.klein@ttu.edu

Background And Purpose:
High levels of mental workload and stress are experienced by surgeons in the laparoscopic environment. The da Vinci(®) surgical robot was developed to provide surgeons a more user-friendly interface while maintaining the patient benefits associated with laparoscopy. This study examined whether the da Vinci robot reduces mental workload and stress in novice medical students. A detailed understanding of trainees' mental workload and mental stress experiences can aid in the development of training programs that are aimed at facilitating the acquisition of laparoscopic and robotic surgery skills.
Materials And Methods:
Fifteen novice first-year medical students performed a standard peg-transfer task at a laparoscopic simulator and the da Vinci Surgical System. Mental workload and stress were assessed with the Multiple Resources Questionnaire (MRQ) and the Dundee Stress State Questionnaire (DSSQ), respectively.
Results:
Students' mental workload profiles were identical with the two surgical systems and replicated previous MRQ results reported with the laparoscopic system showing high levels of workload. Students experienced a better stress profile with the robotic system, however, when compared wih the laparoscopic system.
Conclusion:
Our study shows that novice medical students perceive less stress when working with the robotic surgical interface than with the laparoscopic surgery interface. The MRQ and the DSSQ are valuable tools for identifying mental workload and mental stress in the laparoscopic and robotic surgery environments. This information may be useful for facilitating the acquisition of laparoscopic and robotic surgery skills.