Related Experiment Video
Updated: May 23, 2026
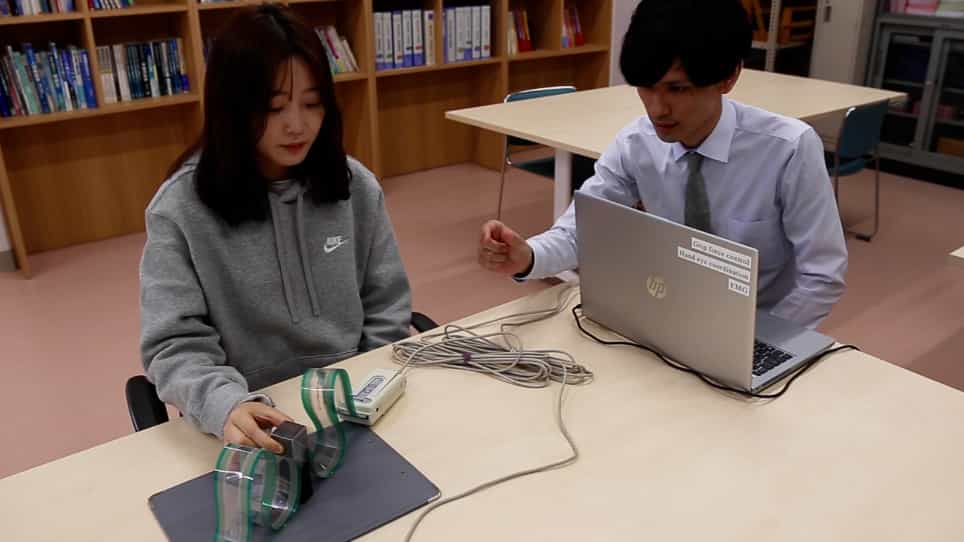

Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Tangential finger forces use mechanical advantage during static grasping
Gregory P Slota1, Mark L Latash, Vladimir M Zatsiorsky
1Pennsylvania State University, University Park, PA, USA.

Abstract:
When grasping and manipulating objects, the central controller utilizes the mechanical advantage of the normal forces of the fingers for torque production. Whether the same is valid for tangential forces is unknown. The main purpose of this study was to determine the patterns of finger tangential forces and the use of mechanical advantage as a control mechanism when dealing with objects of nonuniform finger positioning. A complementary goal was to explore the interaction of mechanical advantage (moment arm) and the role a finger has as a torque agonist/antagonist with respect to external torques (±0.4 N m). Five 6-df force/torque transducers measured finger forces while subjects held a prism handle (6 cm width × 9 cm height) with and without a single finger displaced 2 cm (handle width). The effect of increasing the tangential moment arm was significant (p < .01) for increasing tangential forces (in >70% of trials) and hence creating greater moments. Thus, the data provides evidence that the grasping system as a rule utilizes mechanical advantage for generating tangential forces. The increase in tangential force was independent of whether the finger was acting as a torque agonist or antagonist, revealing their effects to be additive.

Related Concept Videos
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:29
Moment of a Force: Problem Solving
 01:19
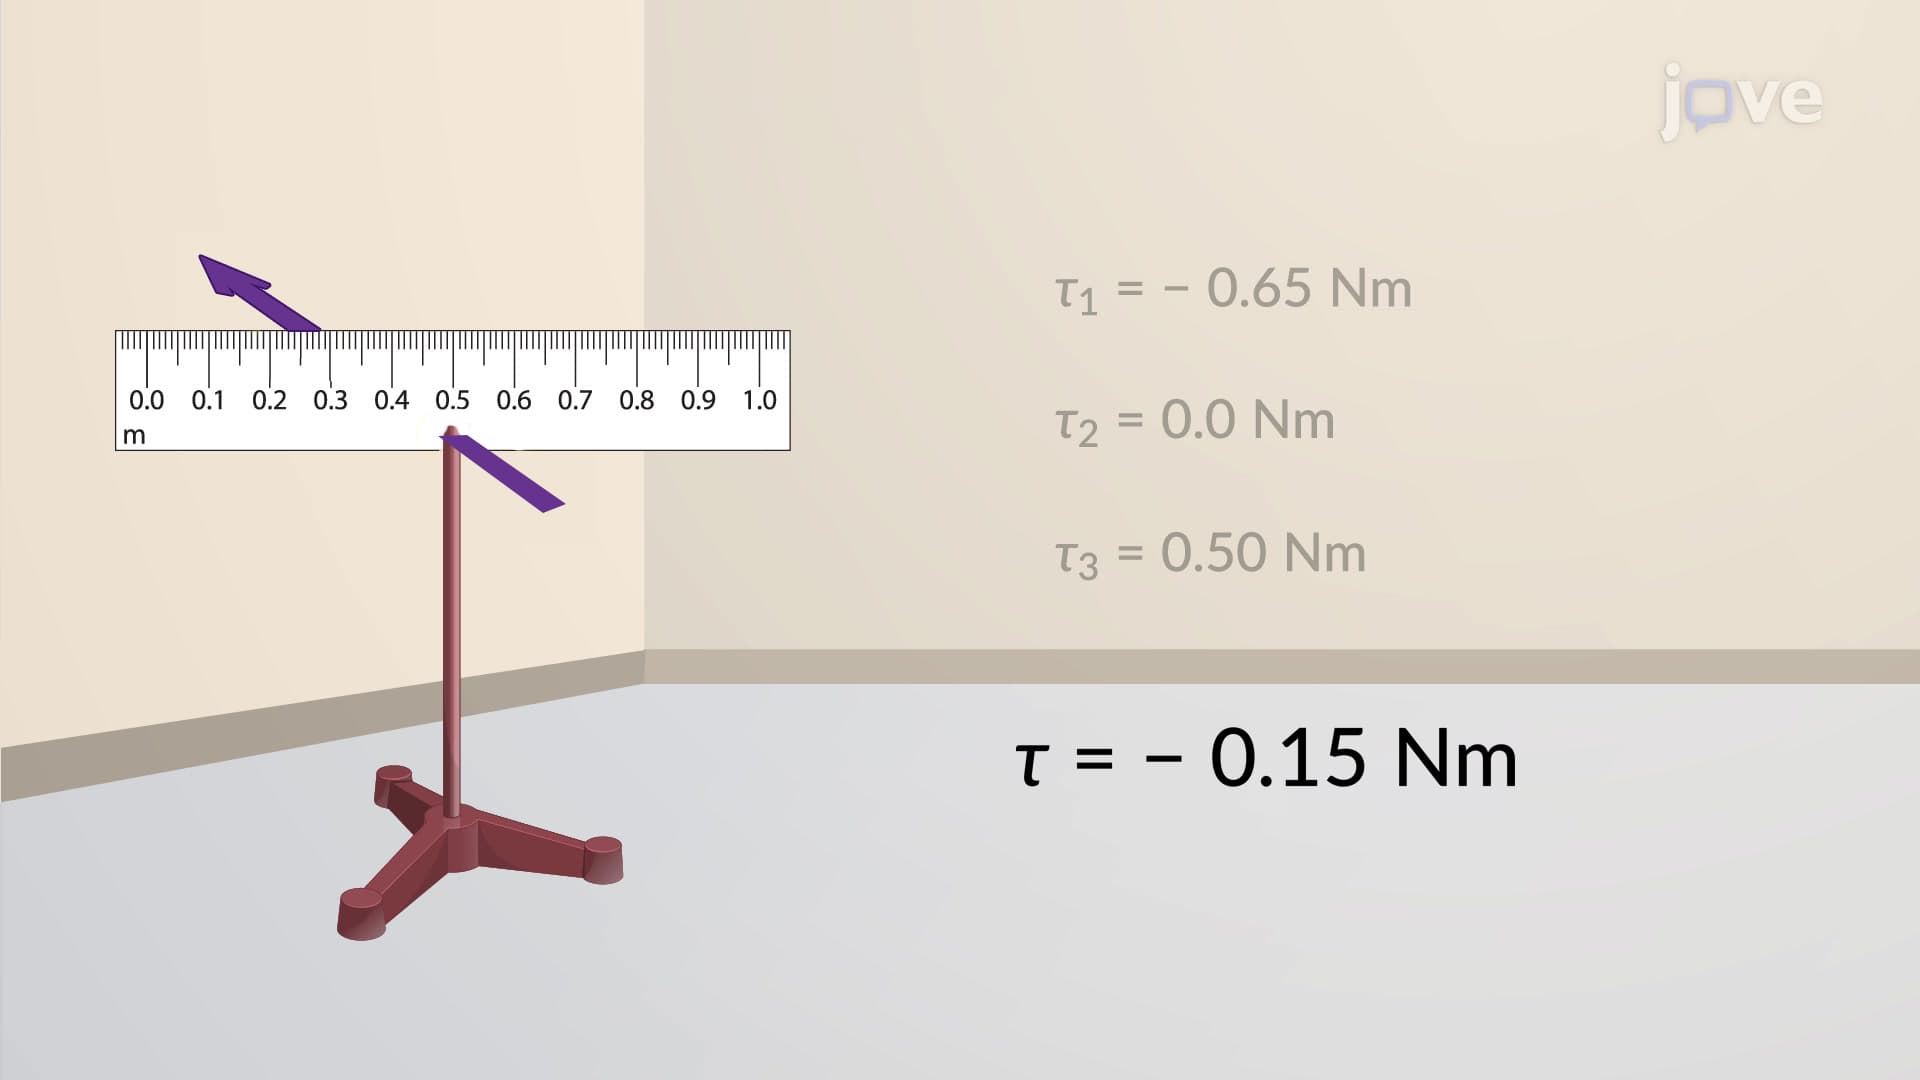
Net Torque Calculations
 01:10
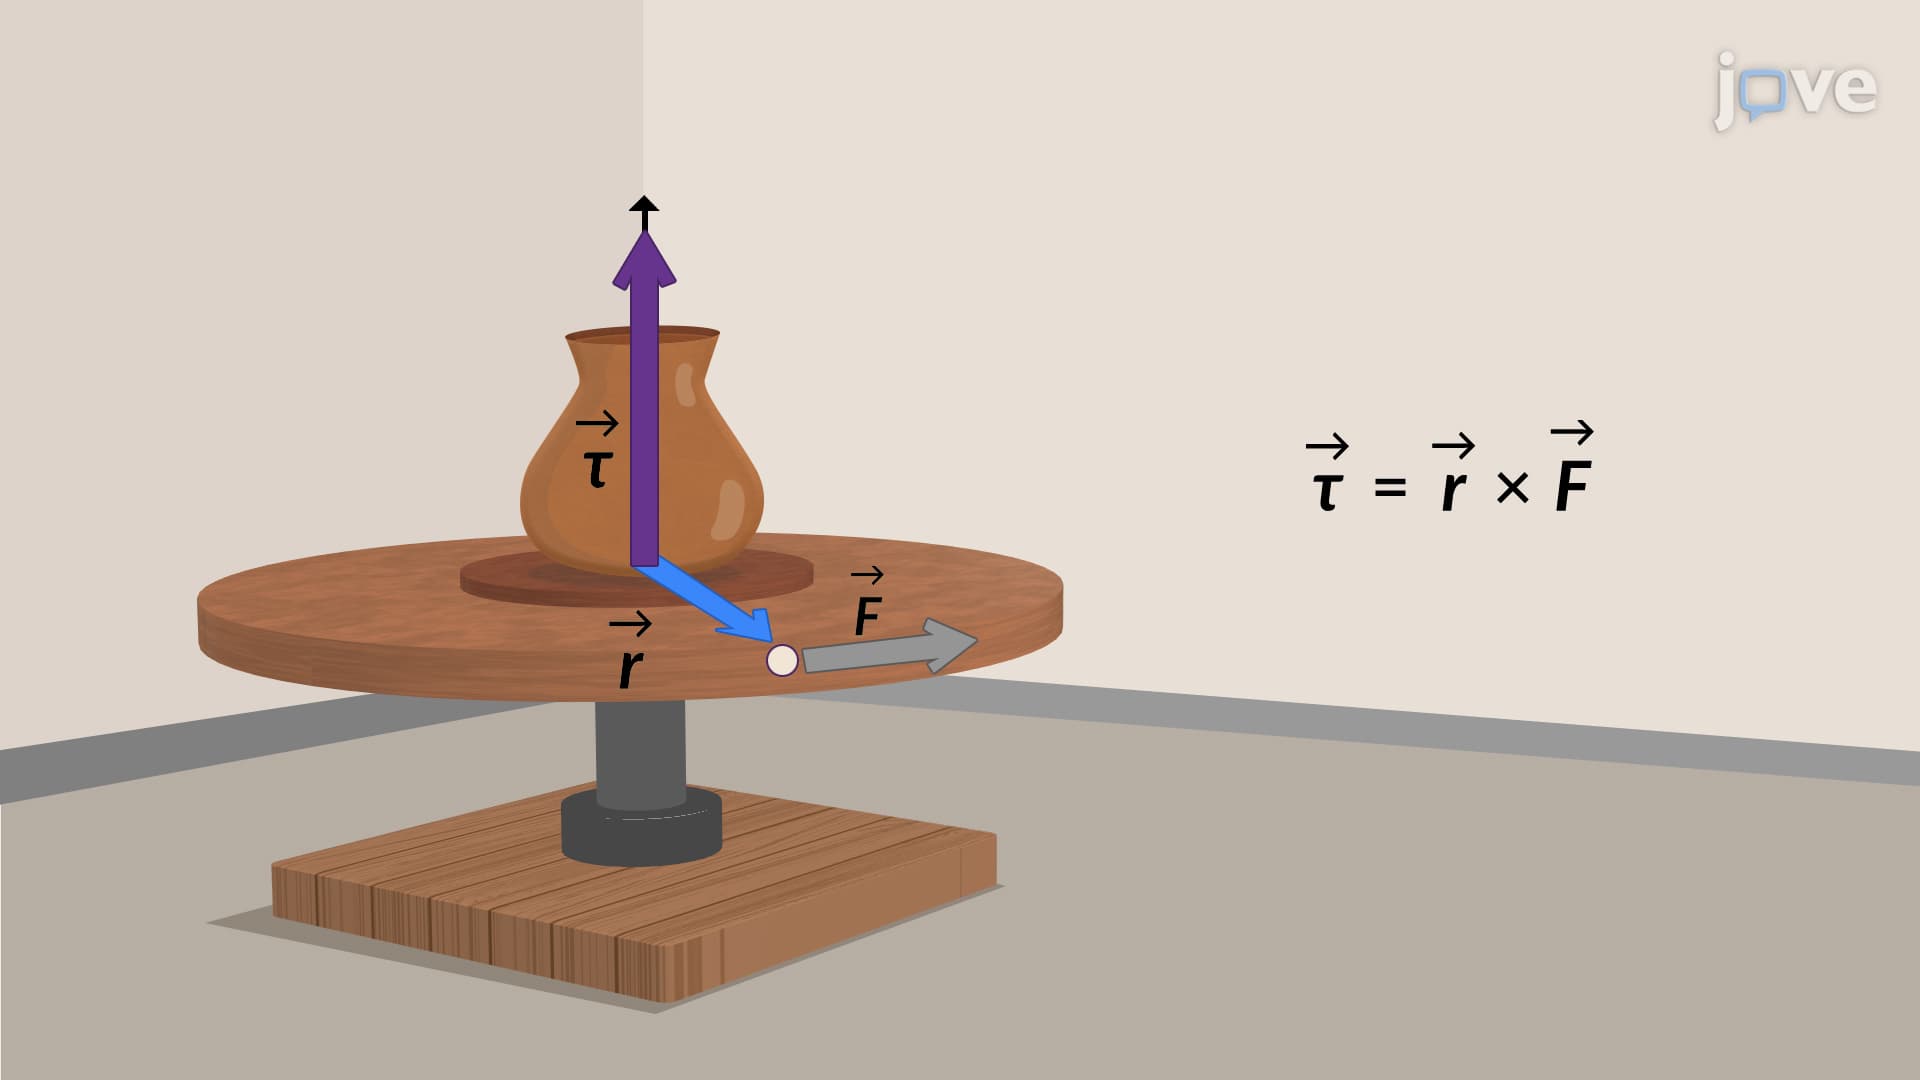
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:30
Machines: Problem Solving II
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...